The Motion module creates smooth robot trajectories that respect velocity, acceleration and jerk limits. It works offline, without robot connection, and its trajectories can be sent with [Stream Motion](/fanuc/documentation/stream-motion), used in a simulation, or checked before use.
Motions are described as in a TP program: joint (J), linear (L) and circular (C) motions, with a speed and a FINE, CNT or CR termination. The module also creates splines through points, geometric shapes, and trajectories from your own positions.
The planner is in the `UnderAutomation.Robotics.Motion` namespace. This namespace is the same in all UnderAutomation robot SDKs, so the same code can plan trajectories for other robot brands. The `FanucMotion` class of `UnderAutomation.Fanuc.Motion` converts FANUC positions, FINE, CNT and CR terminations and I/O to the types of the planner.
## Quick start
**C# : MotionQuickStart**
```csharp
using UnderAutomation.Fanuc.Common;
using UnderAutomation.Fanuc.Motion;
using UnderAutomation.Robotics.Geometry;
using UnderAutomation.Robotics.Motion;
public class MotionQuickStart
{
static void Main()
{
// Limits of the robot (example values). Read them with robot.StreamMotion.ReadLimits().ReferenceLimits
var jointLimits = new JointLimits(
new double[] { 120, 120, 180, 180, 180, 180 },
new double[] { 300, 300, 450, 675, 675, 675 },
new double[] { 1125, 1125, 1687, 2530, 1265, 2530 });
var cartesianLimits = new CartesianLimits(500, 2000, 10000, 90, 360, 1800);
/**/
var planner = new MotionPlanner(jointLimits, cartesianLimits);
// Joint motions, as J instructions of a TP program
var home = new JointValues(0, 0, 0, 0, -90, 0);
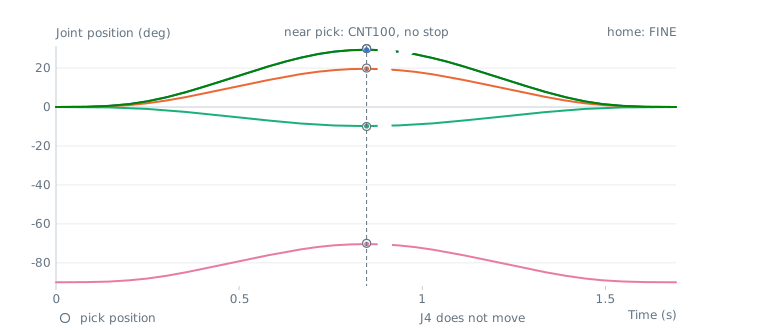
var pick = new JointValues(30, 20, -10, 0, -70, 30);
Trajectory trajectory = planner.CreateJointPath(home)
.MoveJoint(pick, 50, FanucMotion.Cnt(100)) // 50% speed, CNT100
.MoveJoint(home, 50, FanucMotion.Fine())
.Build();
Console.WriteLine($"Duration: {trajectory.Duration:0.000} s");
// Position at any time, or one position per communication cycle
JointValues middle = trajectory.GetJoints(trajectory.Duration / 2);
JointValues[] samples = trajectory.SampleJoints(0.008);
// FANUC joint position, when needed
JointsPosition fanucMiddle = FanucMotion.ToJointsPosition(middle);
// Velocity, acceleration and jerk of each axis, computed as the robot does
TrajectoryReport report = trajectory.Check(jointLimits, 0.008, false);
Console.WriteLine(report.IsValid);
/**/
}
}
```
**Python : MotionQuickStart**
```python
from underautomation.fanuc.motion.fanuc_motion import FanucMotion
from underautomation.robotics.geometry.joint_values import JointValues
from underautomation.robotics.motion.joint_limits import JointLimits
from underautomation.robotics.motion.cartesian_limits import CartesianLimits
from underautomation.robotics.motion.motion_planner import MotionPlanner
# Limits of the robot (example values). Read them with robot.stream_motion.read_limits().reference_limits
joint_limits = JointLimits(
[120, 120, 180, 180, 180, 180],
[300, 300, 450, 675, 675, 675],
[1125, 1125, 1687, 2530, 1265, 2530])
cartesian_limits = CartesianLimits(500, 2000, 10000, 90, 360, 1800)
##
planner = MotionPlanner(joint_limits, cartesian_limits)
# Joint motions, as J instructions of a TP program
home = JointValues([0, 0, 0, 0, -90, 0])
pick = JointValues([30, 20, -10, 0, -70, 30])
trajectory = planner.create_joint_path(home) \
.move_joint(pick, 50, FanucMotion.cnt(100)) \
.move_joint(home, 50, FanucMotion.fine()) \
.build()
print(f"Duration: {trajectory.duration:.3f} s")
# Position at any time, or one position per communication cycle
middle = trajectory.get_joints(trajectory.duration / 2)
samples = trajectory.sample_joints(0.008)
# FANUC joint position, when needed
fanuc_middle = FanucMotion.to_joints_position(middle)
# Velocity, acceleration and jerk of each axis, computed as the robot does
report = trajectory.check(joint_limits, 0.008, False)
print(report.is_valid)
##
```
## Try it in the demo application
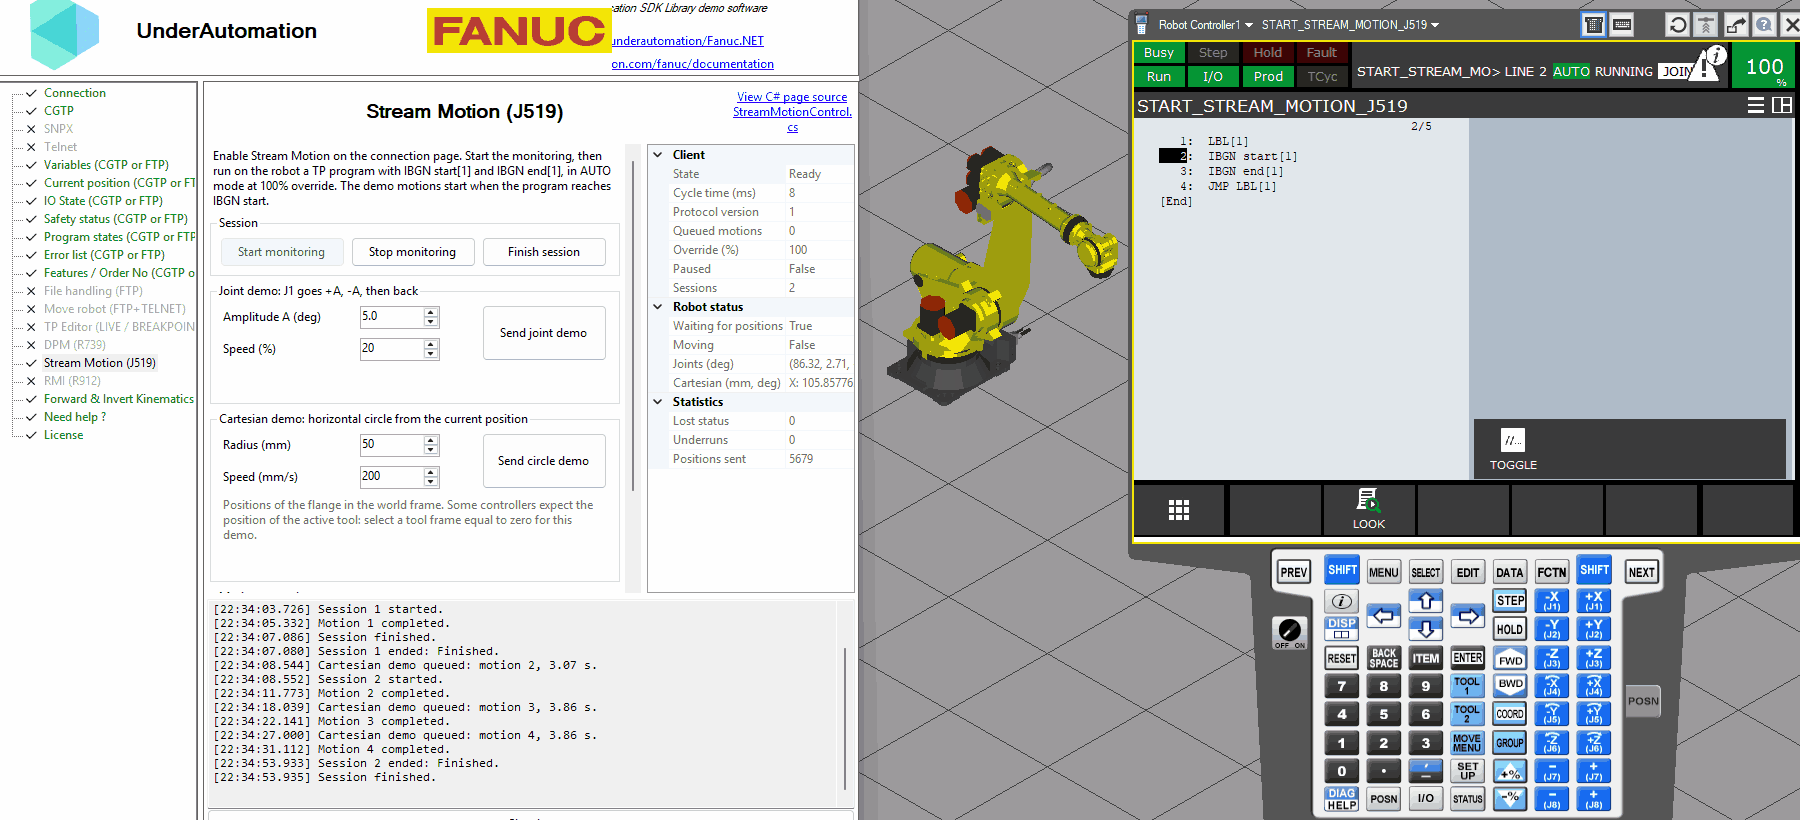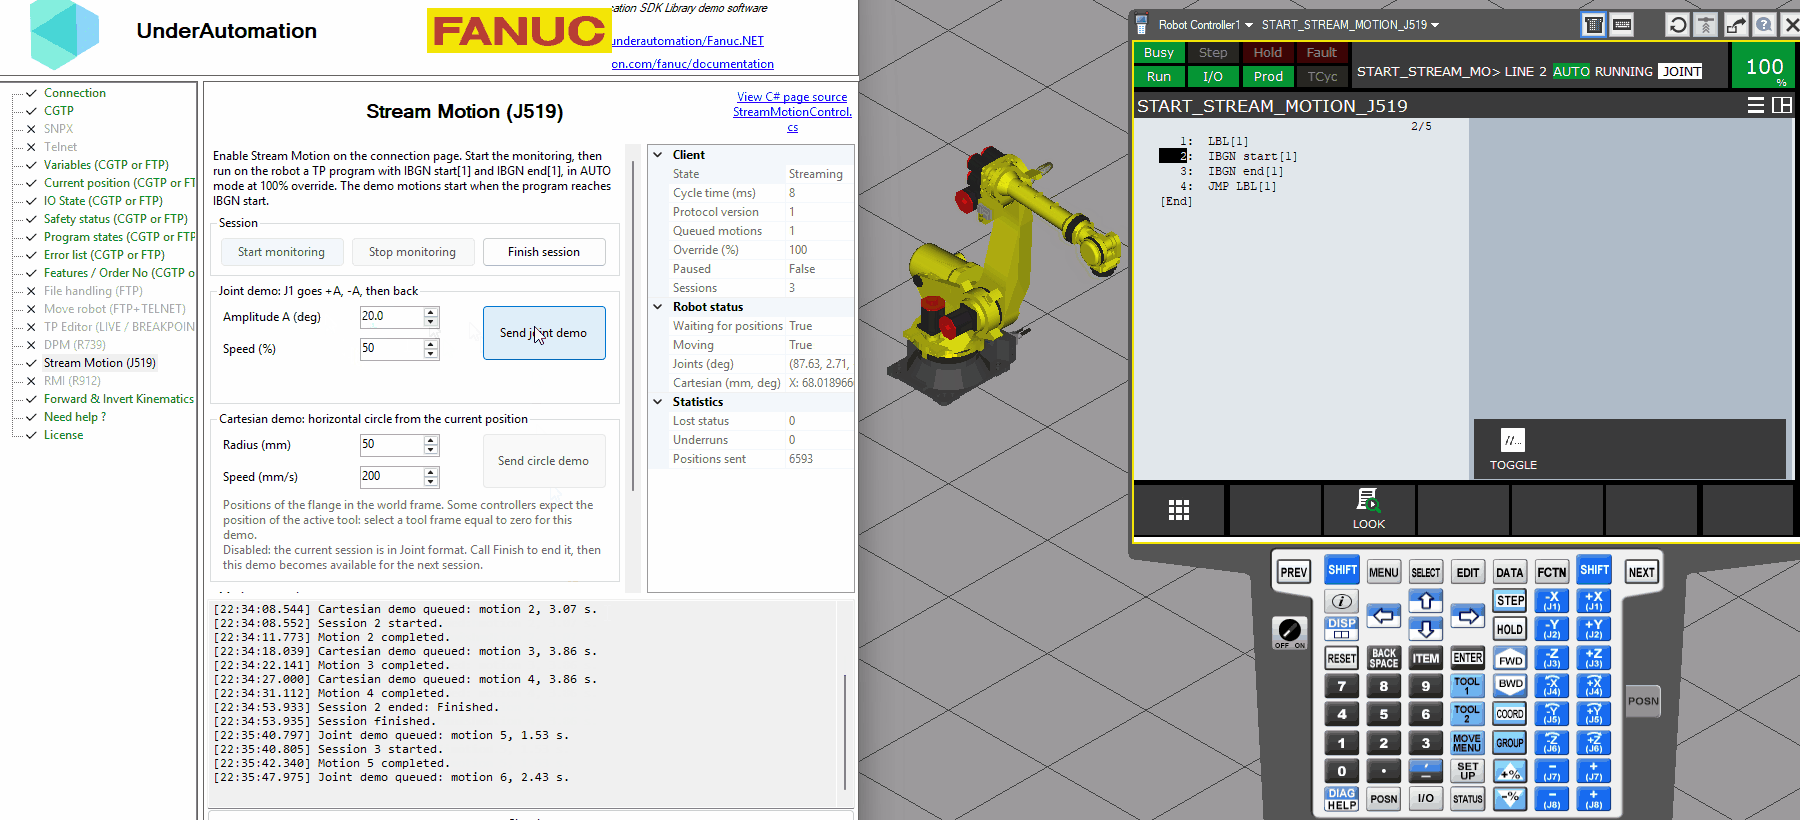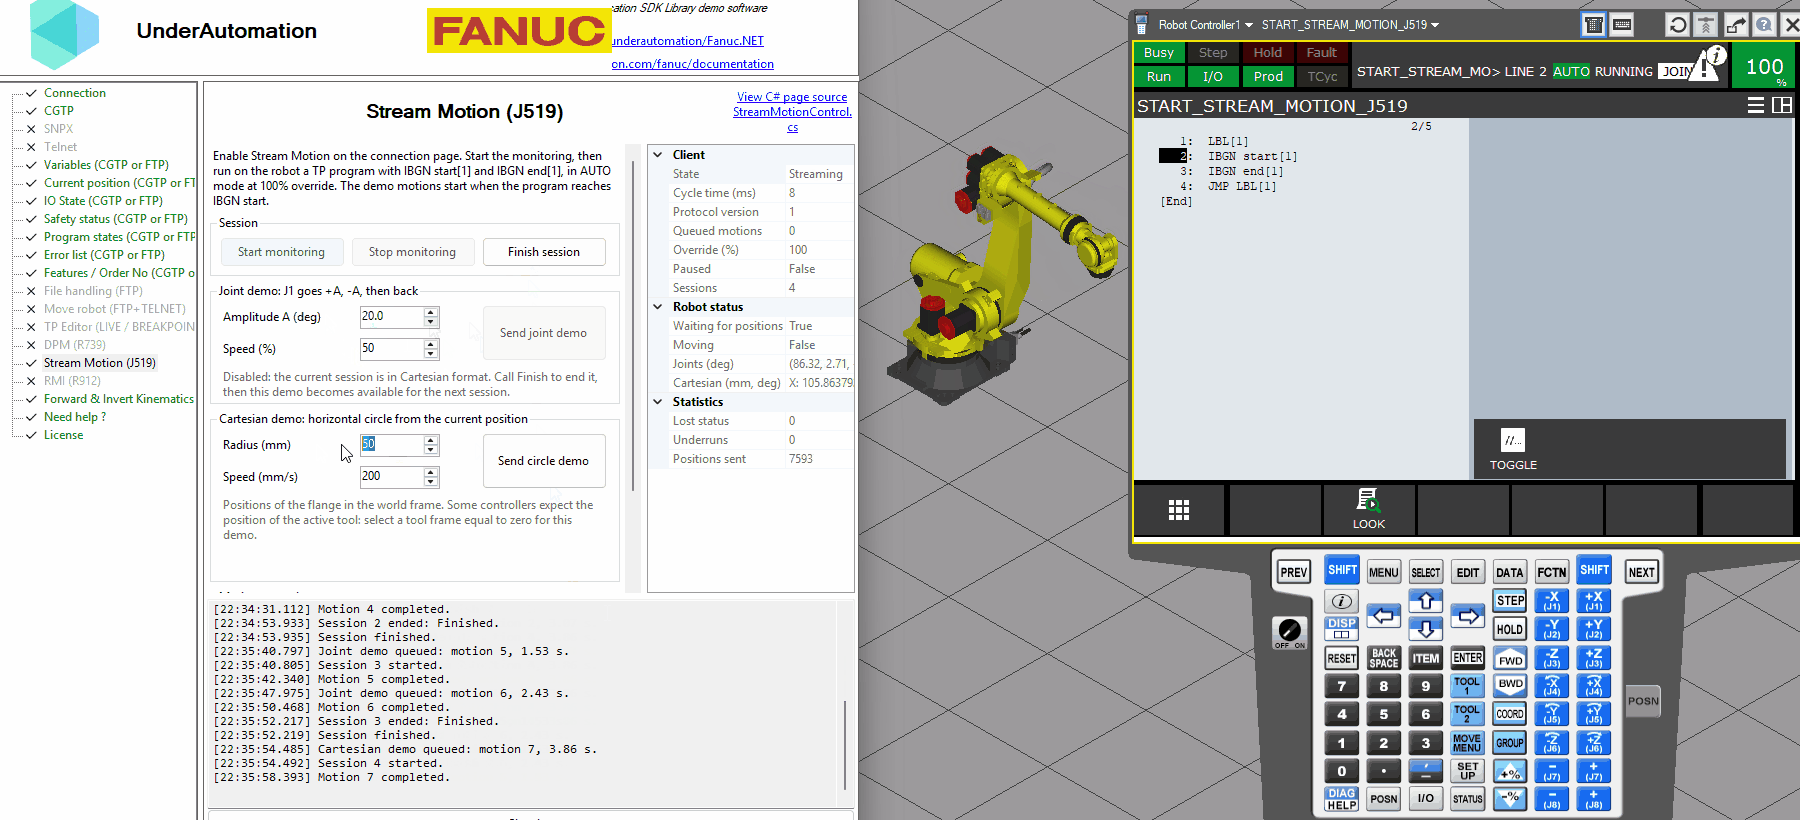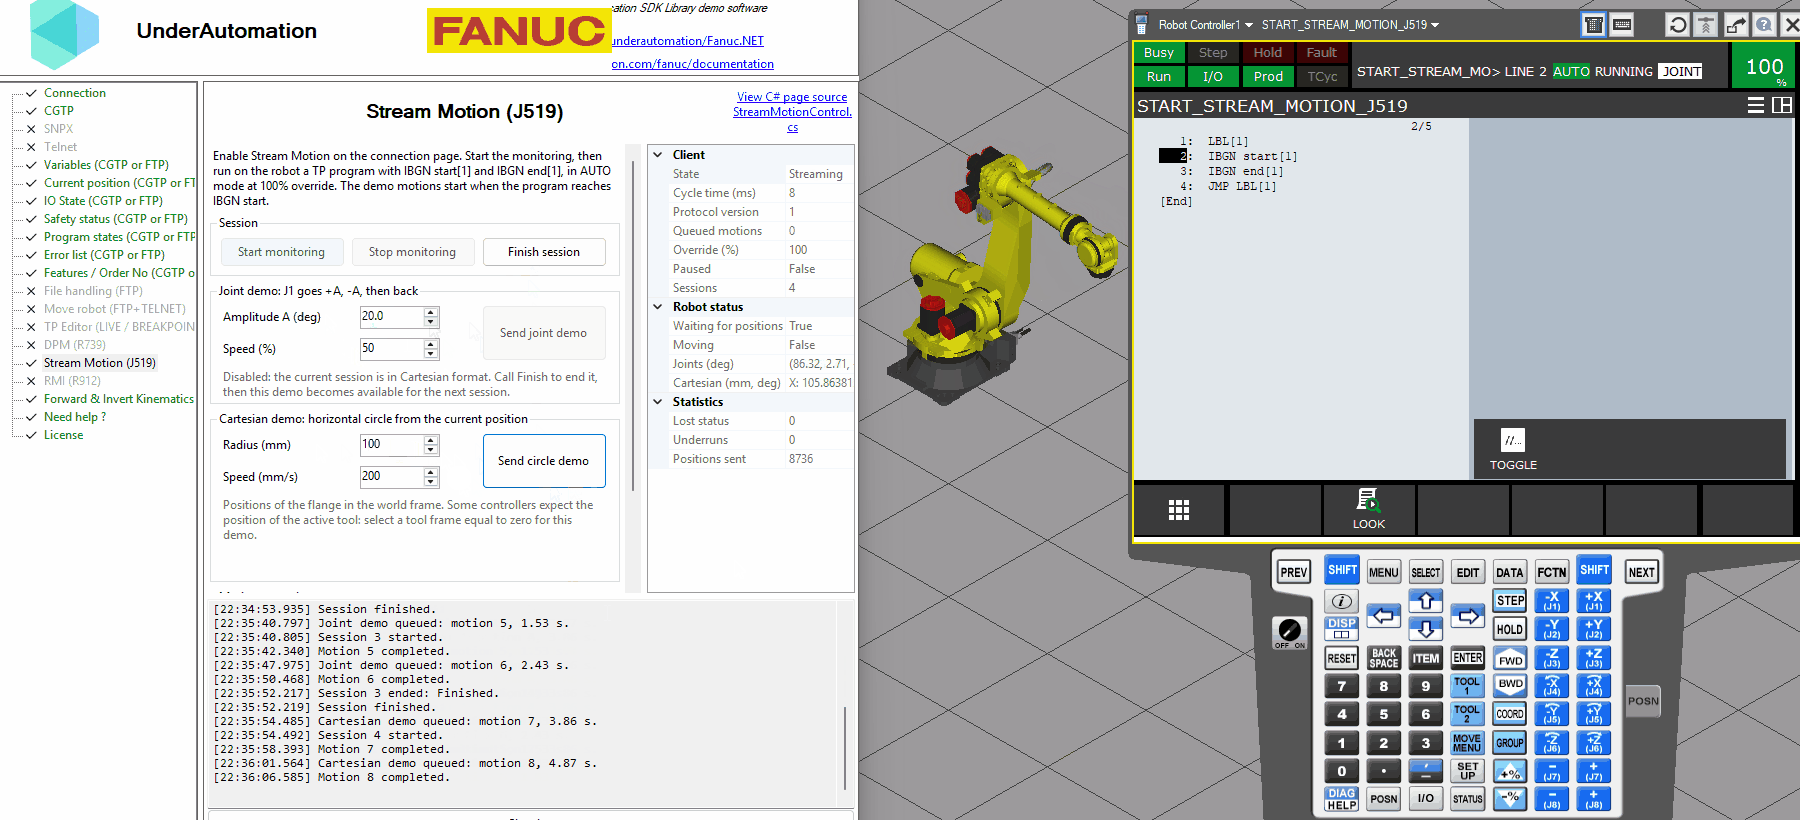
The [demo application](/fanuc/documentation/demo-app) (Windows) has a Stream Motion page with two buttons that build trajectories with the motion planner and send them to the robot with [Stream Motion](/fanuc/documentation/stream-motion).
- **Joint demo** uses a `JointPathBuilder`: J1 moves to +amplitude, then to -amplitude with a `Cnt` termination between the two moves, then back to the start with `Fine`.
- **Cartesian demo** uses a `CartesianPathBuilder`: a horizontal circle of the given radius, starting and ending at the current position.
Change the amplitude, the radius or the speed and send the demo again: the duration of the resulting trajectory is shown in the log, and the joint and Cartesian positions update in real time while the robot moves.
The C# source of this page is in the `StreamMotionControl.cs` file of the [Fanuc.NET repository](https://github.com/underautomation/Fanuc.NET/blob/main/UnderAutomation.Fanuc.Showcase.Forms/Components/StreamMotionControl.cs).
## Main concepts
| Class | Role |
| --- | --- |
| `JointLimits` | Velocity, acceleration and jerk of each axis (9 axes). Read them from the robot with `StreamMotion.ReadLimits()` |
| `CartesianLimits` | Linear and angular velocity, acceleration and jerk, for Cartesian motions. You choose them |
| `MotionPlanner` | Creates joint and Cartesian paths with the limits, and optional tool and user frames |
| `JointPathBuilder`, `CartesianPathBuilder` | Chain motions, waits and I/O, then `Build()` the trajectory |
| `Trajectory` | Result: position at any time, samples at a fixed period, I/O events, limit checks |
| `JointValues`, `CartesianPose` | Joint and Cartesian positions of the planner. A `CartesianPose` has X, Y, Z, an `Orientation` and optional external axes |
| `FanucMotion` | Conversions with `JointsPosition` and `XYZWPRPosition`, FINE, CNT and CR terminations, I/O signals, FANUC positions of a trajectory |
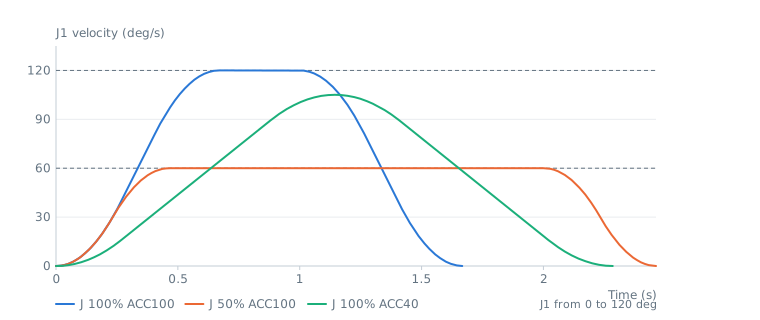
All motions use jerk limited profiles: the acceleration changes progressively, which gives smooth motions and avoids the jerk alarms of the robot. 100% speed means the velocity limits, and the acceleration percentage (ACC) scales the acceleration and the jerk.
## What do you want to do?
| Need | Page |
| --- | --- |
| Move to positions with J, L, C motions, FINE, CNT, CR | [Joint & Cartesian motions](/fanuc/documentation/motion-moves) |
| Pass through a list of points, draw a circle, a rectangle or a helix | [Splines & shapes](/fanuc/documentation/motion-splines-shapes) |
| Use positions computed by your application, check or slow down a trajectory | [Trajectories from points](/fanuc/documentation/motion-trajectory-from-points) |
| Convert orientations and positions between frames | [Frames & orientations](/fanuc/documentation/motion-frames-orientations) |
## Units and conventions
- Joint positions in degrees (mm for linear axes), Cartesian positions in mm, angles in degrees.
- Velocities per second, accelerations per second squared, jerks per second cubed.
- The W, P, R angles of FANUC use the fixed XYZ convention: `CartesianPose.FromEuler(x, y, z, w, p, r, EulerConvention.FixedXYZ)` gives the same pose as `FanucMotion.ToCartesianPose(new XYZWPRPosition(x, y, z, w, p, r))`.
- `FanucMotion.SampleCartesian()` gives FANUC positions whose W, P, R angles stay continuous: an angle can go beyond 180 degrees instead of jumping to -180.
## API reference
**Members of Motion.FanucMotion**
```csharp
public static class FanucMotion {
// CNT termination: the next motion starts during the deceleration of this one
public static Termination Cnt(int value)
// CR termination (corner region): the corner is replaced by a smooth curve at constant speed. Only between Cartesian motions.
public static Termination Cr(double distance)
// FINE termination: the robot stops at the target position
public static Termination Fine()
// Creates a Cartesian trajectory from FANUC positions taken at a fixed period.
// The W, P, R angles are kept without any change, and the extended axes are used when the positions are .
public static Trajectory FromCartesianSamples(XYZWPRPosition[] samples, double cycleTime)
// Samples a Cartesian trajectory at a fixed period and returns FANUC positions. The W, P, R angles stay continuous from one position to the next.
public static ExtendedCartesianPosition[] SampleCartesian(Trajectory trajectory, double cycleTime)
// Returns the digital signal of an I/O, to write it during a trajectory (for example DO[5])
public static DigitalSignal Signal(IOType type, int index)
// Converts a FANUC position to a pose. The extended axes E1, E2 and E3 are copied when the position is an .
public static CartesianPose ToCartesianPose(XYZWPRPosition position)
// Converts a pose to a FANUC position with extended axes (0 when the pose has no external axes).
public static ExtendedCartesianPosition ToExtendedCartesianPosition(CartesianPose pose, XYZWPRPosition reference)
// Converts a FANUC joint position (J1 to J9) to joint values
public static JointValues ToJointValues(JointsPosition position)
// Converts joint values to a FANUC joint position. Missing axes are 0.
public static JointsPosition ToJointsPosition(JointValues values)
// Convention of the W, P, R angles of FANUC positions: rotation W around the fixed X axis, then P around the fixed Y axis, then R around the fixed Z axis
public static EulerConvention WprConvention { get; }
}
```