With XML-RPC, a program that runs on a Universal Robots cobot calls a function of your application and uses its answer: a position computed by a vision system, a number, a text. This page shows how to answer these calls with the SDK. The SDK is the server: it listens on a port of the PC, 50000 by default.
## How it works
1. The robot program creates a connection to the PC with `rpc_factory`.
2. It calls a function of this connection. The robot waits for the answer.
3. The SDK raises `XmlRpcServerRequest` with the name of the function and its arguments. Your code sets `Answer`.
4. The robot assigns the answer to its variable, and the program continues.
URScript of the robot, where `192.168.0.10` is the address of the PC:
```ruby
rpc := rpc_factory("xmlrpc", "http://192.168.0.10:50000")
pose := rpc.get_pose()
text := rpc.say_hello("UR5e")
total := rpc.sum([1, 3.5, -2])
```
See [XML-RPC communication](https://www.universal-robots.com/articles/ur/interface-communication/xml-rpc-communication/) by Universal Robots. The address of the PC on the network of the robot is also in `robot.PrimaryInterface.LocalEndPoint`.
## Example
The XML-RPC server is disabled by default: set `XmlRpc.Enable` in `ConnectParameters`.
**C# : XmlRpc**
```csharp
using UnderAutomation.UniversalRobots;
using UnderAutomation.UniversalRobots.Common;
using UnderAutomation.UniversalRobots.XmlRpc;
class XmlRpc
{
static void Main(string[] args)
{
/**/
var robot = new UR();
var parameters = new ConnectParameters("192.168.0.1");
// The XML-RPC server is disabled by default
parameters.XmlRpc.Enable = true;
parameters.XmlRpc.Port = 50000;
robot.Connect(parameters);
// Raised for each call of the robot program
robot.XmlRpc.XmlRpcServerRequest += OnRequest;
/**/
}
/**/
// The robot program connects with:
// rpc := rpc_factory("xmlrpc", "http://192.168.0.10:50000")
// where 192.168.0.10 is the address of this PC
static void OnRequest(object sender, XmlRpcEventArg request)
{
Console.WriteLine(request.EndPoint.Address + " calls " + request.MethodName);
switch (request.MethodName)
{
// URScript: answer := rpc.get_pose()
case "get_pose":
request.Answer = new Pose(0.4, -0.1, 0.3, 0, 3.14, 0); // m and rad
break;
// URScript: answer := rpc.say_hello("UR5e")
case "say_hello":
request.Answer = "Hello " + request.Arguments[0];
break;
// URScript: answer := rpc.sum([1, 3.5, -2])
case "sum":
double[] values = request.Arguments[0];
request.Answer = values.Sum();
break;
// Without an answer, the variable of the robot is not assigned
default:
break;
}
}
/**/
}
```
**Python : XmlRpc**
```python
from underautomation.universal_robots.ur import UR
from underautomation.universal_robots.connect_parameters import ConnectParameters
from underautomation.universal_robots.common.pose import Pose
from underautomation.universal_robots.xml_rpc.xml_rpc_event_arg import XmlRpcEventArg
from underautomation.universal_robots.xml_rpc.xml_rpc_pose_value import XmlRpcPoseValue
from underautomation.universal_robots.xml_rpc.xml_rpc_string_value import XmlRpcStringValue
##
robot = UR()
parameters = ConnectParameters("192.168.0.1")
# The XML-RPC server is disabled by default
parameters.xml_rpc.enable = True
parameters.xml_rpc.port = 50000
robot.connect(parameters)
# The robot program connects with:
# rpc := rpc_factory("xmlrpc", "http://192.168.0.10:50000")
# where 192.168.0.10 is the address of this PC
def on_request(sender, e):
request = XmlRpcEventArg(e._instance)
print(request.end_point, "calls", request.method_name)
# URScript: answer := rpc.get_pose()
if request.method_name == "get_pose":
request.answer = XmlRpcPoseValue(Pose(0.4, -0.1, 0.3, 0, 3.14, 0)) # m and rad
# URScript: answer := rpc.say_hello("UR5e")
elif request.method_name == "say_hello":
request.answer = XmlRpcStringValue("Hello " + str(request.arguments[0]))
# Without an answer, the variable of the robot is not assigned
# Raised for each call of the robot program
robot.xml_rpc.xml_rpc_server_request(on_request)
##
```
The same server works without `UR`:
**C# : XmlRpcDirect**
```csharp
using UnderAutomation.UniversalRobots.XmlRpc;
class XmlRpcDirect
{
static void Main(string[] args)
{
/**/
// An XML-RPC server, without a UR instance
var server = new XmlRpcServer();
server.XmlRpcServerRequest += (sender, request) =>
{
if (request.MethodName == "get_counter")
request.Answer = 42;
};
server.Start(50000);
// ...
server.Stop();
/**/
}
}
```
**Python : XmlRpcDirect**
```python
from underautomation.universal_robots.xml_rpc.xml_rpc_server import XmlRpcServer
from underautomation.universal_robots.xml_rpc.xml_rpc_event_arg import XmlRpcEventArg
from underautomation.universal_robots.xml_rpc.xml_rpc_integer_value import XmlRpcIntegerValue
##
# An XML-RPC server, without a UR instance
server = XmlRpcServer()
def on_request(sender, e):
request = XmlRpcEventArg(e._instance)
if request.method_name == "get_counter":
request.answer = XmlRpcIntegerValue(42)
server.xml_rpc_server_request(on_request)
server.start(50000)
# ...
server.stop()
##
```
Allow the port of the server in the firewall of the PC.
## Values
`Answer` and `Arguments` are `XmlRpcValue`. In C#, implicit conversions accept and return the native types: `request.Answer = 12`, `= 3.5`, `= true`, `= "text"`, `= new Pose(...)`, `= new double[] {...}`, and `double[] values = request.Arguments[0]`.
| URScript type | .NET class | Python class |
| ------------- | --------------------- | ----------------------------------------------- |
| integer | `XmlRpcIntegerValue` | `XmlRpcIntegerValue(12)` |
| float | `XmlRpcDoubleValue` | `XmlRpcDoubleValue(3.5)` |
| boolean | `XmlRpcBooleanValue` | `XmlRpcBooleanValue(True)` |
| string | `XmlRpcStringValue` | `XmlRpcStringValue("text")` |
| pose | `XmlRpcPoseValue` | `XmlRpcPoseValue(Pose(x, y, z, rx, ry, rz))` |
| array | `XmlRpcArrayValue` | `XmlRpcArrayValue` |
| struct | `XmlRpcStructValue` | `XmlRpcStructValue` |
A value that the SDK cannot read is an `XmlRpcUnknownValue`: its `AdditionalInformation` says why.
Without an answer, the function returns nothing to the robot and its variable is not assigned.
## Example programs
### PolyScope
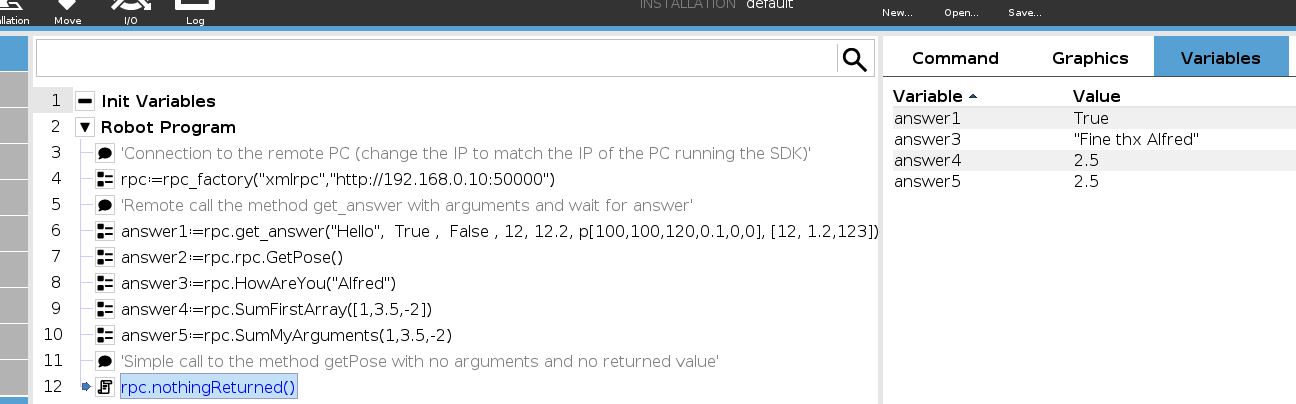
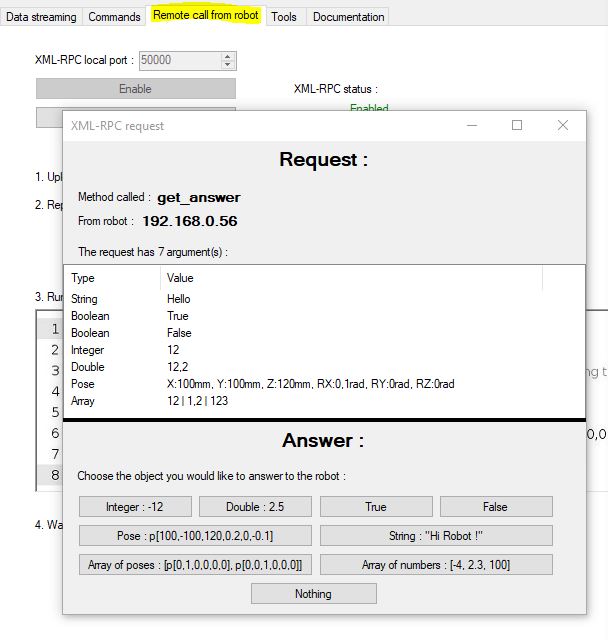
[xml_rpc_sample.urp](https://github.com/underautomation/UniversalRobots.NET/raw/main/UnderAutomation.UniversalRobots.Showcase.Forms/Samples/xml_rpc_sample.urp) calls several functions. The demo application shows each call and lets you choose the answer.
### LabVIEW
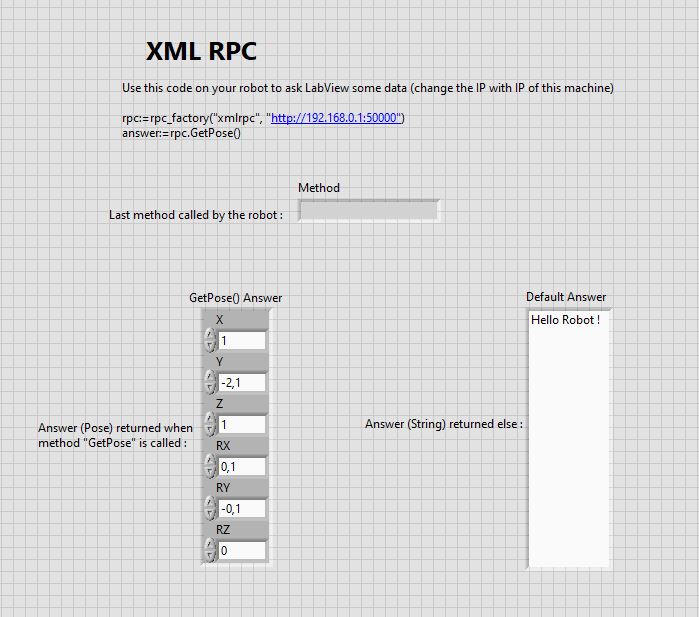
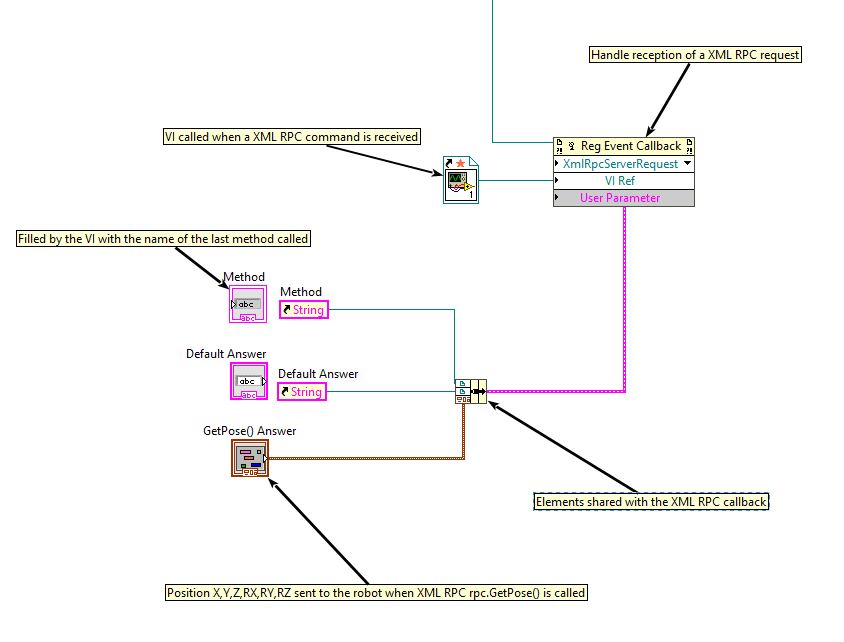
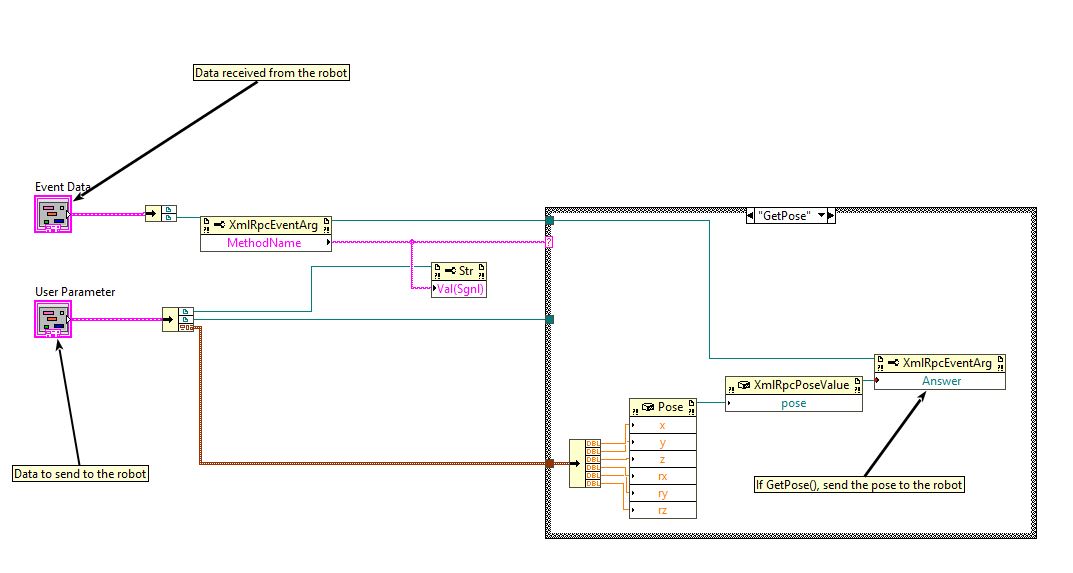
The LabVIEW example answers `GetPose()` with the position of its front panel, and a text to the other functions:
## Try it in the demo application
Everything on this page can be tried without writing code, in the **Remote procedure call (XML-RPC)** page of the [demo application](/universal-robots/documentation/demo-app).
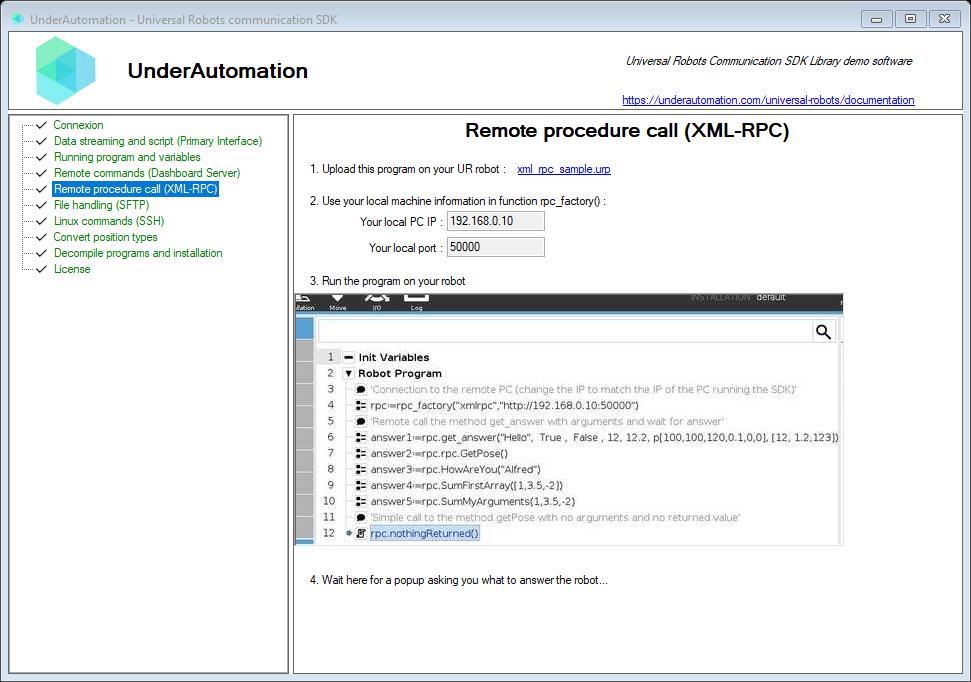
Its C# source is [XmlRpcControl.cs](https://github.com/underautomation/UniversalRobots.NET/blob/main/UnderAutomation.UniversalRobots.Showcase.Forms/Components/XmlRpcControl.cs).
## Reference
**Members of XmlRpc.XmlRpcEventArg**
```csharp
public class XmlRpcEventArg : EventArgs {
// Response to be provided to the robot by the user
public XmlRpcValue Answer
// The arguments of the method called
public readonly XmlRpcValue[] Arguments
// IP address of the robot
public readonly IPEndPoint EndPoint
// The method called by the robot
public readonly string MethodName
// Returns a string describing the method name and argument count.
public override string ToString()
// The XML document received via HTTP
public readonly XDocument XmlRequest
}
```
**Members of XmlRpc.XmlRpcValue**
```csharp
public abstract class XmlRpcValue {
protected XmlRpcValue()
// Returns the XML string representation of this value.
public override string ToString()
// Determines the class of this message
public abstract XmlRpcType Type { get; }
// The XML description of the message that has been received from the robot or will be sent to the robot
public XElement Xml { get; }
// Implicitly converts a to an .
public static implicit operator XmlRpcValue(bool value)
// Implicitly converts a array to an .
public static implicit operator XmlRpcValue(bool[] value)
// Implicitly converts a to an .
public static implicit operator XmlRpcValue(double value)
// Implicitly converts a array to an .
public static implicit operator XmlRpcValue(double[] value)
// Implicitly converts an to an .
public static implicit operator XmlRpcValue(int value)
// Implicitly converts an array to an .
public static implicit operator XmlRpcValue(int[] value)
// Implicitly converts a to an .
public static implicit operator XmlRpcValue(string value)
// Implicitly converts a array to an .
public static implicit operator XmlRpcValue(string[] value)
// Implicitly converts a to an .
public static implicit operator XmlRpcValue(Pose value)
// Implicitly converts a array to an .
public static implicit operator XmlRpcValue(Pose[] value)
// Implicitly converts an to a .
public static implicit operator bool(XmlRpcValue value)
// Implicitly converts an to a array.
public static implicit operator bool[](XmlRpcValue value)
// Implicitly converts an to a .
public static implicit operator double(XmlRpcValue value)
// Implicitly converts an to a array.
public static implicit operator double[](XmlRpcValue value)
// Implicitly converts an to an .
public static implicit operator int(XmlRpcValue value)
// Implicitly converts an to an array.
public static implicit operator int[](XmlRpcValue value)
// Implicitly converts an to a .
public static implicit operator string(XmlRpcValue value)
// Implicitly converts an to a array.
public static implicit operator string[](XmlRpcValue value)
// Implicitly converts an to a .
public static implicit operator Pose(XmlRpcValue value)
// Implicitly converts an to a array.
public static implicit operator Pose[](XmlRpcValue value)
// Implicitly converts an array of to an .
public static implicit operator XmlRpcValue(XmlRpcValue[] value)
}
```
## What to read next
- [Socket communication](/universal-robots/documentation/socket-communication): exchange your own messages with the robot program.
- [Read and write registers](/universal-robots/documentation/registers): exchange numbers with the robot program, without waiting.