This page shows the three ways to get the geometry of a Yaskawa Motoman arm for the offline kinematics of the SDK: the catalog of 169 models, the `ALL.PRM` parameter file of the controller, or your own DH parameters. It also explains the meaning of each parameter.
## DH parameters
`DhParameters` holds the 9 values that change from one 6-axis Yaskawa arm to another. The other values of the Denavit-Hartenberg table are the same for every arm.
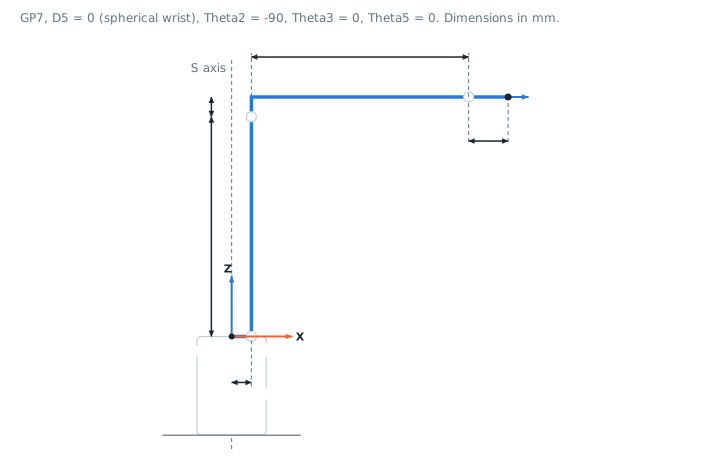
| Parameter | Meaning | GP7 |
| --------- | -------------------------------------------------------------- | ---- |
| `A1` | Offset between the S axis and the L axis, along the arm (mm) | 40 |
| `A2` | Lower arm: L axis to U axis (mm) | 445 |
| `A3` | Elbow offset: U axis to the forearm axis (mm) | 40 |
| `D4` | Forearm: U axis to the wrist (mm) | 440 |
| `D5` | Wrist offset along the B axis (mm). 0 for a spherical wrist | 0 |
| `D6` | Wrist to flange, along the T axis (mm) | 80 |
| `Theta2` | DH angle of the L axis at zero pulse (degrees) | -90 |
| `Theta3` | DH angle of the U axis at zero pulse (degrees) | 0 |
| `Theta5` | DH angle of the B axis at zero pulse (degrees) | 0 |
The parameters use the modified DH convention (Craig). `KinematicsCategory` tells which solver is used: `Opw` when `D5` is 0, `J5OffsetWrist` otherwise.
## From the catalog
`ArmKinematicModels` lists 169 models: GP (33), MH (48), ES (14), SP (14), HC (15), HP (7), AR (6), MS (6), PH (5), MotoMINI and others. `FromArmKinematicModel` returns their parameters. `FromArmKinematicModelName` finds a model by its name, and returns `null` when the name is not known.
**C# : KinematicsModels**
```csharp
using UnderAutomation.Yaskawa.Common;
using UnderAutomation.Yaskawa.Kinematics;
public class KinematicsModels
{
static void Main()
{
/**/
// From the enumeration: 169 models of the catalog
DhParameters gp7 = DhParameters.FromArmKinematicModel(ArmKinematicModels.GP7);
// From the name of the model, case ignored. Null if the model is not known.
DhParameters hc10 = DhParameters.FromArmKinematicModelName("HC10");
Console.WriteLine(gp7); // A1=40, A2=445, A3=40, D4=440, D5=0, D6=80...
Console.WriteLine(gp7.KinematicsCategory); // Opw
Console.WriteLine(hc10.KinematicsCategory); // J5OffsetWrist
// Every model of the catalog
foreach (ArmKinematicModels model in Enum.GetValues(typeof(ArmKinematicModels)))
Console.WriteLine(model);
/**/
}
}
```
**Python : KinematicsModels**
```python
from underautomation.yaskawa.common.dh_parameters import DhParameters
from underautomation.yaskawa.kinematics.arm_kinematic_models import ArmKinematicModels
from underautomation.yaskawa.kinematics.kinematics_utils import KinematicsUtils
##
# From the enumeration: 169 models of the catalog
gp7 = DhParameters.from_arm_kinematic_model(ArmKinematicModels.GP7)
# From the name of the model, case ignored. None if the model is not known.
hc10 = DhParameters.from_arm_kinematic_model_name("HC10")
print(gp7) # A1=40, A2=445, A3=40, D4=440, D5=0, D6=80...
print(gp7.kinematics_category.name) # Opw
print(hc10.kinematics_category.name) # J5OffsetWrist
# Every model of the catalog
for model in ArmKinematicModels:
print(model.name)
##
```
Some models have several variants, with the order code in the name (for example `HC10DT_1_06VXHC10_B10`). Use the variant of the name plate of your robot. Do not store the integer value of the enumeration: new models are added in alphabetical order and shift the values. Store the name.
## From the controller
The `ALL.PRM` file of a controller contains the geometry of its robot. `FromPrmFile` reads a file saved on the PC, `FromPrmContent` the text of the file. DX100, DX200, FS100, YRC1000 and YRC1000micro files are supported. The parameters of the first robot (R1) are read.
**C# : KinematicsPrmFile**
```csharp
using UnderAutomation.Yaskawa;
using UnderAutomation.Yaskawa.Common;
using UnderAutomation.Yaskawa.Kinematics;
public class KinematicsPrmFile
{
static void Main()
{
/**/
// ALL.PRM saved from the controller, on the PC
DhParameters fromFile = DhParameters.FromPrmFile(@"C:\Backup\ALL.PRM");
// Or downloaded from the controller (1.4 MB, about 13 s on a YRC1000micro)
var parameters = new ConnectParameters("192.168.0.1");
parameters.Ftp.Enable = true;
var robot = new YaskawaRobot();
robot.Connect(parameters);
string content = robot.Ftp.GetFile("ALL.PRM");
DhParameters dh = DhParameters.FromPrmContent(content);
// Joint solutions of the current position (tool 0, robot frame)
var position = robot.HighSpeedEServer.GetRobotCartesianPosition();
foreach (JointsAngles solution in KinematicsUtils.InverseKinematics(position, dh))
Console.WriteLine(solution);
robot.Disconnect();
/**/
}
}
```
**Python : KinematicsPrmFile**
```python
from underautomation.yaskawa.yaskawa_robot import YaskawaRobot
from underautomation.yaskawa.connect_parameters import ConnectParameters
from underautomation.yaskawa.common.dh_parameters import DhParameters
from underautomation.yaskawa.kinematics.kinematics_utils import KinematicsUtils
##
# ALL.PRM saved from the controller, on the PC
from_file = DhParameters.from_prm_file(r"C:\Backup\ALL.PRM")
# Or downloaded from the controller (1.4 MB, about 13 s on a YRC1000micro)
parameters = ConnectParameters("192.168.0.1")
parameters.ftp.enable = True
robot = YaskawaRobot()
robot.connect(parameters)
content = robot.ftp.get_file("ALL.PRM")
dh = DhParameters.from_prm_content(content)
# Joint solutions of the current position (tool 0, robot frame)
position = robot.high_speed_e_server.get_robot_cartesian_position()
for solution in KinematicsUtils.inverse_kinematics(position, dh):
print(solution)
robot.disconnect()
##
```
Download `ALL.PRM` with [FTP](/yaskawa/documentation/ftp-transfer), [HTTP](/yaskawa/documentation/http) or the [High Speed Ethernet Server](/yaskawa/documentation/hses-files). The file is about 1.4 MB: FTP and HTTP take about 13 s on a YRC1000micro, the High Speed Ethernet Server about 45 s. Save it once, then use `FromPrmFile`.
On a MotoMINI, the parameters read from `ALL.PRM` are equal to `ArmKinematicModels.MotoMINI` of the catalog. The file is the right choice for a model that is not in the catalog, or to check the model of a robot.
A file of a robot with a structure that is not supported throws a `NotSupportedException`. See [Supported robots](/yaskawa/documentation/kinematics#supported_robots).
## Your own values
The constructor takes `A1`, `A2`, `A3`, `D4`, `D5`, `D6` in mm, then `Theta2`, `Theta3`, `Theta5` in degrees. Two `DhParameters` with the same values are equal.
**C# : KinematicsCustomDh**
```csharp
using UnderAutomation.Yaskawa.Common;
using UnderAutomation.Yaskawa.Kinematics;
public class KinematicsCustomDh
{
static void Main()
{
/**/
// A1, A2, A3, D4, D5, D6 in mm, then Theta2, Theta3, Theta5 in degrees
var dh = new DhParameters(40, 445, 40, 440, 0, 80, -90, 0, 0);
// Same values as the catalog: the same geometry
bool sameAsGp7 = dh.Equals(DhParameters.FromArmKinematicModel(ArmKinematicModels.GP7));
// The solver is chosen from the values: D5 = 0 is a spherical wrist
Console.WriteLine(dh.KinematicsCategory); // Opw
/**/
}
}
```
**Python : KinematicsCustomDh**
```python
from underautomation.yaskawa.common.dh_parameters import DhParameters
from underautomation.yaskawa.kinematics.arm_kinematic_models import ArmKinematicModels
##
# A1, A2, A3, D4, D5, D6 in mm, then Theta2, Theta3, Theta5 in degrees
dh = DhParameters(40, 445, 40, 440, 0, 80, -90, 0, 0)
# Same values as the catalog: the same geometry
same_as_gp7 = dh == DhParameters.from_arm_kinematic_model(ArmKinematicModels.GP7)
# The solver is chosen from the values: D5 = 0 is a spherical wrist
print(dh.kinematics_category.name) # Opw
##
```
`DhParameters` implements `IDhParameters`: your own class can also implement this interface and be passed to `KinematicsUtils`.
## Reference
**Members of Common.DhParameters**
```csharp
public class DhParameters : IDhParameters {
// Initializes a new instance of with zero lengths and standard home angles
// ( = -90, = 0, = 0).
public DhParameters()
// Initializes a new instance of with the specified values.
public DhParameters(double a1, double a2, double a3, double d4, double d5, double d6, double theta2, double theta3, double theta5)
// Initializes a new instance of by copying an existing .
public DhParameters(IDhParameters parameters)
// Offset between the S axis and the L axis, along the arm (mm).
public double A1 { get; set; }
// Lower arm length, between the L axis and the U axis (mm).
public double A2 { get; set; }
// Elbow offset, between the U axis and the forearm axis (mm).
public double A3 { get; set; }
// Forearm length, between the U axis and the wrist (mm).
public double D4 { get; set; }
// Wrist offset along the B axis (mm). Zero for a spherical wrist.
public double D5 { get; set; }
// Distance between the wrist and the flange, along the T axis (mm).
public double D6 { get; set; }
public override bool Equals(object obj)
// Returns the DH parameters of a known robot model.
public static DhParameters FromArmKinematicModel(ArmKinematicModels model)
// Returns the DH parameters of a known robot model, from its name (for example "GP7" or "HC10DTP").
// The comparison ignores case.
public static DhParameters FromArmKinematicModelName(string modelName)
// Reads the DH parameters of robot group 1 from the text content of an ALL.PRM parameter file.
// DX100, DX200, FS100, YRC1000 and YRC1000micro files are supported.
public static DhParameters FromPrmContent(string content)
// Reads the DH parameters of robot group 1 from an ALL.PRM parameter file saved from a controller.
// DX100, DX200, FS100, YRC1000 and YRC1000micro files are supported.
public static DhParameters FromPrmFile(string path)
public override int GetHashCode()
// Kinematic structure of the arm: when is 0,
// otherwise.
public KinematicsCategory KinematicsCategory { get; }
// DH angle of the L axis when the L axis is at zero pulse (degrees).
public double Theta2 { get; set; }
// DH angle of the U axis when the U axis is at zero pulse (degrees).
public double Theta3 { get; set; }
// DH angle of the B axis when the B axis is at zero pulse (degrees).
public double Theta5 { get; set; }
public override string ToString()
}
```
**Members of Common.IDhParameters**
```csharp
public interface IDhParameters {
// Offset between the S axis and the L axis, along the arm (mm).
double A1 { get; }
// Lower arm length, between the L axis and the U axis (mm).
double A2 { get; }
// Elbow offset, between the U axis and the forearm axis (mm).
double A3 { get; }
// Forearm length, between the U axis and the wrist (mm).
double D4 { get; }
// Wrist offset along the B axis (mm). Zero for a spherical wrist.
double D5 { get; }
// Distance between the wrist and the flange, along the T axis (mm).
double D6 { get; }
// DH angle of the L axis when the L axis is at zero pulse (degrees).
double Theta2 { get; }
// DH angle of the U axis when the U axis is at zero pulse (degrees).
double Theta3 { get; }
// DH angle of the B axis when the B axis is at zero pulse (degrees).
double Theta5 { get; }
}
```
**Members of Kinematics.ArmKinematicModels**
```csharp
public enum ArmKinematicModels {
// AR1440
[ArmModel("AR1440", 155, 614, 200, 640, 0, 100, -90, 0, 0)]
AR1440 = 0
// AR1730
[ArmModel("AR1730", 150, 760, 200, 795, 0, 100, -90, 0, 0)]
AR1730 = 1
// AR2010
[ArmModel("AR2010", 150, 760, 200, 1082, 0, 100, -90, 0, 0)]
AR2010 = 2
// AR3120
[ArmModel("AR3120", 145, 1150, 250, 1812, 0, 100, -90, 0, 0)]
AR3120 = 3
// AR700
[ArmModel("AR700", 40, 345, 40, 340, 0, 80, -90, 0, 0)]
AR700 = 4
// AR900
[ArmModel("AR900", 40, 445, 40, 440, 0, 80, -90, 0, 0)]
AR900 = 5
// DX1350D
[ArmModel("DX1350D", 200, 600, 75, 550, 0, 120, -90, 0, 0)]
DX1350D = 6
// EP4000D
[ArmModel("EP4000D", 550, 1100, 250, 2135, 0, 255, 0, 0, 0)]
EP4000D = 7
// EPH130D
[ArmModel("EPH130D", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
EPH130D = 8
// EPH400D
[ArmModel("EPH400D", 550, 1100, 250, 2135, 0, 255, 0, 0, 0)]
EPH400D = 9
// EPX1250
[ArmModel("EPX1250", 200, 520, 130, 520, 0, 86.5, -90, 0, 0)]
EPX1250 = 10
// ES0165D-A00
[ArmModel("ES0165D-A00", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
ES0165D_A00 = 11
// ES0165D-A10
[ArmModel("ES0165D-A10", 285, 1150, 250, 1590, 0, 225, -90, 0, 0)]
ES0165D_A10 = 12
// ES0165D-B00
[ArmModel("ES0165D-B00", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
ES0165D_B00 = 13
// ES0165D-B10
[ArmModel("ES0165D-B10", 285, 1150, 250, 1590, 0, 225, -90, 0, 0)]
ES0165D_B10 = 14
// ES0165D-Z10
[ArmModel("ES0165D-Z10", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
ES0165D_Z10 = 15
// ES0200D
[ArmModel("ES0200D", 285, 1150, 250, 1225, 0, 250, -90, 0, 0)]
ES0200D = 16
// ES0280D
[ArmModel("ES0280D", 285, 1150, 250, 1225, 0, 250, -90, 0, 0)]
ES0280D = 17
// ES165RD
[ArmModel("ES165RD", 740, 1150, 250, 1225, 0, 225, 0, 0, 0)]
ES165RD = 18
// ES200D
[ArmModel("ES200D", 285, 1150, 250, 1225, 0, 250, -90, 0, 0)]
ES200D = 19
// ES200RD-A00-Proto
[ArmModel("ES200RD-A00-Proto", 740, 1150, 250, 1225, 0, 250, 0, 0, 0)]
ES200RD_A00_Proto = 20
// ES200RD-A10
[ArmModel("ES200RD-A10", 740, 1150, 250, 2100, 0, 225, 0, 0, 0)]
ES200RD_A10 = 21
// ES200RD-J00
[ArmModel("ES200RD-J00", 740, 1150, 250, 1225, 0, 250, 0, 0, 0)]
ES200RD_J00 = 22
// ES200RD-Pack-Proto
[ArmModel("ES200RD-Pack-Proto", 740, 1150, 250, 1225, 0, 250, 0, 0, 0)]
ES200RD_Pack_Proto = 23
// ES280D
[ArmModel("ES280D", 285, 1150, 250, 1225, 0, 250, -90, 0, 0)]
ES280D = 24
// GA50
[ArmModel("GA50", 330, 870, 250, 800, 0, 175, -90, 0, 0)]
GA50 = 25
// GG250
[ArmModel("GG250", 285, 1150, 300, 1275, 0, 250, -90, 0, 0)]
GG250 = 26
// GP110
[ArmModel("GP110", 320, 870, 235, 1020, 0, 200, -90, 0, 0)]
GP110 = 27
// GP110H
[ArmModel("GP110H", 320, 870, 300, 800, 0, 250, -90, 0, 0)]
GP110H = 28
// GP12
[ArmModel("GP12", 155, 614, 200, 640, 0, 100, -90, 0, 0)]
GP12 = 29
// GP165R
[ArmModel("GP165R", 740, 1150, 250, 1225, 0, 225, 0, 0, 0)]
GP165R = 30
// GP180
[ArmModel("GP180", 325, 1150, 300, 1225, 0, 225, -90, 0, 0)]
GP180 = 31
// GP180H
[ArmModel("GP180H", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
GP180H = 32
// GP180-120
[ArmModel("GP180-120", 325, 1150, 300, 1590, 0, 225, -90, 0, 0)]
GP180_120 = 33
// GP200R
[ArmModel("GP200R", 740, 1150, 250, 1225, 0, 250, 0, 0, 0)]
GP200R = 34
// GP200S
[ArmModel("GP200S", 325, 700, 300, 830, 0, 250, -90, 0, 0)]
GP200S = 35
// GP20HL
[ArmModel("GP20HL", 145, 1150, 250, 1812, 0, 100, -90, 0, 0)]
GP20HL = 36
// GP215
[ArmModel("GP215", 285, 1150, 250, 1490, 0, 250, -90, 0, 0)]
GP215 = 37
// GP225
[ArmModel("GP225", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
GP225 = 38
// GP225H
[ArmModel("GP225H", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
GP225H = 39
// GP25
[ArmModel("GP25", 150, 760, 200, 795, 0, 100, -90, 0, 0)]
GP25 = 40
// GP250
[ArmModel("GP250", 285, 1150, 250, 1285, 0, 250, -90, 0, 0)]
GP250 = 41
// GP25SV
[ArmModel("GP25SV", -150, 614, 200, 795, 0, 100, -90, 0, 0)]
GP25SV = 42
// GP25-12
[ArmModel("GP25-12", 150, 760, 200, 1082, 0, 100, -90, 0, 0)]
GP25_12 = 43
// GP280
[ArmModel("GP280", 285, 1150, 250, 1015, 0, 250, -90, 0, 0)]
GP280 = 44
// GP280L
[ArmModel("GP280L", 270, 1250, 300, 1566, 0, 270, -90, 0, 0)]
GP280L = 45
// GP300R
[ArmModel("GP300R", 750, 1050, 280, 1400, 0, 250, 0, 0, 0)]
GP300R = 46
// GP35H
[ArmModel("GP35H", 145, 870, 250, 1025, 0, 175, -90, 0, 0)]
GP35H = 47
// GP35L
[ArmModel("GP35L", 145, 1150, 210, 1225, 0, 175, -90, 0, 0)]
GP35L = 48
// GP360
[ArmModel("GP360", 270, 1250, 300, 1277, 0, 270, -90, 0, 0)]
GP360 = 49
// GP4
[ArmModel("GP4", 0, 260, 15, 290, 0, 72, -90, 0, 0)]
GP4 = 50
// GP400
[ArmModel("GP400", 400, 1050, 250, 1605, 0, 300, -90, 0, 0)]
GP400 = 51
// GP400R
[ArmModel("GP400R", 280, 1100, 250, 2135, 0, 255, 0, 0, 0)]
GP400R = 52
// GP50
[ArmModel("GP50", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
GP50 = 53
// GP600
[ArmModel("GP600", 400, 1050, 250, 1605, 0, 300, -90, 0, 0)]
GP600 = 54
// GP7
[ArmModel("GP7", 40, 445, 40, 440, 0, 80, -90, 0, 0)]
GP7 = 55
// GP70L
[ArmModel("GP70L", 320, 1165, 235, 1225, 0, 175, -90, 0, 0)]
GP70L = 56
// GP8
[ArmModel("GP8", 40, 345, 40, 340, 0, 80, -90, 0, 0)]
GP8 = 57
// GP88
[ArmModel("GP88", 320, 870, 210, 1025, 0, 175, -90, 0, 0)]
GP88 = 58
// GP8L
[ArmModel("GP8L", 155, 714, 200, 740, 0, 80, -90, 0, 0)]
GP8L = 59
// HC10
[ArmModel("HC10", 0, 700, 0, 500, 162, 130, -90, 90, 0)]
HC10 = 60
// HC10DTF
[ArmModel("HC10DTF", 0, 700, 0, 500, 162, 170, -90, 0, 0)]
HC10DTF = 61
// HC10DTFP
[ArmModel("HC10DTFP", 0, 700, 0, 500, 162, 170, -90, 0, 0)]
HC10DTFP = 62
// HC10DTP
[ArmModel("HC10DTP", 0, 700, 0, 500, 162, 170, -90, 0, 0)]
HC10DTP = 63
// HC10DT_1-06VXHC10-A10
[ArmModel("HC10DT_1-06VXHC10-A10", 0, 700, 0, 500, 162, 170, -90, 90, 0)]
HC10DT_1_06VXHC10_A10 = 64
// HC10DT_1-06VXHC10-B10
[ArmModel("HC10DT_1-06VXHC10-B10", 0, 700, 0, 500, 162, 170, -90, 0, 0)]
HC10DT_1_06VXHC10_B10 = 65
// HC10DT_1-06VXHC10-B11
[ArmModel("HC10DT_1-06VXHC10-B11", 0, 700, 0, 500, 162, 170, -90, 0, 0)]
HC10DT_1_06VXHC10_B11 = 66
// HC10DT_1-06VXHC10-B12
[ArmModel("HC10DT_1-06VXHC10-B12", 0, 700, 0, 500, 162, 170, -90, 0, 0)]
HC10DT_1_06VXHC10_B12 = 67
// HC10DT_1-06VXHC10-C11
[ArmModel("HC10DT_1-06VXHC10-C11", 0, 700, 0, 500, 162, 170, -90, 90, 0)]
HC10DT_1_06VXHC10_C11 = 68
// HC10SDTP
[ArmModel("HC10SDTP", 0, 550, 0, 350, 162, 170, -90, 0, 0)]
HC10SDTP = 69
// HC20DT
[ArmModel("HC20DT", 0, 820, 0, 880, 0, 200, -90, 0, 0)]
HC20DT = 70
// HC20DTP
[ArmModel("HC20DTP", 0, 820, 0, 880, 0, 200, -90, 0, 0)]
HC20DTP = 71
// HC20SDT
[ArmModel("HC20SDT", 0, 725, 0, 475, 185, 200, -90, 0, 0)]
HC20SDT = 72
// HC20SDTP
[ArmModel("HC20SDTP", 0, 725, 0, 475, 185, 200, -90, 0, 0)]
HC20SDTP = 73
// HC30PL
[ArmModel("HC30PL", 0, 820, 0, 880, 0, 200, -90, 0, 90)]
HC30PL = 74
// HP0020D-A00
[ArmModel("HP0020D-A00", 150, 760, 140, 795, 0, 105, -90, 0, 90)]
HP0020D_A00 = 75
// HP0020D-A10
[ArmModel("HP0020D-A10", 150, 760, 140, 995, 0, 105, -90, 0, 90)]
HP0020D_A10 = 76
// HP0020D-B00
[ArmModel("HP0020D-B00", 150, 760, 140, 795, 0, 105, -90, 0, 90)]
HP0020D_B00 = 77
// HP0020D-B10
[ArmModel("HP0020D-B10", 150, 760, 140, 995, 0, 105, -90, 0, 90)]
HP0020D_B10 = 78
// HP0020F
[ArmModel("HP0020F", 150, 760, 140, 795, 0, 105, -90, 0, 90)]
HP0020F = 79
// HP0165D
[ArmModel("HP0165D", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
HP0165D = 80
// HP020RD
[ArmModel("HP020RD", 450, 760, 140, 795, 0, 105, 0, 0, 0)]
HP020RD = 81
// MA02010
[ArmModel("MA02010", 150, 760, 200, 1082, 0, 100, -90, 0, 0)]
MA02010 = 82
// MA03120
[ArmModel("MA03120", 145, 1150, 200, 1815, 0, 100, -90, 0, 0)]
MA03120 = 83
// MA1440
[ArmModel("MA1440", 155, 614, 200, 640, 0, 100, -90, 0, 0)]
MA1440 = 84
// MC02000
[ArmModel("MC02000", 330, 870, 250, 800, 0, 175, -90, 0, 0)]
MC02000 = 85
// MCL0020
[ArmModel("MCL0020", 150, 730, 140, 765, 0, 105, -90, 0, 90)]
MCL0020 = 86
// MCL020F
[ArmModel("MCL020F", 150, 730, 140, 765, 0, 105, -90, 0, 90)]
MCL020F = 87
// MH00005
[ArmModel("MH00005", 88, 310, 40, 305, 0, 86.5, -90, 0, 0)]
MH00005 = 88
// MH00006-A00
[ArmModel("MH00006-A00", 150, 614, 155, 640, 0, 95, -90, 0, 90)]
MH00006_A00 = 89
// MH00006-A30
[ArmModel("MH00006-A30", 150, 614, 155, 640, 0, 95, -90, 0, 90)]
MH00006_A30 = 90
// MH00006-B00
[ArmModel("MH00006-B00", 150, 614, 155, 640, 0, 95, -90, 0, 90)]
MH00006_B00 = 91
// MH00006-B30
[ArmModel("MH00006-B30", 150, 614, 155, 640, 0, 95, -90, 0, 90)]
MH00006_B30 = 92
// MH00006-C00
[ArmModel("MH00006-C00", 150, 614, 155, 640, 0, 100, -90, 0, 90)]
MH00006_C00 = 93
// MH0000J
[ArmModel("MH0000J", 0, 275, 0, 270, 0, 63, -90, 0, 0)]
MH0000J = 94
// MH00024-A00
[ArmModel("MH00024-A00", 150, 760, 200, 795, 0, 100, -90, 0, 0)]
MH00024_A00 = 95
// MH00024-A10
[ArmModel("MH00024-A10", 150, 760, 200, 1082, 0, 100, -90, 0, 0)]
MH00024_A10 = 96
// MH00024-Z00-Proto
[ArmModel("MH00024-Z00-Proto", 150, 760, 200, 795, 0, 100, -90, 0, 0)]
MH00024_Z00_Proto = 97
// MH0003F
[ArmModel("MH0003F", 0, 260, 30, 270, 0, 90, -90, 0, 0)]
MH0003F = 98
// MH00050-A00
[ArmModel("MH00050-A00", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
MH00050_A00 = 99
// MH00050-A10
[ArmModel("MH00050-A10", 145, 1150, 200, 1800, 0, 105, -90, 0, 90)]
MH00050_A10 = 100
// MH00050-A20
[ArmModel("MH00050-A20", 145, 1150, 210, 1225, 0, 175, -90, 0, 0)]
MH00050_A20 = 101
// MH00050-B00
[ArmModel("MH00050-B00", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
MH00050_B00 = 102
// MH00050-B10
[ArmModel("MH00050-B10", 145, 1150, 200, 1800, 0, 105, -90, 0, 90)]
MH00050_B10 = 103
// MH00050-B20
[ArmModel("MH00050-B20", 145, 1150, 210, 1225, 0, 175, -90, 0, 0)]
MH00050_B20 = 104
// MH00050-J00
[ArmModel("MH00050-J00", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
MH00050_J00 = 105
// MH00050-J10
[ArmModel("MH00050-J10", 145, 1150, 200, 1800, 0, 105, -90, 0, 90)]
MH00050_J10 = 106
// MH00050-J20
[ArmModel("MH00050-J20", 145, 1150, 210, 1225, 0, 175, -90, 0, 0)]
MH00050_J20 = 107
// MH00050-Z00
[ArmModel("MH00050-Z00", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
MH00050_Z00 = 108
// MH0005F
[ArmModel("MH0005F", 88, 310, 40, 305, 0, 80, -90, 0, 0)]
MH0005F = 109
// MH0005L
[ArmModel("MH0005L", 88, 400, 40, 405, 0, 86.5, -90, 0, 0)]
MH0005L = 110
// MH0005S
[ArmModel("MH0005S", 88, 310, 40, 305, 0, 80, -90, 0, 0)]
MH0005S = 111
// MH0006F
[ArmModel("MH0006F", 150, 614, 155, 640, 0, 95, -90, 0, 90)]
MH0006F = 112
// MH0006S
[ArmModel("MH0006S", 150, 305, 155, 520, 0, 95, -90, 0, 90)]
MH0006S = 113
// MH00080
[ArmModel("MH00080", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
MH00080 = 114
// MH00165-A00
[ArmModel("MH00165-A00", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
MH00165_A00 = 115
// MH00165-A10
[ArmModel("MH00165-A10", 285, 1150, 250, 1590, 0, 225, -90, 0, 0)]
MH00165_A10 = 116
// MH00165-B00
[ArmModel("MH00165-B00", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
MH00165_B00 = 117
// MH00200
[ArmModel("MH00200", 285, 1150, 250, 1225, 0, 250, -90, 0, 0)]
MH00200 = 118
// MH00215
[ArmModel("MH00215", 285, 1150, 250, 1490, 0, 250, -90, 0, 0)]
MH00215 = 119
// MH00250
[ArmModel("MH00250", 285, 1150, 250, 1285, 0, 250, -90, 0, 0)]
MH00250 = 120
// MH00280
[ArmModel("MH00280", 285, 1150, 250, 1015, 0, 250, -90, 0, 0)]
MH00280 = 121
// MH003BM
[ArmModel("MH003BM", 0, 260, 30, 270, 0, 90, -90, 0, 0)]
MH003BM = 122
// MH00400
[ArmModel("MH00400", 400, 1050, 250, 1605, 0, 300, -90, 0, 0)]
MH00400 = 123
// MH005BM
[ArmModel("MH005BM", 0, 350, 40, 350, 0, 115, -90, 0, 0)]
MH005BM = 124
// MH005LF
[ArmModel("MH005LF", 88, 400, 40, 405, 0, 80, -90, 0, 0)]
MH005LF = 125
// MH005LS
[ArmModel("MH005LS", 88, 400, 40, 405, 0, 80, -90, 0, 0)]
MH005LS = 126
// MH00600
[ArmModel("MH00600", 400, 1050, 250, 1605, 0, 300, -90, 0, 0)]
MH00600 = 127
// MH006SF
[ArmModel("MH006SF", 150, 305, 155, 520, 0, 95, -90, 0, 90)]
MH006SF = 128
// MH00900
[ArmModel("MH00900", 500, 1700, 350, 2480, 0, 440, -90, 0, 0)]
MH00900 = 129
// MH110
[ArmModel("MH110", 320, 870, 235, 1020, 0, 200, -90, 0, 0)]
MH110 = 130
// MH12
[ArmModel("MH12", 155, 614, 200, 640, 0, 100, -90, 0, 0)]
MH12 = 131
// MH180-A00
[ArmModel("MH180-A00", 325, 1150, 300, 1225, 0, 225, -90, 0, 0)]
MH180_A00 = 132
// MH180-A10
[ArmModel("MH180-A10", 325, 1150, 300, 1590, 0, 225, -90, 0, 0)]
MH180_A10 = 133
// MH180-C00
[ArmModel("MH180-C00", 325, 1150, 300, 1225, 0, 225, -90, 0, 0)]
MH180_C00 = 134
// MH225
[ArmModel("MH225", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
MH225 = 135
// MHP045L
[ArmModel("MHP045L", 0, 1400, 0, 1450, 0, 175, -90, 0, 0)]
MHP045L = 136
// MPL0080
[ArmModel("MPL0080", 145, 870, 210, 1025, 0, 175, -90, 0, 90)]
MPL0080 = 137
// MPX1150
[ArmModel("MPX1150", 0, 320, 75, 400, 0, 86.5, -90, 0, 0)]
MPX1150 = 138
// MPX1400
[ArmModel("MPX1400", 200, 520, 130, 520, 0, 86.5, -90, 0, 0)]
MPX1400 = 139
// MPX1950
[ArmModel("MPX1950", 0, 725, 0, 725, 0, 100, -90, 0, 0)]
MPX1950 = 140
// MS00080
[ArmModel("MS00080", 145, 870, 210, 1025, 0, 175, -90, 0, 0)]
MS00080 = 141
// MS00120
[ArmModel("MS00120", 100, 750, 300, 900, 0, 225, -90, 0, 0)]
MS00120 = 142
// MS0080W
[ArmModel("MS0080W", 320, 870, 210, 1025, 0, 175, -90, 0, 0)]
MS0080W = 143
// MS100
[ArmModel("MS100", 320, 870, 235, 1020, 0, 200, -90, 0, 0)]
MS100 = 144
// MS165
[ArmModel("MS165", 325, 1150, 300, 1225, 0, 225, -90, 0, 0)]
MS165 = 145
// MS210
[ArmModel("MS210", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
MS210 = 146
// MotoMINI
[ArmModel("MotoMINI", 20, 165, 0, 165, 0, 40, -90, 0, 90)]
MotoMINI = 147
// PH130F
[ArmModel("PH130F", 285, 1150, 250, 1225, 0, 225, -90, 0, 0)]
PH130F = 148
// PH130RF
[ArmModel("PH130RF", 720, 1050, 250, 1700, 0, 230, 0, 0, 0)]
PH130RF = 149
// PH13RLD
[ArmModel("PH13RLD", 720, 1050, 250, 1700, 0, 230, 0, 0, 0)]
PH13RLD = 150
// PH200R
[ArmModel("PH200R", 550, 1100, 250, 2135, 0, 255, 0, 0, 0)]
PH200R = 151
// PH200RF
[ArmModel("PH200RF", 550, 1100, 250, 2135, 0, 255, 0, 0, 0)]
PH200RF = 152
// SP100
[ArmModel("SP100", 320, 870, 235, 1020, 0, 200, -90, 0, 0)]
SP100 = 153
// SP110H
[ArmModel("SP110H", 320, 870, 300, 800, 0, 250, -90, 0, 0)]
SP110H = 154
// SP130
[ArmModel("SP130", 320, 870, 235, 1020, 0, 200, -90, 0, 0)]
SP130 = 155
// SP150R
[ArmModel("SP150R", 740, 1150, 250, 1225, 0, 225, 0, 0, 0)]
SP150R = 156
// SP165
[ArmModel("SP165", 325, 1150, 300, 1225, 0, 225, -90, 0, 0)]
SP165 = 157
// SP165-105
[ArmModel("SP165-105", 325, 1150, 300, 1590, 0, 225, -90, 0, 0)]
SP165_105 = 158
// SP180H
[ArmModel("SP180H", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
SP180H = 159
// SP180H-110
[ArmModel("SP180H-110", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
SP180H_110 = 160
// SP185R
[ArmModel("SP185R", 740, 1150, 250, 1225, 0, 250, 0, 0, 0)]
SP185R = 161
// SP210
[ArmModel("SP210", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
SP210 = 162
// SP225H
[ArmModel("SP225H", 325, 1150, 300, 1225, 0, 250, -90, 0, 0)]
SP225H = 163
// SP225H-135
[ArmModel("SP225H-135", 325, 1150, 300, 1480, 0, 250, -90, 0, 0)]
SP225H_135 = 164
// SP235
[ArmModel("SP235", 285, 1150, 250, 1285, 0, 250, -90, 0, 0)]
SP235 = 165
// SP80
[ArmModel("SP80", 320, 870, 210, 1025, 0, 175, -90, 0, 0)]
SP80 = 166
// UP0350D
[ArmModel("UP0350D", 280, 1050, 250, 1320, 0, 270, -120, 0, 0)]
UP0350D = 167
// UP400RD
[ArmModel("UP400RD", 280, 1100, 250, 2135, 0, 255, 0, 0, 0)]
UP400RD = 168
}
```
## What to read next
- [Offline kinematics](/yaskawa/documentation/kinematics): forward and inverse kinematics.
- [FTP file transfers](/yaskawa/documentation/ftp-transfer): download `ALL.PRM` and the other files of the controller.