Joint & Cartesian motions
Chain joint, linear and circular motions with FINE, CNT and CR terminations, waits and I/O, in tool and user frames.
Path builders describe a trajectory as the instructions of a TP program. Each method adds a motion and returns the builder, so the calls can be chained. Build() creates the trajectory.
Joint motions
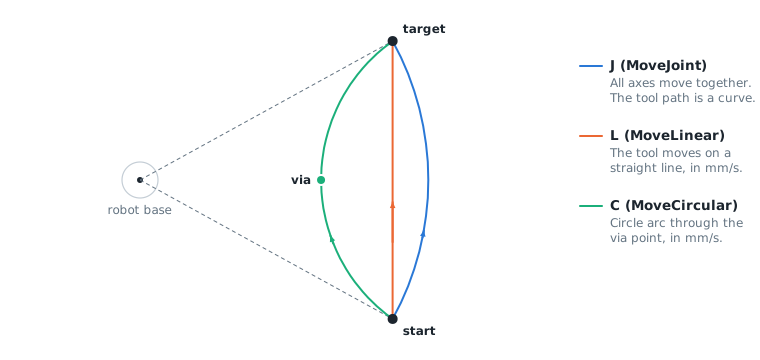
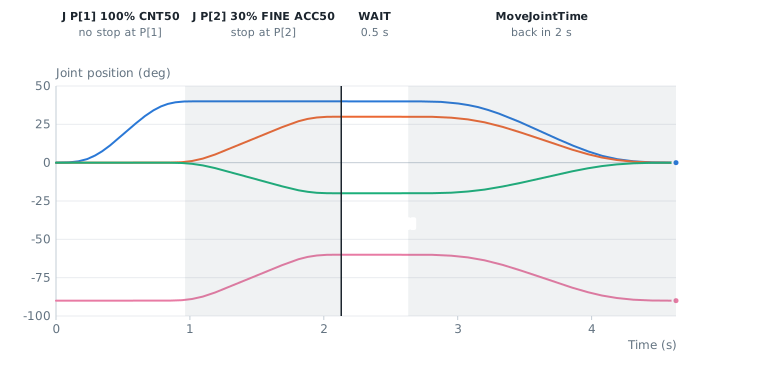
A joint motion moves all axes together on a straight line in joint space: they start and stop at the same time.
new double[] { 1125, 1125, 1687, 2530, 1265, 2530 });var cartesianLimits = new CartesianLimits(500, 2000, 10000, 90, 360, 1800);var planner = new MotionPlanner(jointLimits, null);var start = new JointValues(0, 0, 0, 0, -90, 0);var p1 = new JointValues(40, 0, 0, 0, -90, 0);var p2 = new JointValues(40, 30, -20, 0, -60, 0);Trajectory trajectory = planner.CreateJointPath(start).MoveJoint(p1, 100, FanucMotion.Cnt(50)) // J P[1] 100% CNT50.MoveJoint(p2, 30, FanucMotion.Fine(), 50) // J P[2] 30% FINE ACC50.SetIO(FanucMotion.Signal(IOType.DO, 1), true) // DO[1]=ON when the robot is at P[2].Wait(0.5) // WAIT 0.50(sec).MoveJointTime(start, 2.0, FanucMotion.Fine()) // back in 2 s.Build();}}
| Method | TP equivalent |
|---|---|
MoveJoint(target, speedPercent, termination, accelerationPercent) | J P[1] 50% CNT100 ACC80 |
MoveJointTime(target, duration, termination) | Joint motion in a given time (longer if the limits need it) |
Wait(duration) | WAIT 0.50(sec) |
SetIO(FanucMotion.Signal(IOType.DO, 1), true) | DO[1]=ON after the previous motion |
MoveJointSpline(points, speedPercent, termination) | Smooth motion through several positions, see Splines & shapes |
Cartesian motions
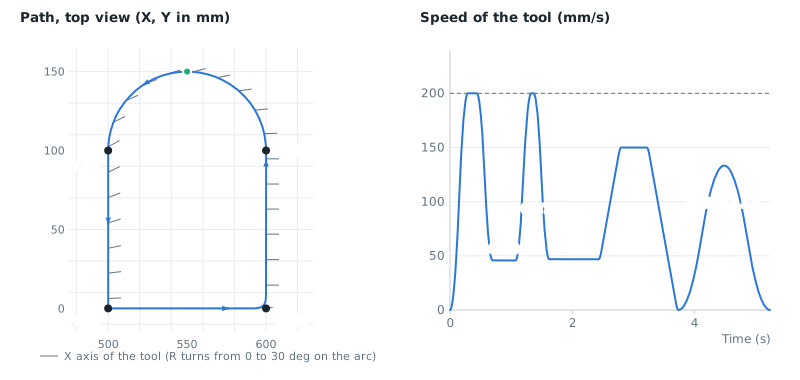
Linear and circular motions move the tool center point at the given speed in mm/s. The orientation turns progressively from the start orientation to the target orientation.
new double[] { 1125, 1125, 1687, 2530, 1265, 2530 });var cartesianLimits = new CartesianLimits(500, 2000, 10000, 90, 360, 1800);var planner = new MotionPlanner(jointLimits, cartesianLimits);// X, Y, Z, W, P, R: the W, P, R angles of FANUC use the fixed XYZ conventionFunc<double, double, double, double, double, double, CartesianPose> wpr =(x, y, z, w, p, r) => CartesianPose.FromEuler(x, y, z, w, p, r, EulerConvention.FixedXYZ);var start = wpr(500, 0, 300, 180, 0, 0);Trajectory trajectory = planner.CreateCartesianPath(start).MoveLinear(wpr(600, 0, 300, 180, 0, 0), 200, FanucMotion.Cr(10)) // L 200mm/sec CR10.MoveLinear(wpr(600, 100, 300, 180, 0, 0), 200, FanucMotion.Cnt(100)) // L 200mm/sec CNT100.MoveCircular(wpr(550, 150, 300, 180, 0, 0), // C via pointwpr(500, 100, 300, 180, 0, 30), 150, FanucMotion.Fine()) // target, 150mm/sec FINE.MoveLinearTime(start, 1.5, FanucMotion.Fine()) // back in 1.5 s.Build();// FANUC positions of the trajectory (W, P, R stay continuous)ExtendedCartesianPosition[] samples = FanucMotion.SampleCartesian(trajectory, 0.008);}}
| Method | TP equivalent |
|---|---|
MoveLinear(target, speed, termination, accelerationPercent) | L P[1] 200mm/sec CR10 |
MoveCircular(via, target, speed, termination, accelerationPercent) | C P[1] P[2] 150mm/sec FINE |
MoveLinearTime(target, duration, termination) | Linear motion in a given time |
The speed is reduced when the change of orientation, the curvature or the extended axes need it.
Terminations
| Termination | Behavior |
|---|---|
FanucMotion.Fine() | The robot stops at the target |
FanucMotion.Cnt(0..100) | The next motion starts during the deceleration of this one. CNT100 gives the smoothest motion. Joint and Cartesian |
FanucMotion.Cr(distance) | Corner region: the corner is replaced by a smooth curve that starts at this distance (mm) from the target, whatever the speed. Cartesian only, between L and C motions and splines |
These methods return a Termination of the planner: Termination.Stop(), Termination.Overlap(percent) and Termination.Corner(distance) give the same result.
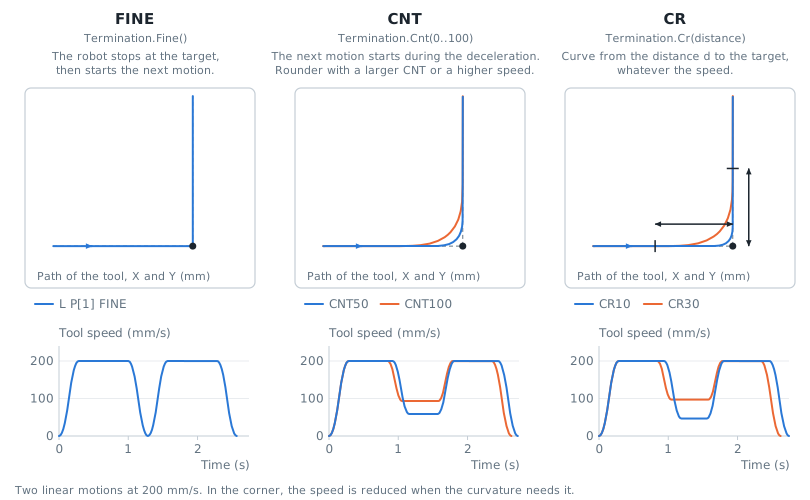
With CNT, the size of the rounded corner depends on the speed, as on a FANUC controller:
- Joint motions: the next motion starts during the deceleration of this one. The overlap is reduced automatically when the combination of both motions would exceed the limits.
- Linear and circular motions: the corner is replaced by a smooth curve that starts where the robot would start to decelerate (CNT100), or closer to the target (CNT50: half of this distance).
With CR, the corner geometry is fixed: the curve passes at about 0.12 x distance from the corner for a change of direction of 45 degrees, 0.25 x distance for 90 degrees and 0.4 x distance for 135 degrees. The distance is limited to half of the length of each motion.
In a CNT or CR curve, the speed is constant, and reduced when the curvature needs it: a sharp corner with a small distance is followed slowly. For a fast motion, use a larger CNT or CR distance.
Tool and user frames
By default, Cartesian positions are flange positions in the world frame. Set ToolFrame and UserFrame to give the targets as positions of a tool in a user frame, as with UTOOL and UFRAME on the teach pendant:
new double[] { 1125, 1125, 1687, 2530, 1265, 2530 });var cartesianLimits = new CartesianLimits(500, 2000, 10000, 90, 360, 1800);var planner = new MotionPlanner(jointLimits, cartesianLimits);// Targets are positions of this tool, in this user frameplanner.ToolFrame = FanucMotion.ToCartesianPose(new XYZWPRPosition(0, 0, 150, 0, 0, 0)); // UTOOL: 150 mm along Z of the flangeplanner.UserFrame = FanucMotion.ToCartesianPose(new XYZWPRPosition(800, -200, 0, 0, 0, 90)); // UFRAME, relative to the world frame// The start is the position of the robot (flange in the world frame)var builder = planner.CreateCartesianPath(FanucMotion.ToCartesianPose(new XYZWPRPosition(700, 0, 400, 180, 0, 0)));// EndPosition gives the same position as a tool position in the user frameCartesianPose tcp = builder.EndPosition;var target = new CartesianPose(tcp.X + 50, tcp.Y, tcp.Z, tcp.Orientation);// The trajectory gives flange positions in the world frame, ready to send to the robotTrajectory trajectory = builder.MoveLinear(target, 100, FanucMotion.Fine()).Build();}}
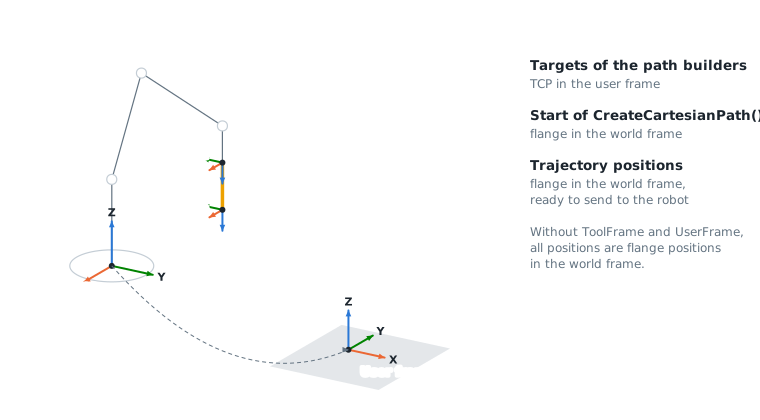
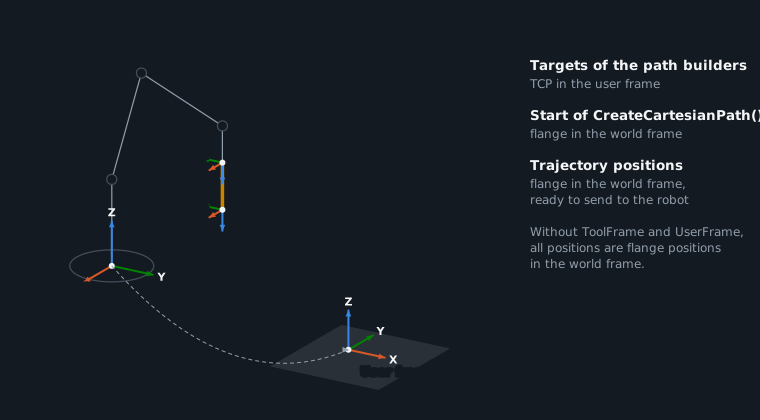
- The start of
CreateCartesianPath()is the position of the robot: flange in the world frame, for exampleFanucMotion.ToCartesianPose(StreamMotion.QueueEndCartesianPosition). EndPositiongives the end of the motions added so far, in the tool and user frames, as aCartesianPose.- The trajectory gives flange positions in the world frame, ready to send to the robot. The Cartesian limits apply to the tool center point.