Forward and inverse kinematics
Compute the flange position from joint angles, and every set of joint angles for a position, for 169 Yaskawa arms and cobots, offline on the PC.
This page explains the offline kinematics of the Yaskawa SDK: forward kinematics (joint angles to flange position) and inverse kinematics (flange position to every set of joint angles) of 6-axis Motoman arms and cobots. The computation runs on the PC, without a controller and without a connection, for 169 robot models.
What the kinematics do
| Function | Input | Output |
|---|---|---|
KinematicsUtils.ForwardKinematics | Joint angles in degrees (S, L, U, R, B, T) | Flange position: X, Y, Z in mm, Rx, Ry, Rz in degrees |
KinematicsUtils.InverseKinematics | Flange position | Every joint solution, up to 8 or 16 |
Both take the geometry of the robot as DhParameters: from the catalog of models, from the ALL.PRM file of the controller, or from your own values. See Kinematics models.
Use cases: check that a target can be reached before you send a move, choose the posture of a move, compute a position in a simulation or a planner, or compare a position read on the controller with a model.
Conventions
- Joint angles are in degrees, with the signs of the pendant. They are not encoder pulses: the conversion from pulses depends on the robot and is not done by the SDK.
- The Cartesian position is the flange (tool 0) in the robot frame. Add your tool yourself, with
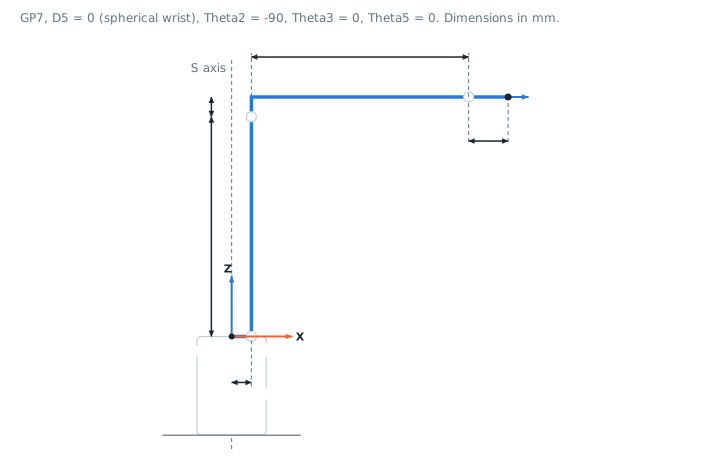
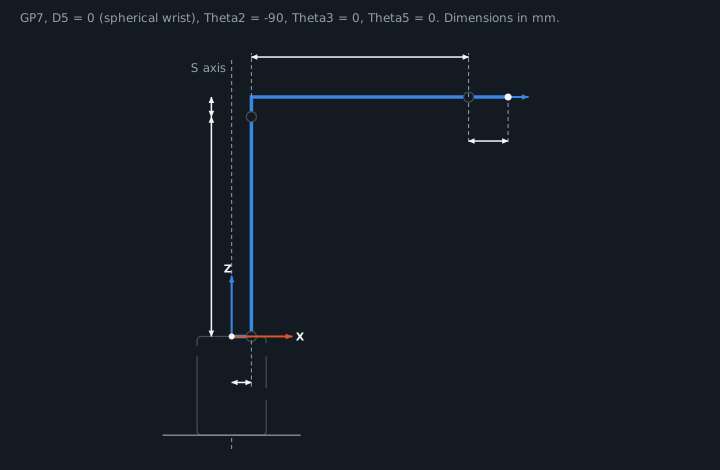
CartesianPosition.ToHomogeneousMatrix()and a matrix product. - The robot frame has its origin on the S axis, at the height of the L axis, X forward and Z up.
- The angles follow the Yaskawa convention: the orientation matrix is
R = Rz(Rz) * Ry(Ry) * Rx(Rx), the same as the pendant.
Forward kinematics
ForwardKinematics(joints, dh) returns the flange position for a set of joint angles.
static void Main(){// Geometry of the robot modelDhParameters dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.GP7);// Joint angles in degrees (S, L, U, R, B, T), with the signs of the pendantvar joints = new JointsAngles(0, 0, 0, 0, -90, 0);// Position of the flange in the robot frame: mm and degreesCartesianPosition flange = KinematicsUtils.ForwardKinematics(joints, dh);Console.WriteLine(flange); // X=480, Y=0, Z=405, Rx=-180, Ry=0, Rz=0: the flange points down}}
JointsAngles takes the 6 angles in its constructor, or an array. S, L, U, R, B, T and Values read and change them.
Inverse kinematics
InverseKinematics(position, dh) returns every set of joint angles that puts the flange at the position. The angles are in the range (-180, 180]. The array is empty when the position cannot be reached.
static void Main(){DhParameters dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.GP7);// Flange position in the robot frame: mm and degreesvar target = new CartesianPosition(400, 100, 300, 180, 0, 0);// Every joint solution, angles in (-180, 180]. Empty if the position cannot be reached.JointsAngles[] solutions = KinematicsUtils.InverseKinematics(target, dh);foreach (JointsAngles solution in solutions)Console.WriteLine(solution); // S=..., L=..., U=..., R=..., B=..., T=...}}
The joint limits of the robot are not checked: remove the solutions outside the limits of your robot, then choose one. See Inverse kinematics.
Supported robots
The SDK chooses the solver from the DH parameters:
KinematicsCategory | Structure | Models of the catalog | Solutions |
|---|---|---|---|
Opw | Ortho-parallel base, spherical wrist: the R, B and T axes meet (D5 = 0) | 157 (GP, MH, ES, AR, MotoMINI, HC20DT, HC30PL...) | Up to 8 |
J5OffsetWrist | Ortho-parallel base, wrist offset along the B axis (D5 is not 0, A1 and A3 are 0) | 12 (HC10, HC10DT, HC20SDT...) | Up to 16 |
These structures are not supported: T axis offset from the B axis (MA1400, MA1550, MA1800, MA1900), painting wrists with tilted axes (MPX2600, MPX3500), R axis parallel to the L and U axes (MPXL2600), palletizing robots, SCARA, delta and 7-axis robots. For them, InverseKinematics throws a NotSupportedException.
Accuracy and speed
- Each solution is checked with the forward kinematics before it is returned: the error is below 0.00001 mm.
- The catalog gives the nominal geometry of each model. The controller can use calibrated values: compare a few positions with your robot before you rely on an offline result.
- The SDK is tested with poses measured on real GP7 and HC10 robots.
- An inverse kinematics takes about 20 µs for a GP7 and 100 µs for an HC10 on a desktop PC: 10000 targets of a path are checked in a fraction of a second.
Reference
Forward and inverse kinematics of 6-axis Yaskawa arms.
| Member | Type | Description |
|---|---|---|
ForwardKinematics(IJointAngles, IDhParameters) Method static | CartesianPosition | Computes the flange position for the given joint angles.
|
InverseKinematics(ICartesianPosition, IDhParameters) Method static | JointsAngles[] | Computes all the joint solutions that put the flange at the given position. Joint limits are not checked. Angles are returned in the range (-180, 180].
|
Joint angles of a 6-axis arm, in degrees, with the same signs as the pendant (axes S, L, U, R, B, T).
| Member | Type | Description |
|---|---|---|
JointsAngles() Constructor | Initializes a new instance of JointsAngles with all angles at 0. | |
JointsAngles(double, double, double, double, double, double) Constructor | Initializes a new instance of JointsAngles with the specified angles (degrees).
| |
JointsAngles(double[]) Constructor | Initializes a new instance of JointsAngles from an array of at least 6 angles (degrees). The array is copied.
| |
B Property | double | B axis angle (degrees). |
L Property | double | L axis angle (degrees). |
R Property | double | R axis angle (degrees). |
S Property | double | S axis angle (degrees). |
T Property | double | T axis angle (degrees). |
U Property | double | U axis angle (degrees). |
Values Property read only | double[] | Angles of axes S, L, U, R, B, T in degrees. |
ToString() Method | string |
Cartesian position of the robot flange in the robot frame.
| Member | Type | Description |
|---|---|---|
CartesianPosition() Constructor | Initializes a new instance of CartesianPosition at the origin, with zero angles. | |
CartesianPosition(double, double, double, double, double, double) Constructor | Initializes a new instance of CartesianPosition with the specified values.
| |
CartesianPosition(ICartesianPosition) Constructor | Initializes a new instance of CartesianPosition by copying any Cartesian position, for example a position read from the robot.
| |
Rx Property | double | Rotation around the X axis in degrees. |
Ry Property | double | Rotation around the Y axis in degrees. |
Rz Property | double | Rotation around the Z axis in degrees. |
X Property | double | X position in millimeters. |
Y Property | double | Y position in millimeters. |
Z Property | double | Z position in millimeters. |
FromHomogeneousMatrix(double[,]) Method static | CartesianPosition | Creates a Cartesian position from a homogeneous matrix (3x4 or 4x4, translation in mm). When Ry is +90 or -90 degrees, Rx and Rz are not unique: Rz is set to 0.
|
ToHomogeneousMatrix() Method | double[,] | Returns the 4x4 homogeneous matrix of this position (rotation and translation in mm). |
ToString() Method | string |
Kinematic structure of a 6-axis arm. It decides which inverse kinematics solver is used.
| Name | Value | Description |
|---|---|---|
J5OffsetWrist | 1 | Ortho-parallel base with a wrist offset along the B axis (D5 is not 0): the R and T axes do not meet. Collaborative robots such as HC10, HC10DT, HC20SDT. Up to 16 inverse kinematics solutions. |
Opw | 0 | Ortho-parallel base with a spherical wrist: the R, B and T axes meet at one point (D5 = 0). Most industrial arms (GP, MH, ES, HC20DT, HC30PL...). Up to 8 inverse kinematics solutions. |
What to read next
- Inverse kinematics: the solutions, the postures and how to choose one.
- Kinematics models: DH parameters from the catalog, from the controller or from your values.