Common API
Types and members shared by every brand in UnderAutomation.Robotics.
This page describes the types and members of UnderAutomation.Robotics that are the same for every robot brand.
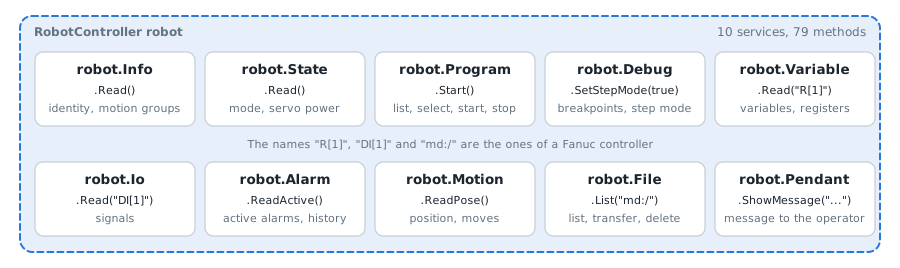
One object, ten services
The common API is one class, RobotController, of the namespace UnderAutomation.Robotics.Controllers. After Connect, each service is a property of the object, and a call is always robot.Service.Method().
| Service | What it does |
|---|---|
| Info | Controller identity and motion groups |
| State | Operating mode and servo power |
| Program | List, start, stop and read the execution |
| Debug | Breakpoints and step mode |
| Variable | Read and write variables and registers |
| Io | Read, write and simulate signals |
| Alarm | Read and reset alarms |
| Motion | Read the position and move the robot |
| File | List, transfer and delete files |
| Pendant | Show a message to the operator |
The same rules for every service
- A method that a brand does not have throws
FeatureNotSupportedException.IsAvailableof the service returnsfalsebefore the call. See Errors. - The page of each service has a Brand support table: the protocol that each method uses on each brand.
robot.Nativegives the object of the brand SDK, on the same connections, for what the common API does not cover. See Connect to your robot.robot.Routingtells which protocol each method uses on the connected controller. See Routing.
What to read next
- How it works: the library in four diagrams.
- Connect to your robot: the connection parameters of each brand.
- How-to articles: one code per task, in C# and Python.