
Yaskawa SDKControl Yaskawa robots from your own software
Quickly create applications in .NET, Python or LabVIEW that communicate with your Motoman Yaskawa industrial robot. A ready-to-use software library: your PC talks to the robot over the network cable.
From 750 € / $900, paid once
 .NET / C#
 Python
 LabVIEW
 Matlab
1// dotnet add package UnderAutomation.Yaskawa2using UnderAutomation.Yaskawa;34var robot = new YaskawaRobot();5robot.Connect("192.168.0.1");67var position = robot.HighSpeedEServer.GetRobotCartesianPosition();8robot.HighSpeedEServer.SelectJob("WELD01", 0);9robot.HighSpeedEServer.StartJob();
What you get
Plug & Play
Connect your robot in just a few minutes. No license manager to install, no USB key. Only reference the library.
No plugins to install on the robot
Use of network protocols provided as standard by the robot controller.
30-day trial
Try it free for 30 days, no commitment, no registration required
Pay once, use forever
Perpetual license, no subscription required, regardless of the number of robots, developers, or redistributed software
Yaskawa SDK features: HSES, Ethernet Server, FTP and kinematics
Each feature comes with a code sample. Click on it to see the full code.
Move the robot
Send Cartesian and joint moves to the robot, and read its current position, the torque of the motors and the position error.
var robot = new YaskawaRobot();robot.Connect("192.168.0.1");// The servo must be on, the controller in remote moderobot.HighSpeedEServer.SetServo(true);// Linear move to an absolute position of the robot frame, at 50 mm/srobot.HighSpeedEServer.MoveCartesian(x: 850, y: 0, z: 400, // mmrx: 180, ry: 0, rz: 0, // degreesPositionCommandClassification.Cartesian_MM_S,speed: 50,PositionCommandOperationCoordinate.Robot,commandtype: PositionCommandType.StraightAbsolute);// Joint interpolated move to the same target, at 10 % of the maximum speedrobot.HighSpeedEServer.MoveCartesian(850, 0, 400, 180, 0, 0,PositionCommandClassification.LinkPercent,speed: 10,PositionCommandOperationCoordinate.Robot,commandtype: PositionCommandType.LinkAbsolute);robot.Disconnect();}
Run robot programs
Send jobs to the controller, select them and start them from a PC. Then follow the executing job, its line and the alarms.
var robot = new YaskawaRobot();robot.Connect("192.168.0.1");// Select the job by its name, without the .JBI extension, at line 0robot.HighSpeedEServer.SelectJob("WELD01", 0);// Starting needs the play mode, the remote mode and the servo onrobot.HighSpeedEServer.SetServo(true);robot.HighSpeedEServer.StartJob();robot.Disconnect();}
Data reading and writing
Read and write the I/O, the byte, integer, real, string and position variables, and the registers of the controller.
var robot = new YaskawaRobot();robot.Connect("192.168.0.1");// B000 to B003: byte variables (0 to 255)byte[] b = robot.HighSpeedEServer.ReadByte(0, 4).Value;robot.HighSpeedEServer.WriteByte(0, new byte[] { 1, 2, 3, 4 });// I010 and I011: integer variables (16 bits)short[] i = robot.HighSpeedEServer.ReadInteger(10, 2).Value;robot.HighSpeedEServer.WriteInteger(10, new short[] { -100, 200 });// D000: double integer variable (32 bits)int[] d = robot.HighSpeedEServer.ReadDoubleInteger(0, 1).Value;robot.HighSpeedEServer.WriteDoubleInteger(0, new[] { 100000 });// R005 to R007: real variables (32 bit floating point)float[] r = robot.HighSpeedEServer.ReadReal(5, 3).Value;robot.HighSpeedEServer.WriteReal(5, new[] { 1.5f, -2.25f, 3f });robot.Disconnect();}
File transfers
Download, upload and delete jobs and data files over FTP, HTTP or the High Speed Ethernet Server, and download the CMOS backup.
var robot = new YaskawaRobot();robot.Connect(parameters);// Text of a file: the folder is deduced from the extensionstring job = robot.Ftp.GetFile("TEST.JBI");// Bytes of a file, with its full pathbyte[] variables = robot.Ftp.DownloadFile("/DAT/VAR.DAT");// To a file of the PCrobot.Ftp.DownloadFileToLocal("/PRM/ALL.PRM", @"C:\Backup\ALL.PRM");// Several files into a folder of the PC: returns the local pathsstring[] saved = robot.Ftp.DownloadFilesToLocal(new[] { "/JOB/TEST.JBI", "/DAT/VAR.DAT" }, @"C:\Backup");robot.Disconnect();}
Ethernet Server over TCP
Read the status, the alarms with their text, the positions in any frame and the encoder temperatures. Start a job and wait for its end in one call.
var robot = new YaskawaRobot();robot.Connect(parameters);// Play mode, remote mode, no alarmrobot.EServer.SelectJob("PICK", 0); // job and linerobot.EServer.SetServo(true);robot.EServer.StartJob();// Blocks until the job ends, or 60 sbool completed = robot.EServer.WaitForJobCompletion(60);Console.WriteLine(completed ? "Job completed" : "Job stopped or timeout");robot.Disconnect();}
Offline kinematics
Forward and inverse kinematics of 169 Yaskawa arms and cobots, on the PC: up to 8 or 16 joint solutions for a position, DH parameters read from ALL.PRM.
static void Main(){DhParameters dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.GP7);// Flange position in the robot frame: mm and degreesvar target = new CartesianPosition(400, 100, 300, 180, 0, 0);// Every joint solution, angles in (-180, 180]. Empty if the position cannot be reached.JointsAngles[] solutions = KinematicsUtils.InverseKinematics(target, dh);foreach (JointsAngles solution in solutions)Console.WriteLine(solution); // S=..., L=..., U=..., R=..., B=..., T=...}}
See it in action
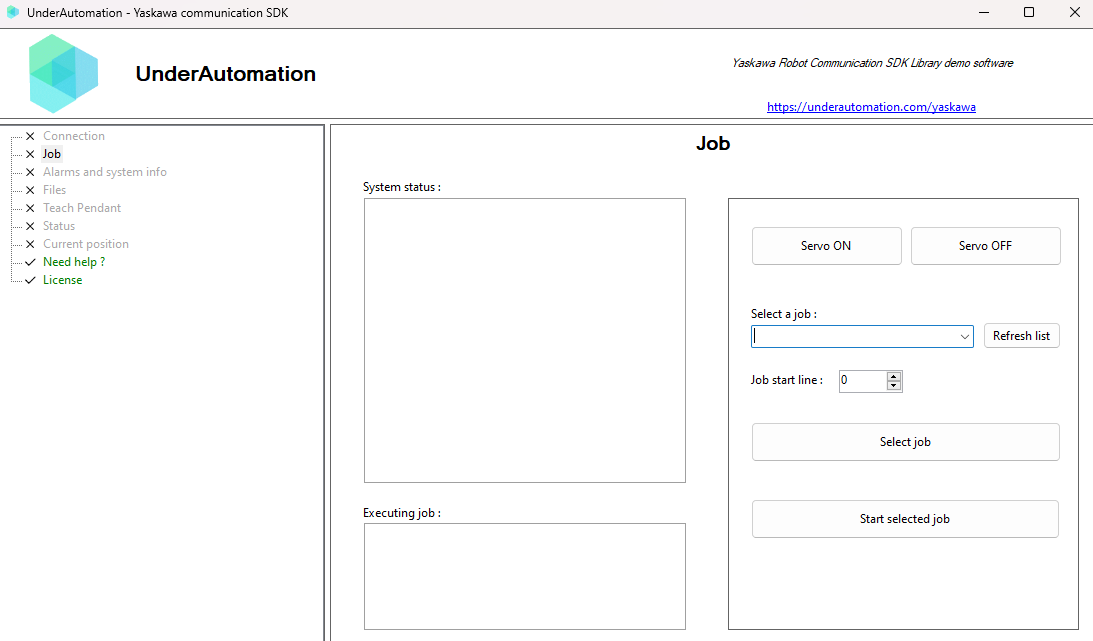
Video and screenshots of the demo application delivered with the SDK.
Windows application example
No code to write: test the SDK on your robot with the demo application.
Examples on GitHub
The sources of examples of use of this SDK are available on Github
Python example
Example of operation of this SDK with Python to recover the Cartesian position of a robot.
Labview example
Example of VI which allows most of the functions of this SDK to be tested.
Install it in one command
Choose your language. The 30-day trial starts at the first use, with no registration.
.NET
NuGet package for C# and VB.NET, from .NET Framework to the latest .NET.
dotnet add package UnderAutomation.YaskawaPython
Python package on PyPI, for Windows, Linux and macOS.
pip install UnderAutomation.YaskawaLabVIEW
LabVIEW library (.lvlib) and its example project, on GitHub.
git clone https://github.com/underautomation/Yaskawa.vi.gitAI agents
Skill for AI coding agents (Claude Code, Cursor, Copilot...): your assistant knows the API of the SDK.
npx skills add underautomation/skills --skill underautomation-yaskawa-csharpBrowse the documentation
The documentation allows you to quickly start developing with the library. The same functionality is available in all supported languages.

Browse the documentation
The documentation allows you to quickly start developing with the library. The same functionality is available in all supported languages.
Getting started with .NET
Code your application in C# or VB with this 100% managed library, without dependencies and available on NuGet.org in the version and architecture of your choice (x86, x64, ARM, Linux, Windows, MacOS, .NET Framework, .NET Core, UWP, ...)
Get started with Python
Quickly develop a program in Python that communicates with your robot using this library. It is available on PyPI.
Getting started with LabVIEW
Equip your LabVIEW VIs with a communication with your robot.
Getting started with Matlab
Allow your Matlab scripts to drive your robot.
Guides and how-to articles
Each article explains how to do one task, step by step, with code you can copy.
Get the robot position
Read the position of a Yaskawa robot from C# or Python: Cartesian position or joint pulses, which method to choose, and a polling loop. Complete program included.
Read and write I/O
Switch a network input and wait for an output of a Yaskawa controller from C# or Python, with the signal numbers, groups and bits explained.
Read and write variables
Exchange data with a Yaskawa job from C# or Python: integer, real, byte and string variables, which type to choose, and the frequent errors.
Run a job
Select a job of a Yaskawa controller, switch the servo on, start it and wait for its end from C# or Python. Settings of the controller and frequent errors.
Read and reset alarms
Detect an alarm of a Yaskawa controller, read its code and text, reset it and check the result, from C# or Python.
Transfer files and backups
Back up every job of a Yaskawa controller, send a job written on the PC and download the CMOS backup, from C# or Python.
Monitor the state of the robot
Poll the mode, the servo, the hold, the alarms and the job of a Yaskawa controller, and print each change of state.
Move the robot from a PC
Switch the servo on and move a Yaskawa robot in a straight line from C# or Python, without a job. Which move to choose, how to wait for the end, and the frequent errors.
Pricing
Libraries can be downloaded for free and can be tested for 30 days. After this period, you can ask us to extend the trial period, or buy the license that suits you best: standard, pro or source. After purchasing, you have a maintenance period, giving you access to the support and the possibility of updating. When you buy a license to use, it is linked to a robot brand, you can use it forever, without recurring fee, regardless of the number of robot, developer or software that you redistribute to your customers. If you are a distributor and wish to offer your customers one of our products, please contact us to discuss special conditions and prices.
Standard Site License
•
Pro License
•
Source license
•
Frequently asked questions
Libraries on GitHub
Each package is published on GitHub with its changelog.
Latest releases
Yaskawa.NET
Latest release
Get started now !
Start the 30-day trial today, or ask for a quote.