
Yaskawa SDK控制 Yaskawa 机器人 直接从您自己的软件
快速创建使用 .NET、Python 或 LabVIEW 与 Motoman Yaskawa 工业机器人通信的应用程序。 开箱即用的软件库:您的电脑通过网线与机器人通信。
 .NET / C#
 Python
 LabVIEW
 Matlab
1// dotnet add package UnderAutomation.Yaskawa2using UnderAutomation.Yaskawa;34var robot = new YaskawaRobot();5robot.Connect("192.168.0.1");67var position = robot.HighSpeedEServer.GetRobotCartesianPosition();8robot.HighSpeedEServer.SelectJob("WELD01", 0);9robot.HighSpeedEServer.StartJob();
您将获得什么
Plug & Play
只需几分钟即可连接您的机器人。无需安装许可证管理器, 无需 USB 密钥。仅参考图书馆。
没有在机器人上安装的插件
使用机器人控制器作为标准提供的网络协议。
30 天试用
免费试用 30 天, 无承诺, 无需注册
付一次, 永远使用
永久许可, 无需订阅, 无论机器人, 开发人员的数量是多少
Yaskawa SDK 功能:HSES、Ethernet Server、FTP 和运动学
每项功能都有代码示例。点击示例可查看完整代码。
移动机器人
该库允许发送笛卡尔和联合运动命令, 并允许您恢复当前位置, 几对引擎和定位误差。
var robot = new YaskawaRobot();robot.Connect("192.168.0.1");// The servo must be on, the controller in remote moderobot.HighSpeedEServer.SetServo(true);// Linear move to an absolute position of the robot frame, at 50 mm/srobot.HighSpeedEServer.MoveCartesian(x: 850, y: 0, z: 400, // mmrx: 180, ry: 0, rz: 0, // degreesPositionCommandClassification.Cartesian_MM_S,speed: 50,PositionCommandOperationCoordinate.Robot,commandtype: PositionCommandType.StraightAbsolute);// Joint interpolated move to the same target, at 10 % of the maximum speedrobot.HighSpeedEServer.MoveCartesian(850, 0, 400, 180, 0, 0,PositionCommandClassification.LinkPercent,speed: 10,PositionCommandOperationCoordinate.Robot,commandtype: PositionCommandType.LinkAbsolute);robot.Disconnect();}
运行机器人程序
SDK允许您将程序发送到控制器并远程启动。 然后可以遵循执行的进度以及警报状态。
var robot = new YaskawaRobot();robot.Connect("192.168.0.1");// Select the job by its name, without the .JBI extension, at line 0robot.HighSpeedEServer.SelectJob("WELD01", 0);// Starting needs the play mode, the remote mode and the servo onrobot.HighSpeedEServer.SetServo(true);robot.HighSpeedEServer.StartJob();robot.Disconnect();}
数据阅读和写作
您的应用程序可以在机器人中读取所有类型的寄存器 (io, 位置变量, 字节变量, ...)
var robot = new YaskawaRobot();robot.Connect("192.168.0.1");// B000 to B003: byte variables (0 to 255)byte[] b = robot.HighSpeedEServer.ReadByte(0, 4).Value;robot.HighSpeedEServer.WriteByte(0, new byte[] { 1, 2, 3, 4 });// I010 and I011: integer variables (16 bits)short[] i = robot.HighSpeedEServer.ReadInteger(10, 2).Value;robot.HighSpeedEServer.WriteInteger(10, new short[] { -100, 200 });// D000: double integer variable (32 bits)int[] d = robot.HighSpeedEServer.ReadDoubleInteger(0, 1).Value;robot.HighSpeedEServer.WriteDoubleInteger(0, new[] { 100000 });// R005 to R007: real variables (32 bit floating point)float[] r = robot.HighSpeedEServer.ReadReal(5, 3).Value;robot.HighSpeedEServer.WriteReal(5, new[] { 1.5f, -2.25f, 3f });robot.Disconnect();}
文件传输
通过 FTP、HTTP 或 High Speed Ethernet Server 下载、上传和删除作业与数据文件,并下载 CMOS 备份。
var robot = new YaskawaRobot();robot.Connect(parameters);// Text of a file: the folder is deduced from the extensionstring job = robot.Ftp.GetFile("TEST.JBI");// Bytes of a file, with its full pathbyte[] variables = robot.Ftp.DownloadFile("/DAT/VAR.DAT");// To a file of the PCrobot.Ftp.DownloadFileToLocal("/PRM/ALL.PRM", @"C:\Backup\ALL.PRM");// Several files into a folder of the PC: returns the local pathsstring[] saved = robot.Ftp.DownloadFilesToLocal(new[] { "/JOB/TEST.JBI", "/DAT/VAR.DAT" }, @"C:\Backup");robot.Disconnect();}
基于 TCP 的 Ethernet Server
读取状态、带文本的报警、任意坐标系下的位置和编码器温度。启动作业,并用一次调用等待其结束。
var robot = new YaskawaRobot();robot.Connect(parameters);// Play mode, remote mode, no alarmrobot.EServer.SelectJob("PICK", 0); // job and linerobot.EServer.SetServo(true);robot.EServer.StartJob();// Blocks until the job ends, or 60 sbool completed = robot.EServer.WaitForJobCompletion(60);Console.WriteLine(completed ? "Job completed" : "Job stopped or timeout");robot.Disconnect();}
离线运动学
在 PC 上计算 169 款 Yaskawa 机械臂和协作机器人的正向与逆向运动学:每个位置最多 8 或 16 组关节解,DH 参数可从 ALL.PRM 读取。
static void Main(){DhParameters dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.GP7);// Flange position in the robot frame: mm and degreesvar target = new CartesianPosition(400, 100, 300, 180, 0, 0);// Every joint solution, angles in (-180, 180]. Empty if the position cannot be reached.JointsAngles[] solutions = KinematicsUtils.InverseKinematics(target, dh);foreach (JointsAngles solution in solutions)Console.WriteLine(solution); // S=..., L=..., U=..., R=..., B=..., T=...}}
看看实际效果
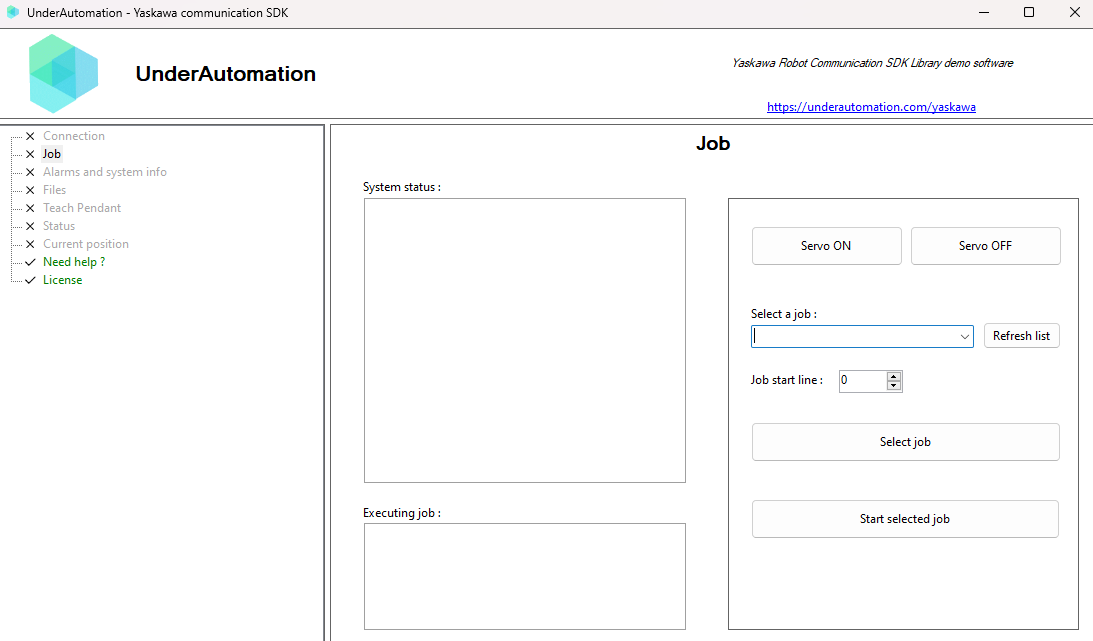
随 SDK 提供的演示程序的视频和截图。
一条命令即可安装
选择您的语言。30 天试用从首次使用开始,无需注册。
.NET
适用于 C# 和 VB.NET 的 NuGet 包,从 .NET Framework 到最新的 .NET。
dotnet add package UnderAutomation.YaskawaPython
PyPI 上的 Python 包,支持 Windows、Linux 和 macOS。
pip install UnderAutomation.YaskawaLabVIEW
LabVIEW 库 (.lvlib) 及其示例项目,位于 GitHub。
git clone https://github.com/underautomation/Yaskawa.vi.gitAI 助手
面向 AI 编程助手(Claude Code、Cursor、Copilot 等)的 Skill:您的助手了解 SDK 的 API。
npx skills add underautomation/skills --skill underautomation-yaskawa-csharp浏览文档
该文档使您可以快速开始使用库开发。 所有受支持的语言都可以使用相同的功能。

浏览文档
该文档使您可以快速开始使用库开发。 所有受支持的语言都可以使用相同的功能。
开始使用.NET
用这个100%托管的库在C#或VB中编码你的应用程序, 没有依赖性, 在NuGet.org上有你选择的版本和架构 (x86, x64, ARM, Linux, Windows, MacOS, .NET Framework, .NET Core, UWP, ...) 。
开始使用Python
用Python快速开发一个程序, 用这个库与你的机器人进行通信。它可以在PyPI上使用。
开始使用LabVIEW
为您的LabVIEW VIs配备与机器人的通信功能。
开始使用Matlab
让你的Matlab脚本来驱动你的机器人。
指南和实用文章
每篇文章逐步讲解一项任务的做法,并附带可直接复制的代码。
Get the robot position
Read the position of a Yaskawa robot from C# or Python: Cartesian position or joint pulses, which method to choose, and a polling loop. Complete program included.
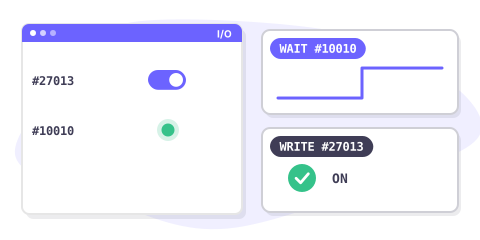
Read and write I/O
Switch a network input and wait for an output of a Yaskawa controller from C# or Python, with the signal numbers, groups and bits explained.
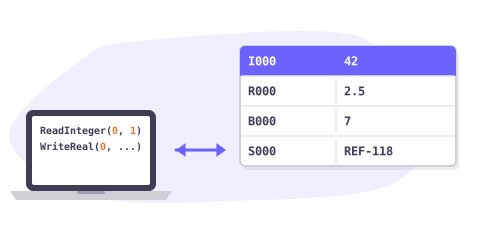
Read and write variables
Exchange data with a Yaskawa job from C# or Python: integer, real, byte and string variables, which type to choose, and the frequent errors.
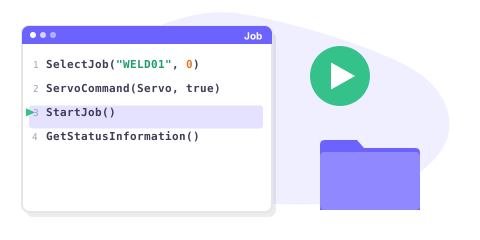
Run a job
Select a job of a Yaskawa controller, switch the servo on, start it and wait for its end from C# or Python. Settings of the controller and frequent errors.
Read and reset alarms
Detect an alarm of a Yaskawa controller, read its code and text, reset it and check the result, from C# or Python.
Transfer files and backups
Back up every job of a Yaskawa controller, send a job written on the PC and download the CMOS backup, from C# or Python.
Monitor the state of the robot
Poll the mode, the servo, the hold, the alarms and the job of a Yaskawa controller, and print each change of state.
Move the robot from a PC
Switch the servo on and move a Yaskawa robot in a straight line from C# or Python, without a job. Which move to choose, how to wait for the end, and the frequent errors.
价格
可以免费下载库, 可以进行30天的测试。 在此期间之后, 您可以要求我们延长试用期, 或购买最适合您的许可证: 站点 (仅二进制二进制) 或源代码 (源代码) 。 购买后, 您有一个一年的维护期, 使您优先访问支持和更新的可能性。 当您购买使用许可证时, 它会链接到机器人品牌, 无论您将其重新分配给客户的机器人, 开发人员或软件的数量如何, 都可以永远使用, 而无需重复费用。 如果您是分销商, 并希望为您的客户提供我们的产品之一, 请与我们联系以讨论特殊条件和价格。
标准站点许可证
•
专业许可
•
源代码许可
•
常见问题
GitHub 上的库
每个包都发布在 GitHub 上,并附有更新日志。