
Staubli SDKControl Stäubli robots from your own software
Quickly create applications in .NET, Python or LabVIEW that communicate with your Staubli industrial robot. A ready-to-use software library: your PC talks to the robot over the network cable.
From 300 € / $350, paid once
 .NET / C#
 Python
1// dotnet add package UnderAutomation.Staubli2using UnderAutomation.Staubli;34var controller = new StaubliController();5controller.Connect("192.168.0.254");67double[] joints = controller.Soap.GetCurrentJointPosition(robot: 0);8var tasks = controller.Soap.GetTasks();9var ios = controller.Soap.GetAllPhysicalIos();
What you get
Plug & Play
Connect your robot in just a few minutes. No license manager to install, no USB key. Only reference the library.
No plugins to install on the robot
Use of network protocols provided as standard by the robot controller.
30-day trial
Try it free for 30 days, no commitment, no registration required
Pay once, use forever
Perpetual license, no subscription required, regardless of the number of robots, developers, or redistributed software
Staubli SDK Features: SOAP and FTP for CS8 & CS9
Each feature comes with a code sample. Click on it to see the full code.
Moving the robot
Powering remotely and sending of joint movement commands or Cartesian coordinates.
Frame intermediate = controller.Soap.ForwardKinematics(robot: 0, joints).Position;intermediate.Py += 0.05;controller.Soap.SetPower(true);// Joint move to joint values, in radiansIMoveResult result = controller.Soap.MoveJJ(robot: 0, joints, mdesc);// Joint move to a Cartesian frameresult = controller.Soap.MoveJC(robot: 0, target, mdesc);// Straight line to a Cartesian frameresult = controller.Soap.MoveL(robot: 0, target, mdesc);// Circle through an intermediate frame, to a target frameresult = controller.Soap.MoveC(robot: 0, intermediate, target, mdesc);// The controller accepted the move, or tells why notif (result.ReturnCode != MotionReturnCode.Success)Console.WriteLine($"Move {result.Id} refused: {result.ReturnCode}");controller.Disconnect();}
Handling applications
Load, start, stop, pause and supervise the execution of tasks.
var controller = new StaubliController();controller.Connect("192.168.0.254");// Path of the project on the disk of the controllerstring project = "Disk://myProject/myProject.pjx";// Load the application in memory, without starting itcontroller.Soap.LoadProject(project);// Start itcontroller.Soap.StartApplication(project);controller.Disconnect();}
File transfer
List, upload, download and delete the files of the controller, and send a complete VAL 3 application in one call. By FTP, or with the .controller file of a controller emulated by Staubli Robotics Suite.
var controller = new StaubliController();controller.Connect(parameters);// The application must not be in memory while its files are replacedcontroller.Soap.StopAndUnloadAll();// Copies C:\MyApps\myApp and its sub-folders to /usr/usrapp/myApp on the controllerstring remoteFolder = controller.File.UploadApplicationToController(@"C:\MyApps\myApp",progress => Console.WriteLine($"{progress:0}%"));// /usr/usrapp/myApp/myApp.pjx is Disk://myApp/myApp.pjx for the SOAP methodscontroller.Soap.LoadProject("Disk://myApp/myApp.pjx");controller.Soap.StartApplication("Disk://myApp/myApp.pjx");controller.Disconnect();}
Position and kinematics
Read the joints and the Cartesian position of the robot, and compute the forward and inverse kinematics on the controller.
var controller = new StaubliController();controller.Connect("192.168.0.254");// Joint values in radians, here the current onesdouble[] joints = controller.Soap.GetCurrentJointPosition(robot: 0);// The controller computes the flange frame for these jointsIForwardKinematics fk = controller.Soap.ForwardKinematics(robot: 0, joints);// Position of the frame origin, and its orientation as a rotation matrixFrame frame = fk.Position;Console.WriteLine($"P = [{frame.Px}, {frame.Py}, {frame.Pz}]");// Configuration of the arm for this position (shoulder, elbow, wrist)Config config = fk.Config;Console.WriteLine(config);controller.Disconnect();}
Information
Get controller and controlled robot characteristics, including model, software version, power status and more.
var controller = new StaubliController();controller.Connect("192.168.0.254");// The robots driven by the controller. The index in this array// is the robot number that the other methods take.Robot[] robots = controller.Soap.GetRobots();for (int i = 0; i < robots.Length; i++){Robot robot = robots[i];Console.WriteLine($"Robot {i}: {robot.Arm}"); // for example TX2-60Console.WriteLine($" Kinematic: {robot.Kinematic}"); // Anthropomorph6, Scara...Console.WriteLine($" Mount type: {robot.MountType}"); // Floor, Ceiling, WallConsole.WriteLine($" Tuning: {robot.Tuning}");}controller.Disconnect();}
Inputs / Outputs
List, read and write entries and outputs of the controller
var controller = new StaubliController();controller.Connect("192.168.0.254");// Names as returned by GetAllPhysicalIosstring[] names = { @"BasicIO-1\%I0", @"BasicIO-1\%Q0" };// One state per name, in the same orderPhysicalIoState[] states = controller.Soap.ReadIos(names);for (int i = 0; i < names.Length; i++){PhysicalIoState state = states[i];// State tells if the name exists on this controllerif (state.State != PhysicalIoEnumState.Defined){Console.WriteLine($"{names[i]}: {state.State}");continue;}Console.WriteLine($"{names[i]} = {state.Value} locked={state.Locked} simulated={state.Simulated}");}controller.Disconnect();}
See it in action
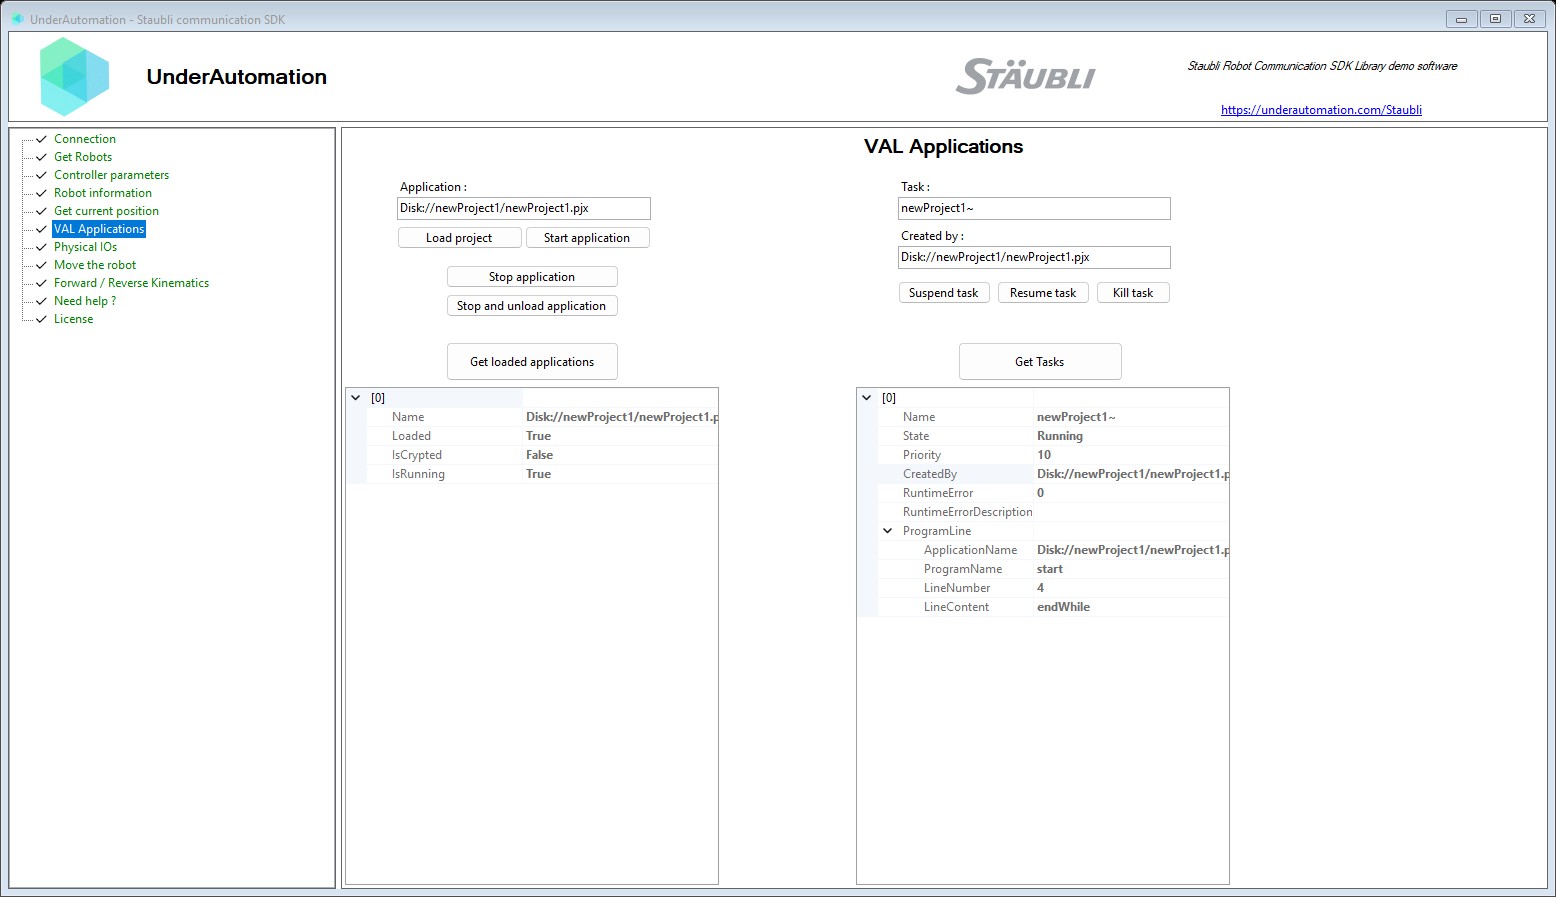
Video and screenshots of the demo application delivered with the SDK.
Windows application example
No code to write: test the SDK on your robot with the demo application.
Examples on GitHub
The sources of examples of use of this SDK are available on Github
Python example
Example of operation of this SDK with Python to recover the Cartesian position of a robot.
Install it in one command
Choose your language. The 30-day trial starts at the first use, with no registration.
.NET
NuGet package for C# and VB.NET, from .NET Framework to the latest .NET.
dotnet add package UnderAutomation.StaubliPython
Python package on PyPI, for Windows, Linux and macOS.
pip install UnderAutomation.StaubliAI agents
Skill for AI coding agents (Claude Code, Cursor, Copilot...): your assistant knows the API of the SDK.
npx skills add underautomation/skills --skill underautomation-staubli-csharpBrowse the documentation
The documentation allows you to quickly start developing with the library. The same functionality is available in all supported languages.

Browse the documentation
The documentation allows you to quickly start developing with the library. The same functionality is available in all supported languages.
Getting started with .NET
Code your application in C# or VB with this 100% managed library, without dependencies and available on NuGet.org in the version and architecture of your choice (x86, x64, ARM, Linux, Windows, MacOS, .NET Framework, .NET Core, UWP, ...)
Get started with Python
Quickly develop a program in Python that communicates with your robot using this library. It is available on PyPI.
Guides and how-to articles
Each article explains how to do one task, step by step, with code you can copy.
Get the robot position
Read the position of a Staubli robot from C# or Python: joints, flange or tool position, and which method to choose. Complete program included.
Read and write I/O
Find the I/O names, wait for an input and switch an output of a Staubli CS8 or CS9 controller from C# or Python.
Move the robot from a PC
Power the arm and move a Staubli robot in a straight line from C# or Python, without a VAL 3 program. Which move to choose, and the frequent errors.
Run a VAL 3 program
Load a VAL 3 project from the disk of the controller, start it, check its tasks and stop it, from C# or Python.
Monitor the state of the robot
Poll the applications and the VAL 3 tasks of a Staubli controller, print each change of state and each runtime error.
Pricing
Libraries can be downloaded for free and can be tested for 30 days. After this period, you can ask us to extend the trial period, or buy the license that suits you best: standard, pro or source. After purchasing, you have a maintenance period, giving you access to the support and the possibility of updating. When you buy a license to use, it is linked to a robot brand, you can use it forever, without recurring fee, regardless of the number of robot, developer or software that you redistribute to your customers. If you are a distributor and wish to offer your customers one of our products, please contact us to discuss special conditions and prices.
Standard Site License
•
Pro License
•
Source license
•
Frequently asked questions
Libraries on GitHub
Each package is published on GitHub with its changelog.
Get started now !
Start the 30-day trial today, or ask for a quote.