Primary Interface : Data streaming
Receive robot state data at 10Hz via the Primary Interfaces
Data described below are sent by the robot controller at 10Hz by the TCP/IP Primary (and Secondary) Interface protocol.
For more information about Primry Interface, see : https://www.universal-robots.com/articles/ur/interface-communication/remote-control-via-tcpip/
Enable Primary Interface
When creating the ConnectParameters object or when the Connect() method is called by passing the IP address of the robot, the Primary Interface protocol is enabled by default.
You can however connect by specifying a ConnectParameters object. You can then choose the port to connect to.
using UnderAutomation.UniversalRobots;using UnderAutomation.UniversalRobots.PrimaryInterface;class PrimaryInterface{static void Main(string[] args){var robot = new UR();var param = new ConnectParameters("192.168.0.1");param.PrimaryInterface.Enable = true; // enable Primary Interface// param.PrimaryInterface.Enable = false; // Connect to the robot without Primary Interfaceparam.PrimaryInterface.Port = Interfaces.PrimaryInterface;// Connect to the robot with custom parametersrobot.Connect(param);// you can also connect directly without ConnectParameters// Primary Interface and Dashboard are enabled by default// robot.Connect("192.168.0.56");//...// Access all your datavar value = robot.PrimaryInterface.JointData.Base.ActualSpeed;//...// Disconnect only Primary Interface communicationrobot.PrimaryInterface.Disconnect();// Disconnect every interfaces (Primary Interface, Dashboard, RTDE, ...)robot.Disconnect();}}
You can also instantiate a PrimaryInterface client directly without using the UR object.
using UnderAutomation.UniversalRobots.PrimaryInterface;class PrimaryInterfaceDirect{static void Main(string[] args){// Create a Prinmary Interface Client alone, outside any UR instancevar client = new PrimaryInterfaceClient();// Open TCP connection to the robotclient.Connect("192.168.0.1", Interfaces.PrimaryInterface);//...// Access all your datavar value = client.JointData.Base.ActualSpeed;//...// Close connection to the robotclient.Disconnect();}}
In the robot, the Primary Client Interface must be enabled in the Polyscope settings for security reasons, see : this page
Get data
Once communication is established with the robot, you will receive data at 10Hz. You can either handle an event that is raised when data is received. But you can also access the last packet received through a property.
using UnderAutomation.UniversalRobots;using UnderAutomation.UniversalRobots.PrimaryInterface;class PrimaryInterfaceData{static void Main(string[] args){var robot = new UR();robot.Connect("192.168.0.1");// Access last received data with propertiesJointDataPackageEventArgs lastJointDataReceived = robot.PrimaryInterface.JointData;KinematicsInfoPackageEventArgs lastKinematicsInfo = robot.PrimaryInterface.KinematicsInfo;// Or you can subscribe to an event to be notified as soon as the data arrivesrobot.PrimaryInterface.JointDataReceived += PrimaryInterface_JointDataReceived;}private static void PrimaryInterface_JointDataReceived(object sender, JointDataPackageEventArgs e){// e contains my new data !!}}
Get connection status
The Connected property indicates whether the interface is connected. If the interface disconnects (e.g. the robot is stopped or the network cable is disconnected), this property is set to false without raising a fault.
There is no automatic reconnection mechanism. You will have to call the Connect() function again.
However, if an error occurs inside the library, the InternalErrorOccured event is raised.
using UnderAutomation.UniversalRobots;using UnderAutomation.UniversalRobots.Common;class PrimaryInterfaceStatus{static void Main(string[] args){var robot = new UR();robot.Connect("192.168.0.1");// ...// Check if Primary Interface client is still connectedbool isConnected = robot.PrimaryInterface.Connected;// Handle the event that indicates an internal errorrobot.InternalErrorOccured += Robot_InternalErrorOccured;}private static void Robot_InternalErrorOccured(object sender, InternalErrorEventArgs e){// Get information about an internal errorException exception = e.Exception;string message = e.Message;StatusCode status = e.Status;}}
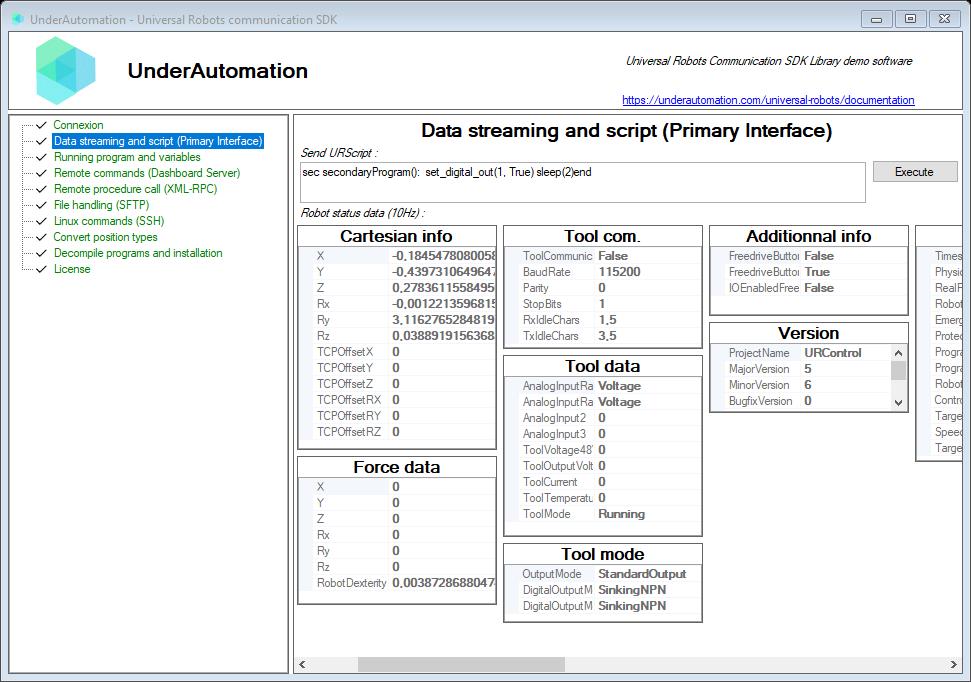
Try it with the Windows example
Robot mode
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageRobotModeDataPackageEventArgs _value = ur.PrimaryInterface.RobotModeData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.RobotModeDataReceived += Ur_RobotModeDataReceived;}private void Ur_RobotModeDataReceived(object sender, RobotModeDataPackageEventArgs e) {// e contains the incoming package}
Information about current robot mode
| Member | Type | Description |
|---|---|---|
RobotModeDataPackageEventArgs() Constructor | ||
ControlMode Property | ControlModes | Current robot control mode |
EmergencyStopped Property | bool | The button Emergency Stop is pressed |
PhysicalRobotConnected Property | bool | Robot is connected to its controller |
ProgramPaused Property | bool | The running program is paused |
ProgramRunning Property | bool | A program is running |
ProtectiveStopped Property | bool | A stop occured due to a fault detection |
RealRobotEnabled Property | bool | Real robot mode active. False if robot is in simulation |
RobotMode Property | RobotModes | Current robot running mode |
RobotPowerOn Property | bool | Robot is powered on and boot is completed. If false, you need to press "ON" button to power it on |
SpeedScaling Property | double | Speed scaling |
TargetSpeedFraction Property | double | Overriden speed ratio between 0 (0%) and 1 (100%) |
TargetSpeedFractionLimit Property | double | Maximum target speed fraction |
Timestamp Property | TimeSpan | Timespan since the robot controller has started |
Robot control modes
| Name | Value | Description |
|---|---|---|
Force | 2 | Robot is force controlled. (For example : URScript force_mode() function is called) |
Position | 0 | Robot is position controlled |
Teach | 1 | The robot is hand guided by pushing teached button |
Torque | 3 | Robot is torque controlled |
Robot running modes
| Name | Value | Description |
|---|---|---|
BackDrive | 6 | The robot is hand guided by pushing teached button |
Booting | 2 | The robot controller is booting |
ConfirmSafety | 1 | Robot has stopped due to a Safety Stop |
Disconnected | 0 | Robot is not connected to its controller |
Idle | 5 | Power is on but breaks are not released |
Other | -1 | Robot is in an obsolete CB2 mode |
PowerOff | 3 | The robot is powered off |
PowerOn | 4 | The robot is powered on |
Running | 7 | Robot is in normal mode |
UpdatingFirmware | 8 | Firmware is upgrading |
Joint data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageJointDataPackageEventArgs _value = ur.PrimaryInterface.JointData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.JointDataReceived += Ur_JointDataReceived;}private void Ur_JointDataReceived(object sender, JointDataPackageEventArgs e) {// e contains the incoming package}
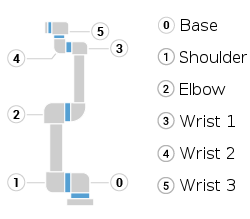
Status of each joints
| Member | Type | Description |
|---|---|---|
JointDataPackageEventArgs() Constructor | ||
Base Property | JointData | Base joint data |
Elbow Property | JointData | Elbow joint data |
Shoulder Property | JointData | Shoulder joint data |
Wrist1 Property | JointData | Wrist1 joint data |
Wrist2 Property | JointData | Wrist2 joint data |
Wrist3 Property | JointData | Wrist3 (Tool) joint data |
Joint data
| Member | Type | Description |
|---|---|---|
JointData() Constructor | ||
ActualSpeed Property | double | Joint rotation speed in rad/s |
Current Property | float | Motor current in Amps |
JointMode Property | JointModes | Joint mode |
Position Property | double | Angular joint position in radian |
TargetPosition Property | double | Angular target position in radian |
Temperature Property | float | Joint temperature in °C |
Voltage Property | float | Motor votage in Volts |
Joint modes
| Name | Value | Description |
|---|---|---|
Backdrive | 238 | |
Booting | 247 | |
Bootloder | 249 | |
Calibration | 250 | |
Fault | 252 | |
Idle | 255 | |
MotorInitialisation | 246 | |
NotResponding | 245 | |
PartDCalibration | 237 | |
PartDCalibrationError | 248 | |
PowerOff | 239 | |
Running | 253 | |
ShuttingDown | 236 |
Tool data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageToolDataPackageEventArgs _value = ur.PrimaryInterface.ToolData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.ToolDataReceived += Ur_ToolDataReceived;}private void Ur_ToolDataReceived(object sender, ToolDataPackageEventArgs e) {// e contains the incoming package}
Tool data
| Member | Type | Description |
|---|---|---|
ToolDataPackageEventArgs() Constructor | ||
AnalogInput2 Property | double | Value of Analog input 2 (analog_in[2]) |
AnalogInput3 Property | double | Value of Analog input 3 (analog_in[3]) |
AnalogInputRange2 Property | AnalogRanges | Unit of analog input 2 (analog_in[2]) |
AnalogInputRange3 Property | AnalogRanges | Unit of analog input 3 (analog_in[3]) |
ToolCurrent Property | float | Tool current in Amps |
ToolMode Property | ToolModes | Tool mode |
ToolOutputVoltage Property | sbyte | Tool output voltage |
ToolTemperature Property | float | Tool Temperature in °C |
ToolVoltage48V Property | float | Actual robot voltage power supply |
Analog units of analog inputs and outputs
| Name | Value | Description |
|---|---|---|
Current | 0 | The analog value is in Amps (A) |
Voltage | 1 | The analog value is in Volts (V) |
Tool modes
| Name | Value | Description |
|---|---|---|
Bootloader | 249 | Bootloader |
Idle | 255 | Idle |
Running | 253 | Running |
Masterboard data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageMasterboardDataPackageEventArgs _value = ur.PrimaryInterface.MasterboardData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.MasterboardDataReceived += Ur_MasterboardDataReceived;}private void Ur_MasterboardDataReceived(object sender, MasterboardDataPackageEventArgs e) {// e contains the incoming package}
Masterboard data
| Member | Type | Description |
|---|---|---|
MasterboardDataPackageEventArgs() Constructor | ||
AnalogInput0 Property | double | Value of analog input 0 (analog_in[0]) |
AnalogInput1 Property | double | Value of analog input 1 (analog_in[1]) |
AnalogInputRange0 Property | AnalogRanges | Unit of analog input 0 (analog_in[0]) |
AnalogInputRange1 Property | AnalogRanges | Unit of analog input 1 (analog_in[1]) |
AnalogOutput0 Property | double | Value of analog output 0 (analog_out[0]) |
AnalogOutput1 Property | double | Value of analog output 1 (analog_out[1]) |
AnalogOutputDomain0 Property | AnalogRanges | Unit of analog output 0 (analog_out[0]) |
AnalogOutputDomain1 Property | AnalogRanges | Unit of analog output 1 (analog_out[1) |
DigitalInputs Property | MasterboardDigitalIO | Register where each bit is a digital input value |
DigitalOutputs Property | MasterboardDigitalIO | Register where each bit is a digital output value |
Euromap67Installed Property | sbyte | The robot is interfaced to injection molding machines Euromap 67 |
EuromapCurrent Property | float | Euromap current |
EuromapInputBits Property | int | Register where each bit is a digital Euromap input |
EuromapOutputBits Property | int | Register where each bit is a digital Euromap output |
EuromapVoltage Property | float | Euromap votage |
InReducedMode Property | byte | Robot is in reduced speed mode |
MasterIOCurrent Property | float | Current of all digital and analog inputs and outputs |
MasterboardTemperature Property | float | Temperature of masterboard in °C |
OperationalModeSelectorInput Property | byte | Position of operational mode selector input switch |
RobotCurrent Property | float | Robot current consumption in Amps |
RobotVoltage48V Property | float | Voltage of internal 48V power supply |
Safetymode Property | SafetyStatus | Masterboard safety mode |
ThreePositionEnablingDeviceInput Property | byte | Position of the 3-position enabling device |
Analog units of analog inputs and outputs
| Name | Value | Description |
|---|---|---|
Current | 0 | The analog value is in Amps (A) |
Voltage | 1 | The analog value is in Volts (V) |
| Member | Type | Description |
|---|---|---|
BitArray Property read only | BitArray | Register value seen as a bool array |
Configurable0 Property read only | bool | |
Configurable1 Property read only | bool | |
Configurable2 Property read only | bool | |
Configurable3 Property read only | bool | |
Configurable4 Property read only | bool | |
Configurable5 Property read only | bool | |
Configurable6 Property read only | bool | |
Configurable7 Property read only | bool | |
Digital0 Property read only | bool | |
Digital1 Property read only | bool | |
Digital2 Property read only | bool | |
Digital3 Property read only | bool | |
Digital4 Property read only | bool | |
Digital5 Property read only | bool | |
Digital6 Property read only | bool | |
Digital7 Property read only | bool | |
ToolDigital0 Property read only | bool | |
ToolDigital1 Property read only | bool | |
Value Property read only | int | Register value |
Safety modes
| Name | Value | Description |
|---|---|---|
AutomaticModeSafeguardStop | 10 | |
Fault | 9 | Safety is in fault mode |
Normal | 1 | Safety is in normal operating conditions |
ProtectiveStop | 3 | Protective safeguard Stop. This safety function is triggeredby an external protective device using safety inputs which will trigger a Cat 2 stop3per IEC 60204-1. |
Recovery | 4 | When a safety limit is violated, the safety system must be restarted. |
Reduced | 2 | Speed is reduced |
RobotEmergencyStop | 7 | (EA + EB + SBUS->Screen) Physical e-stop interface input activated |
SafeguardStop | 5 | (SI0 + SI1 + SBUS) Physical s-stop interface input |
SystemEmergencyStop | 6 | (EA + EB + SBUS->Euromap67) Physical e-stop interface input activated |
SystemThreePositionEnablingStop | 11 | |
Violation | 8 | Safety is in violation mode (for example, violation of the allowed delay between redundant signals) |
Cartesian information
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageCartesianInfoPackageEventArgs _value = ur.PrimaryInterface.CartesianInfo;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.CartesianInfoReceived += Ur_CartesianInfoReceived;}private void Ur_CartesianInfoReceived(object sender, CartesianInfoPackageEventArgs e) {// e contains the incoming package}
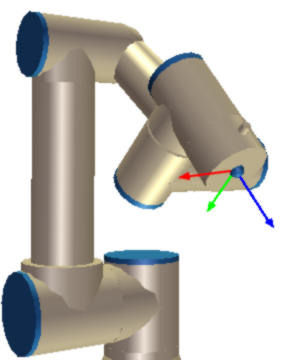
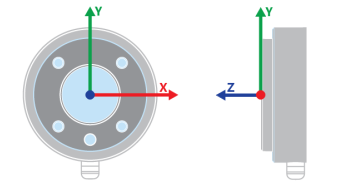
Contains current cartesian position of the robot, including its TCP offset
| Member | Type | Description |
|---|---|---|
CartesianInfoPackageEventArgs() Constructor | ||
Rx Property | double | RX axis coordinate in rad of the TCP in the current frame |
Ry Property | double | RY axis coordinate in rad of the TCP in the current frame |
Rz Property | double | RZ axis coordinate in rad of the TCP in the current frame |
TCPOffsetRX Property | double | RX position of the TCP in the flange frame in rad |
TCPOffsetRY Property | double | RY position of the TCP in the flange frame in rad |
TCPOffsetRZ Property | double | RZ position of the TCP in the flange frame in rad |
TCPOffsetX Property | double | X position of the TCP in the flange frame in meter |
TCPOffsetY Property | double | Y position of the TCP in the flange frame in meter |
TCPOffsetZ Property | double | Z position of the TCP in the flange frame in meter |
X Property | double | X axis coordinate in meter of the TCP in the current frame |
Y Property | double | Y axis coordinate in meter of the TCP in the current frame |
Z Property | double | Z axis coordinate in meter of the TCP in the current frame |
AsPose() Method | Pose | Returns the current cartesian position as a Pose object |
AsTCPOffsetPose() Method | Pose | Returns the TCP offset as a Pose object |
Kinematics information
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageKinematicsInfoPackageEventArgs _value = ur.PrimaryInterface.KinematicsInfo;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.KinematicsInfoReceived += Ur_KinematicsInfoReceived;}private void Ur_KinematicsInfoReceived(object sender, KinematicsInfoPackageEventArgs e) {// e contains the incoming package}
Kinematics info
| Member | Type | Description |
|---|---|---|
KinematicsInfoPackageEventArgs() Constructor | ||
A2 Property read only | double | DH parameter a2 (Shoulder.DHa) |
A3 Property read only | double | DH parameter a3 (Elbow.DHa) |
Base Property | JointKinematicsInfo | Base kinematics info |
CalibrationStatus Property | int | Calibration status (0 : OK) |
D1 Property read only | double | DH parameter d1 (Base.DHd) |
D4 Property read only | double | DH parameter d4 (Wrist1.DHd) |
D5 Property read only | double | DH parameter d5 (Wrist2.DHd) |
D6 Property read only | double | DH parameter d6 (Wrist3.DHd) |
Elbow Property | JointKinematicsInfo | Elbow kinematics info |
Shoulder Property | JointKinematicsInfo | Shoulder kinematics info |
Wrist1 Property | JointKinematicsInfo | Wrist1 kinematics info |
Wrist2 Property | JointKinematicsInfo | Wrist2 kinematics info |
Wrist3 Property | JointKinematicsInfo | Wrist3 (Tool) kinematics info |
Joint kinematics info, Denavit–Hartenberg (DH) parameters
| Member | Type | Description |
|---|---|---|
JointKinematicsInfo() Constructor | ||
Checksum Property | int | Joint checksum |
DHa Property | double | DH convention a parameter |
DHd Property | double | DH convention d parameter |
DHtheta Property | double | DH convention theta parameter |
Dhalpha Property | double | DH convention alpha parameter |
For more information about DH (Denavit-Hartenberg) parameters, please refer the following links :
Configuration data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageConfigurationDataPackageEventArgs _value = ur.PrimaryInterface.ConfigurationData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.ConfigurationDataReceived += Ur_ConfigurationDataReceived;}private void Ur_ConfigurationDataReceived(object sender, ConfigurationDataPackageEventArgs e) {// e contains the incoming package}
Joint configuration
| Member | Type | Description |
|---|---|---|
ConfigurationDataPackageEventArgs() Constructor | ||
A2 Property read only | double | DH parameter a2 (Shoulder.DHa) |
A3 Property read only | double | DH parameter a3 (Elbow.DHa) |
AJointDefault Property | double | Default joint acceleration speed in rad/s² |
AToolDefault Property | double | Default TCP acceleration speed in m/s² |
Base Property | JointConfiguration | Base joint configuration |
ControllerBoxType Property | ControllerBoxTypes | Controller box type |
D1 Property read only | double | DH parameter d1 (Base.DHd) |
D4 Property read only | double | DH parameter d4 (Wrist1.DHd) |
D5 Property read only | double | DH parameter d5 (Wrist2.DHd) |
D6 Property read only | double | DH parameter d6 (Wrist3.DHd) |
Elbow Property | JointConfiguration | Elbow joint configuration |
EqRadius Property | double | Equipment radius in meter |
MasterboardVersion Property | int | Masterboard version |
RobotSubType Property | RobotSubTypes | Robot serie |
RobotType Property | RobotModels | Model of the robot (UR3, UR5, UR10, UR16) |
Shoulder Property | JointConfiguration | Shoulder joint configuration |
VJointDefault Property | double | Default joint angular speed in rad/s |
VToolDefault Property | double | Default TCP speed speed in m/s |
Wrist1 Property | JointConfiguration | Wrist1 joint configuration |
Wrist2 Property | JointConfiguration | Wrist2 joint configuration |
Wrist3 Property | JointConfiguration | Wrist3 (Tool) joint configuration |
Controller box types
| Name | Value | Description |
|---|---|---|
UR10 | 5 | UR10 controller box |
UR16 | 16 | UR16 controller box |
UR20 | 10 | UR20 controller box |
UR3 | 6 | UR3 controller box |
UR30 | 11 | UR30 controller box |
UR5 | 4 | UR5 controller box |
Joint configuration
| Member | Type | Description |
|---|---|---|
JointConfiguration() Constructor | ||
DHa Property | double | a parameter of Denavit–Hartenberg (DH) convention |
DHalpha Property | double | Alpha parameter of Denavit–Hartenberg (DH) convention |
DHd Property | double | d parameter of Denavit–Hartenberg (DH) convention |
DHtheta Property | double | Theta parameter of Denavit–Hartenberg (DH) convention |
JointMaxAcceleration Property | double | Maximum rotation speed in rad/s² |
JointMaxLimit Property | double | Maximum angular position in rad |
JointMaxSpeed Property | double | Maximum rotation speed in rad/s |
JointMinLimit Property | double | Minimum angular position in rad |
Robot sub type (e-Serie or CB-Serie)
| Name | Value | Description |
|---|---|---|
CB2Serie | 1 | CB2-series (Firmware 1.x) |
CB3Serie | 2 | CB3-series (Firmware 3.x) |
ESerie | 3 | e-series (Firmware 5.x) |
Force mode data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageForceModeDataPackageEventArgs _value = ur.PrimaryInterface.ForceModeData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.ForceModeDataReceived += Ur_ForceModeDataReceived;}private void Ur_ForceModeDataReceived(object sender, ForceModeDataPackageEventArgs e) {// e contains the incoming package}
Force mode data
| Member | Type | Description |
|---|---|---|
ForceModeDataPackageEventArgs() Constructor | ||
RobotDexterity Property | double | Dexterity of the robot |
Rx Property | double | Rx torque in tool frame in Nm |
Ry Property | double | Ry torque in tool frame in Nm |
Rz Property | double | Rz torque in tool frame in Nm |
X Property | double | X force in tool frame in N |
Y Property | double | Y force in tool frame in N |
Z Property | double | Z force in tool frame in N |
Additional information
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageAdditionalInfoPackageEventArgs _value = ur.PrimaryInterface.AdditionalInfo;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.AdditionalInfoReceived += Ur_AdditionalInfoReceived;}private void Ur_AdditionalInfoReceived(object sender, AdditionalInfoPackageEventArgs e) {// e contains the incoming package}
Additional information
| Member | Type | Description |
|---|---|---|
AdditionalInfoPackageEventArgs() Constructor | ||
FreedriveButtonEnabled Property | bool | The free drive button is enabled |
FreedriveButtonPressed Property | bool | The free drive button is pressed |
IOEnabledFreedrive Property | bool | Free drive is enable via IO |
Calibration data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageCalibrationDataPackageEventArgs _value = ur.PrimaryInterface.CalibrationData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.CalibrationDataReceived += Ur_CalibrationDataReceived;}private void Ur_CalibrationDataReceived(object sender, CalibrationDataPackageEventArgs e) {// e contains the incoming package}
Calibration data
| Member | Type | Description |
|---|---|---|
CalibrationDataPackageEventArgs() Constructor | ||
Frx Property | double | Frx calibration data |
Fry Property | double | Fry calibration data |
Frz Property | double | Frz calibration data |
Fx Property | double | Fx calibration data |
Fy Property | double | Fy calibration data |
Fz Property | double | Fz calibration data |
Safety data
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageSafetyDataPackageEventArgs _value = ur.PrimaryInterface.SafetyData;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.SafetyDataReceived += Ur_SafetyDataReceived;}private void Ur_SafetyDataReceived(object sender, SafetyDataPackageEventArgs e) {// e contains the incoming package}
Safety internal data
| Member | Type | Description |
|---|---|---|
SafetyDataPackageEventArgs() Constructor | ||
Data Property | byte[] | Irrelevent (Internal use only) |
Tool communication information
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageToolCommunicationInfoPackageEventArgs _value = ur.PrimaryInterface.ToolCommunicationInfo;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.ToolCommunicationInfoReceived += Ur_ToolCommunicationInfoReceived;}private void Ur_ToolCommunicationInfoReceived(object sender, ToolCommunicationInfoPackageEventArgs e) {// e contains the incoming package}
Tool communication info
| Member | Type | Description |
|---|---|---|
ToolCommunicationInfoPackageEventArgs() Constructor | ||
BaudRate Property | int | Baude rate |
Parity Property | int | Parity |
RxIdleChars Property | float | RX Idle Chars |
StopBits Property | int | Stop bits |
ToolCommunicationIsEnabled Property | bool | Is the tool communication interface enabled |
TxIdleChars Property | float | TX Idle Chars |
Tool mode
private UR ur;private void Start() {ur = new UR(); // Create a new UR instanceur.Connect("192.168.0.1"); // Connect to the robot// ...// Direct access to last received packageToolModeInfoPackageEventArgs _value = ur.PrimaryInterface.ToolModeInfo;// Attach a delegate to the event triggered when new package comesur.PrimaryInterface.ToolModeInfoReceived += Ur_ToolModeInfoReceived;}private void Ur_ToolModeInfoReceived(object sender, ToolModeInfoPackageEventArgs e) {// e contains the incoming package}
Tool mode info
| Member | Type | Description |
|---|---|---|
ToolModeInfoPackageEventArgs() Constructor | ||
DigitalOutputMode0 Property | DigitalOutputConfigurations | Digital output 0 configuration |
DigitalOutputMode1 Property | DigitalOutputConfigurations | Digital output 1 configuration |
OutputMode Property | OutputModes | Digital output mode |
Digital output configuration (NPN, PNP, Push/Pull)
| Name | Value | Description |
|---|---|---|
PushPull | 3 | Push / Pull |
SinkingNPN | 1 | Sinking (NOPN) |
SourcingPNP | 2 | Sourcing (PNP) |