Try the SDK with the demo application
A Windows application, one executable and open source, that calls every function of the SDK. Test what your Yaskawa controller answers before you write any code.
The demo application lets you try the whole Yaskawa SDK on your Motoman controller, before you write any code. It is a Windows desktop application that exposes the functions of the SDK with buttons and fields, and shows what the controller answers.
Download
Download UnderAutomation.Yaskawa.Showcase.Forms.exe
There is no installer. The application is one self contained executable, built with .NET 8 for Windows: it runs on a PC without .NET. Copy it where you want, run it, delete it when you are done.
Windows can block a file downloaded from the internet. Right click the file, open Properties, check Unblock and click OK.
The application runs in the 30 day trial of the SDK. The License page registers a key.
What it does
The tree on the left has one page per topic. It connects to a real controller: MotoSim EG-VRC does not answer the High Speed Ethernet Server (see Develop without a robot).
Everything on this page can be tried without writing code, in the Connection page of the demo application.
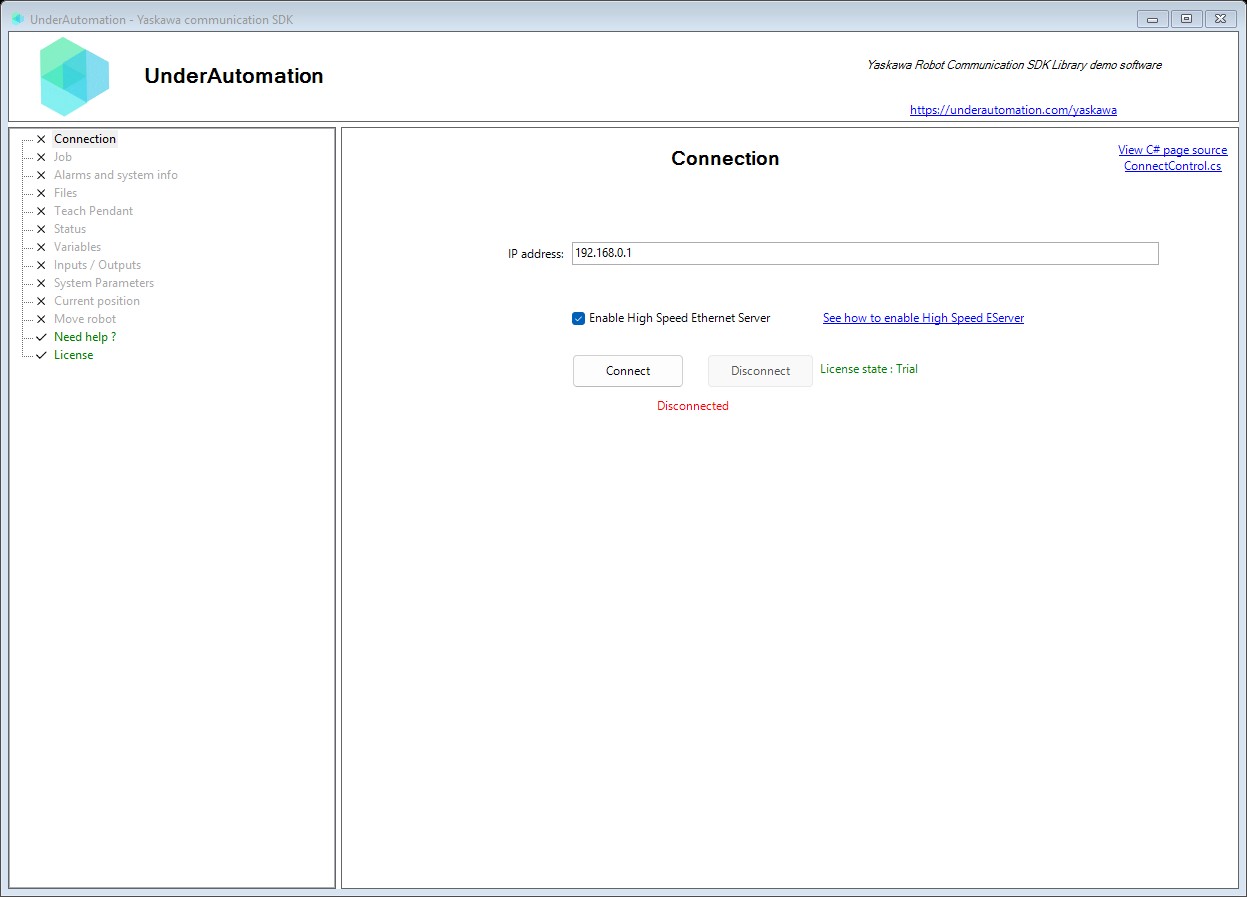
The demo application is open source. The C# source of this page is ConnectControl.cs.
| Page in the application | What you can try | Documentation |
|---|---|---|
| Connection | Address of the controller, connect | Connect to your robot |
| Job | List the jobs, select one at a line, servo on and off, start, read the call stack | Jobs |
| Alarms and system info | The active alarms, reset, the software version and the operating times | Alarms |
| Files | List, download, upload, edit and delete files, CMOS backup | Files and backup |
| Teach Pendant | Show a message on the pendant, lock and unlock it | Status and servo |
| Status | Mode, cycle, servo, hold and alarm flags | Status and servo |
| Variables | Read and write B, M, I, D, R, S and P variables | Variables and registers |
| Inputs / Outputs | Read the I/O groups of each type, write the network inputs | Inputs and outputs |
| System Parameters | Read a system parameter by type, number and group | System information and parameters |
| Current position | Cartesian position, joint pulses, position error and torque | Positions |
| Move robot | Cartesian and joint moves, with the frame, the speed, the tool and the posture | Motion |
| License | Register a license key, read the state of the trial | Licensing |
Start with the Connection page: the other pages stay disabled until a connection is open.
The Move robot page moves the arm. Try it with low speeds, in a cell with its safety functions active.
Read its source
The application is open source: github.com/underautomation/Yaskawa.NET, folder UnderAutomation.Yaskawa.Showcase.Forms.
It is a Windows Forms project for .NET 8. It references the same UnderAutomation.Yaskawa DLL as your project: there is nothing specific to the demo in the way it calls the SDK. Each page of the application is one C# user control in the Components folder. Copy the calls you need into your code.
What to read next
- Connect to your robot: the settings of the controller and the connection parameters, in code.
- High Speed Ethernet Server overview: what each topic covers.
- Licensing: the 30 day trial and the license key.