This page is only available in English.
Convert position types
Convert Rotation Vector to and from RPY
Overview
The class Pose contains the 6 coordinates of a cartesian position : 3 translations X, Y, Z in millimeters and 3 rotation RX, RY, RZ in radians. It also contains 3 rotations properties that exposes the 3 rotations in degrees, but it's not a storage, only a conversion of RX, RY and RZ.
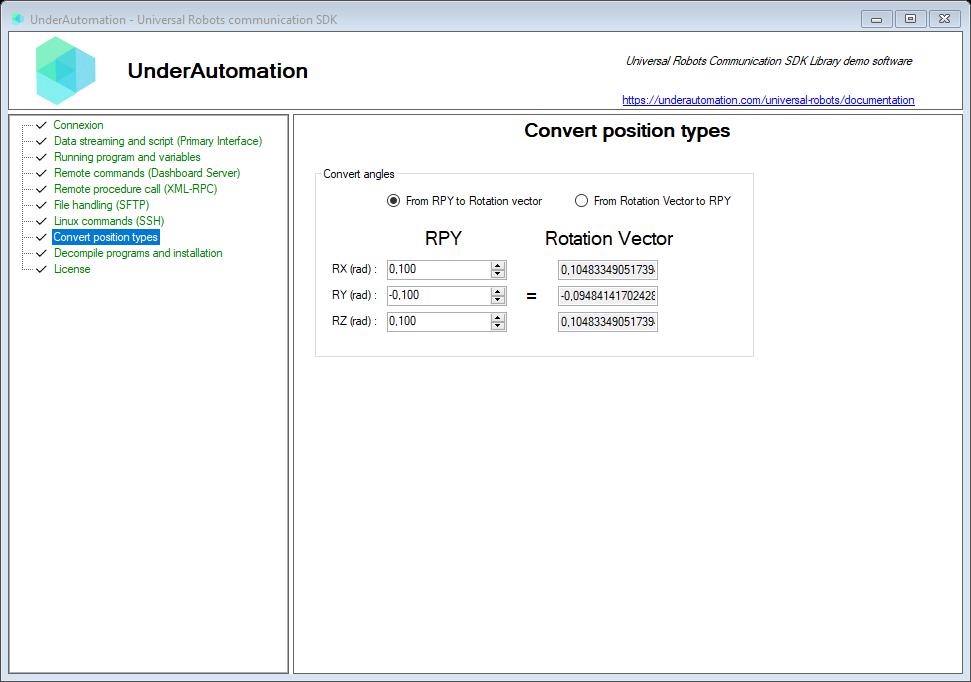
The methods FromRotationVectorToRPY() and FromRPYToRotationVector() transform the position in a new position with same translations X, Y, Z but different rotations.
A Pose instance can be returned in a XML-RPC answer. It will be interpreted as a robot pose.
Represents a UR pose
| Member | Type | Description |
|---|---|---|
Pose() Constructor | ||
Pose(double, double, double) Constructor | ||
Pose(double, double, double, double, double, double) Constructor | ||
Pose(Pose) Constructor | ||
RxDegrees Property | double | RX rotation in degrees or °/s |
RyDegrees Property | double | RY rotation in degrees or °/s |
RzDegrees Property | double | RZ rotation in degrees or °/s |
From4x4MatrixToRPY(double[,]) Method static | Pose | Convert a transformation 4x4 matrix to RPY pose |
From4x4MatrixToRotationVector(double[,]) Method static | Pose | Convert a transformation 4x4 matrix to rotation vector |
FromQuaternionToRotationVector(double, double, double, double) Method static | Pose | Converts a quaternion to UR rotation vector |
FromRPYTo4x4Matrix() Method | double[,] | Consider this pose as a rotation vector and return a 4x4 transformation matrix |
FromRPYToRotationVector() Method | Pose | Consider this pose as RPY And convert it to a new Rotation Vector |
FromRotationVectorTo4x4Matrix() Method | double[,] | Consider this pose as a RPY position and return a 4x4 transformation matrix |
FromRotationVectorToQuaternion(out double, out double, out double, out double) Method | void | Converts a rotation vector to quaternion |
FromRotationVectorToRPY() Method | Pose | Consider this pose as a Rotation Vector And convert it to a new RPY position |
ToString() Method | string | Returns 6 comma separated coordinated with G1 format |
TryParse(string, out Pose) Method static | bool | Pase a pose from its string representation
|
Try it with the Windows example