Connect to the robot
Enable the interfaces of the UR cobot, set the network and the remote control, then connect with ConnectParameters. Ports, settings and errors.
This page explains how to prepare a Universal Robots cobot for the SDK, and how to connect to it from C# or Python. It applies to CB-Series and e-Series robots with PolyScope, to the robots with PolyScope X, and to URSim.
Interfaces and ports
The SDK uses the standard interfaces of the robot. Each one is enabled in ConnectParameters, and some must also be enabled on the robot.
| Interface | Port | ConnectParameters | Default | Setting on the robot |
|---|---|---|---|---|
| Primary Interface | 30001 | PrimaryInterface | enabled | Service Primary Client Interface |
| Dashboard Server | 29999 | Dashboard | enabled | Service Dashboard Server. Not on PolyScope X |
| RTDE | 30004 | Rtde | disabled | Service RTDE |
| Interpreter Mode | 30020 | InterpreterMode | disabled | Service Interpreter Mode Socket |
| REST API | 80 | Rest | disabled | PolyScope X only |
| SSH and SFTP | 22 | Ssh.EnableSsh, Ssh.EnableSftp | disabled | Secure Shell enabled |
| XML-RPC server | 50000 (PC) | XmlRpc | disabled | None. The robot program connects to the PC |
| Socket server | 50001 (PC) | SocketCommunication | disabled | None. The robot program connects to the PC |
The Primary Interface can also use the Secondary Interface (30002) and the read only ports (30011, 30012), with PrimaryInterface.Port. The read only ports do not accept URScript.
Prepare the robot
Network
The robot and the PC must be on the same network, with addresses in the same subnet. On PolyScope, the address is set in the menu at the top right, Settings, System, Network.
Before it connects, Connect sends a ping to the robot and stops if the robot does not answer within 500 ms. When a firewall blocks the ping, set PingBeforeConnecting to false.
Services
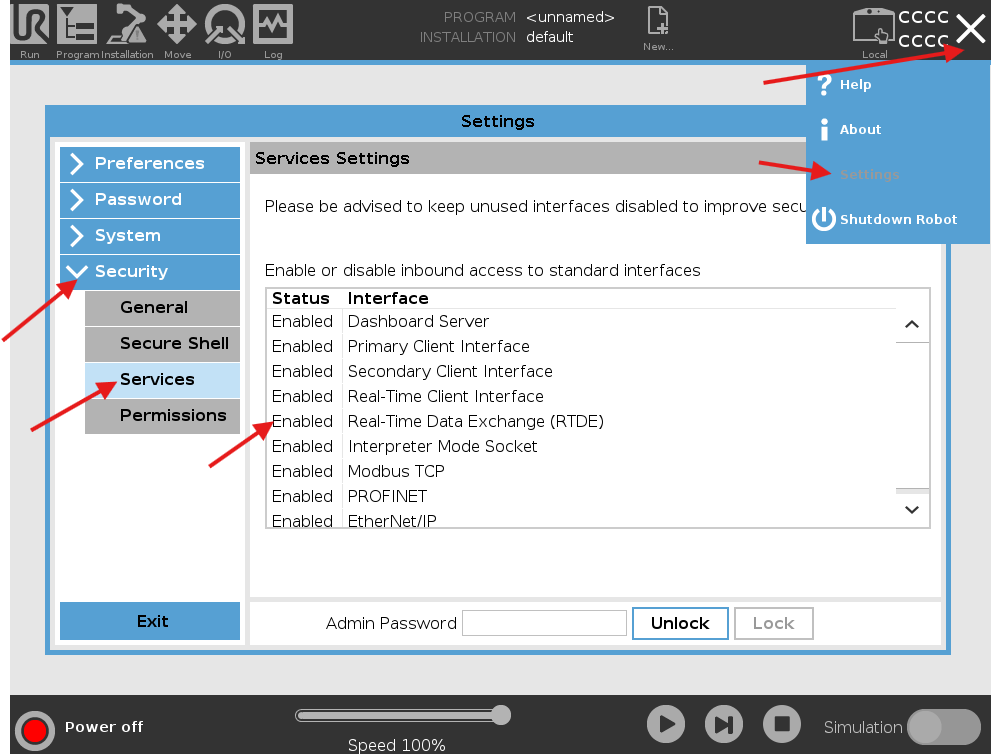
For security, each interface must be enabled on the robot. On PolyScope, open the menu at the top right, Settings, Security, Services, and enable the interfaces of the table above.
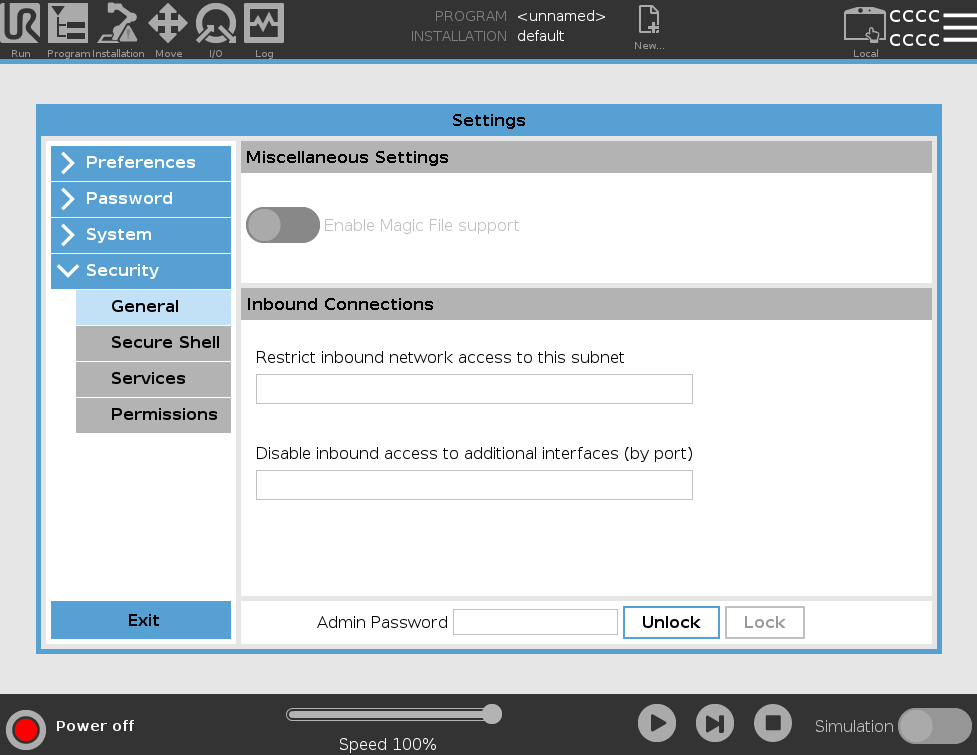
In Settings, Security, General, the inbound connections must not be restricted for the ports that the SDK uses.
Remote control
On e-Series and PolyScope X, the robot accepts commands from the network only in remote control: Dashboard commands that change its state (power, brakes, load, play), URScript sent with the Primary Interface, and REST commands. Reading data does not need it.
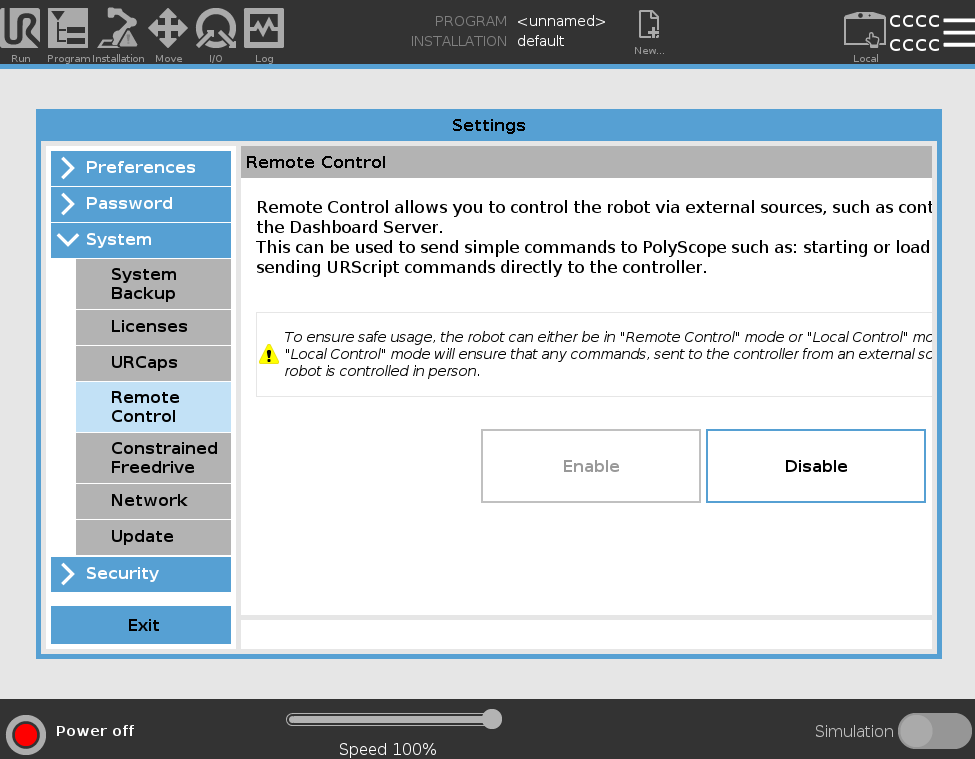
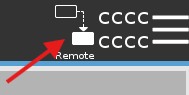
Enable the remote control in Settings, System, Remote Control, then switch the robot from Local to Remote with the icon at the top right of PolyScope.
Firewall of the PC
The antivirus or the firewall of the PC can block these ports. If the connection fails, check them first. The XML-RPC and socket servers listen on the PC: allow their ports in the firewall of the PC.
Connect
Connect("192.168.0.1") opens the Primary Interface and the Dashboard Server. To choose the interfaces and their settings, pass a ConnectParameters:
static void Main(string[] args){var robot = new UR();var parameters = new ConnectParameters("192.168.0.1");// Enabled by defaultparameters.PrimaryInterface.Enable = true;parameters.Dashboard.Enable = true;// RTDE: select the data to exchange and the frequencyparameters.Rtde.Enable = true;parameters.Rtde.Frequency = 500; // Hzparameters.Rtde.OutputSetup.Add(RtdeOutputData.ActualTcpPose);parameters.Rtde.OutputSetup.Add(RtdeOutputData.ActualQ);parameters.Rtde.InputSetup.Add(RtdeInputData.InputIntRegisters, 24);// Local XML-RPC server, called by the robot programparameters.XmlRpc.Enable = true;parameters.XmlRpc.Port = 50000;// Local socket server, the robot program connects to itparameters.SocketCommunication.Enable = true;parameters.SocketCommunication.Port = 50001;// SSH and SFTP, with the Linux user of the controllerparameters.Ssh.EnableSsh = true;parameters.Ssh.EnableSftp = true;parameters.Ssh.Username = "ur";parameters.Ssh.Password = "easybot";// Interpreter Mode and REST API (PolyScope X) are disabled by defaultparameters.InterpreterMode.Enable = false;parameters.Rest.Enable = false;robot.Connect(parameters);// ...// Close every servicerobot.Disconnect();}}
Contains parameters to connect to the robot
| Member | Type | Description |
|---|---|---|
ConnectParameters() Constructor | Initializes a new instance of ConnectParameters with default values. | |
ConnectParameters(string) Constructor | Initializes a new instance of ConnectParameters with the specified robot IP address.
| |
Dashboard Property | DashboardConnectParameters | Dashboard Server connection parameters (port 29999). |
IP Property | string | IP address of the Universal Robots controller. |
InterpreterMode Property | InterpreterModeConnectParameters | Interpreter Mode connection parameters for sending URScript lines interactively. |
PingBeforeConnecting Property | bool | If true, a ping is sent to the robot before attempting connection. Default is true. |
PrimaryInterface Property | PrimaryInterfaceConnectParameters | Primary Interface connection parameters (port 30001/30002). |
Rest Property | RestConnectParameters | REST API connection parameters (PolyscopeX only) |
Rtde Property | RtdeConnectParameters | Real-Time Data Exchange (RTDE) connection parameters (port 30004). |
SocketCommunication Property | SocketCommunicationConnectParameters | Socket communication connection parameters for exchanging data with URScript programs. |
Ssh Property | SshConnectParameters | SSH and SFTP connection parameters for file transfer and remote shell access. |
XmlRpc Property | XmlRpcConnectParameters | XML-RPC connection parameters for remote procedure calls. |
ToString() Method | string | Returns a string representation containing the robot IP address. |
Each interface is also a class that works without UR: PrimaryInterfaceClient, DashboardClient, RtdeClient, RestClient, SftpClient, SshClient, InterpreterModeClient, XmlRpcServer, SocketCommunicationServer. The page of each interface shows it.
Errors
Connect opens the interfaces one after the other. When one fails, it closes the others and throws:
| Exception | Cause |
|---|---|
InvalidLicenseException | The trial is over, or the license key is not valid |
ConnectException | One interface did not connect. Service names it, RobotIp gives the address |
Exception | The robot does not answer the ping, or the address is empty |
After the connection, the errors of the background threads raise the event InternalErrorOccured, on UR and on each client.
{var robot = new UR();try{robot.Connect("192.168.0.1");}catch (InvalidLicenseException ex){// The trial is over or the license key is not validConsole.WriteLine(ex.LicenseInfo);}catch (ConnectException ex){// One service did not connect: the other services are closedConsole.WriteLine($"{ex.Service} of {ex.RobotIp}: {ex.Message}");}catch (Exception ex){// For example, the robot does not answer the pingConsole.WriteLine(ex.Message);}// Errors that happen after the connection, in a background threadrobot.InternalErrorOccured += (sender, e) =>{Console.WriteLine($"{e.Status}: {e.Message}");};}}
Disconnect
Disconnect() closes every interface. Each client also has its own method: robot.Rtde.Disconnect(), robot.Dashboard.Disable()...
Try it in the demo application
Everything on this page can be tried without writing code, in the Connection page of the demo application.
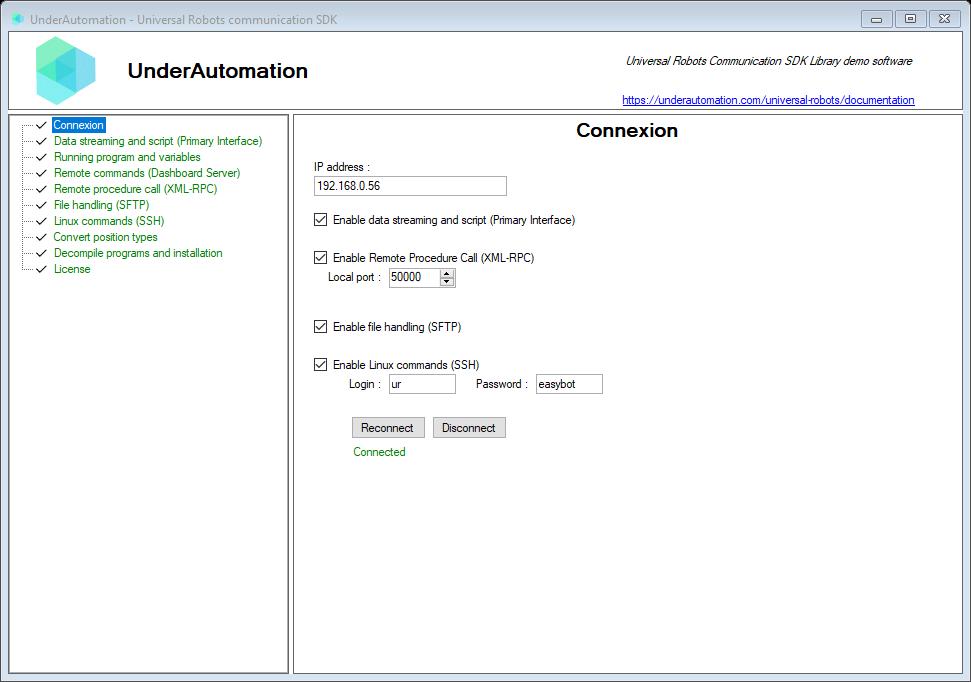
The demo application is open source. The C# source of this page is ConnectControl.cs.
What to read next
- Develop without a robot: install URSim.
- RTDE and Primary Interface: read the state of the robot.
- Licensing: the 30 day trial and the license key.