Mastership
Mastership is the write lock of the controller. Request and release it explicitly, or let the SDK take it implicitly for a single call.
Mastership is the write lock of the controller. Only one client holds it at a time, and a client that does not hold it cannot change anything. Reading never needs it. The service is robot.Rws.Mastership.
The mastership belongs to the connection that took it. Every call made through the same AbbController is the holder. It stays held until you release it or until the connection ends.
Domains
The mastership is not global, it is taken per domain. MastershipDomain has four values, and the two controller generations do not cut the controller the same way.
MastershipDomain | Covers | IRC5, RWS 1.0 | OmniCore, RWS 2.0 |
|---|---|---|---|
Motion | Jogging, mechanical units, anything that moves an axis | Its own domain | Its own domain |
Configuration | System parameters of the controller | Its own domain | Same domain as Edit |
Rapid | RAPID programs and their data | Its own domain | Same domain as Edit |
Edit | System parameters and RAPID programs together | Takes Configuration and Rapid in one call | Its own domain |
You can ask for any of the four values on any controller. The service maps them onto the domains the connected controller really has. GetDomains tells you which ones it exposes.
AbbController robot = new AbbController();robot.Connect("192.168.0.1");// Domains the connected controller really exposesforeach (MastershipDomain domain in robot.Rws.Mastership.GetDomains())Console.WriteLine(domain);// Motion is needed to move a mechanical unitrobot.Rws.Mastership.Request(MastershipDomain.Motion);robot.Rws.Mastership.Release(MastershipDomain.Motion);// Edit covers the system parameters and the RAPID programs at oncerobot.Rws.Mastership.Request(MastershipDomain.Edit);robot.Rws.Mastership.Release(MastershipDomain.Edit);// Without argument, every domain is taken and given backrobot.Rws.Mastership.Request();robot.Rws.Mastership.Release();robot.Disconnect();}
Request and release
Request takes a domain, Release gives it back. Without argument, both work on every domain of the controller at once.
Take the mastership as late as possible and give it back as early as possible. While you hold it, the operator of the robot cannot change the same domain from the teach pendant. Put the release in a finally block, so a failed write does not leave the lock taken.
AbbController robot = new AbbController();robot.Connect("192.168.0.1");// Take the write lock of the RAPID domainrobot.Rws.Mastership.Request(MastershipDomain.Rapid);try{robot.Rws.Rapid.SetSymbolValue("RAPID/T_ROB1/user/reg1", "12");robot.Rws.Rapid.SetSymbolValue("RAPID/T_ROB1/user/reg2", "34");}finally{// Give it back as early as possible, even when the write failedrobot.Rws.Mastership.Release(MastershipDomain.Rapid);}robot.Disconnect();}
A few points to know:
Requestfails when somebody else already holds the domain, and also when this connection already holds it.Release()without argument is accepted even when nothing is held. It is safe to call in afinallyblock.- In manual mode, the controller only grants the mastership once the operator has given your client the right to act on their behalf.
- When a value of the enum covers several domains of the connected controller,
Requesttakes them all. If one of them is refused, the parts already taken are given back before the error is reported.
Who holds the mastership
GetInfo returns a MastershipInfo per domain: who holds it, and whether it is this connection. HeldByMe is the property to test before a write.
AbbController robot = new AbbController();robot.Connect("192.168.0.1");// State of every domain of the controllerforeach (MastershipInfo info in robot.Rws.Mastership.GetInfo()){Console.WriteLine($"{info.Domain} : holder {info.Holder}, held by me {info.HeldByMe}");Console.WriteLine($" application {info.Application}, location {info.Location}");}// State of a single domainMastershipInfo motion = robot.Rws.Mastership.GetInfo(MastershipDomain.Motion);if (motion.Holder == MastershipHolder.None)Console.WriteLine("Motion is free, it can be taken");else if (!motion.HeldByMe)Console.WriteLine("Somebody else holds Motion, a write would fail with 403");robot.Disconnect();}
Holder is a MastershipHolder: None when the domain is free, Remote for a client on the network, Local for a device attached to the controller like the teach pendant, Internal when the controller itself holds it during an operation that must not be interrupted.
Implicit mastership
Two operations take the mastership for you, use it for a single request and give it back immediately: Panel.SetSpeedRatio and Controller.Restart. This is the default. Pass false for the useImplicitMastership parameter when your own code already holds the mastership, otherwise the controller refuses the second request on a domain you already hold.
AbbController robot = new AbbController();robot.Connect("192.168.0.1");// The mastership is taken for this single call and given back right afterrobot.Rws.Panel.SetSpeedRatio(50);// Same behaviour for a restart of the controllerrobot.Rws.Controller.Restart(ControllerRestartMode.Restart);// Set the flag to false when your own code already holds the mastershiprobot.Rws.Mastership.Request();try{robot.Rws.Panel.SetSpeedRatio(100, false);}finally{robot.Rws.Mastership.Release();}robot.Disconnect();}
Every other write operation needs an explicit Request.
What happens without mastership
The controller answers with the HTTP status code 403, and the SDK throws an RwsException with StatusCode set to 403. The same code is used when the user account lacks the UAS grant, so check the mastership state to tell the two cases apart.
AbbController robot = new AbbController();robot.Connect("192.168.0.1");try{// No mastership taken, the controller refuses the writerobot.Rws.Rapid.SetSymbolValue("RAPID/T_ROB1/user/reg1", "5");}catch (RwsException ex) when (ex.StatusCode == 403){// Find out who holds the domainMastershipInfo info = robot.Rws.Mastership.GetInfo(MastershipDomain.Rapid);Console.WriteLine($"{info.Domain} is held by {info.Holder} ({info.Application})");}robot.Disconnect();}
Operations that need the mastership:
| Domain | Examples |
|---|---|
Rapid | Write a RAPID variable, load or unload a module, start and stop the program, move the program pointer |
Motion | Jog the robot, change the position of a mechanical unit, calibration operations |
Configuration | Change the system parameters, the network configuration, the time zone |
Try it in the demo application
Everything on this page can be tried without writing code, in the Mastership (RWS) page of the demo application.
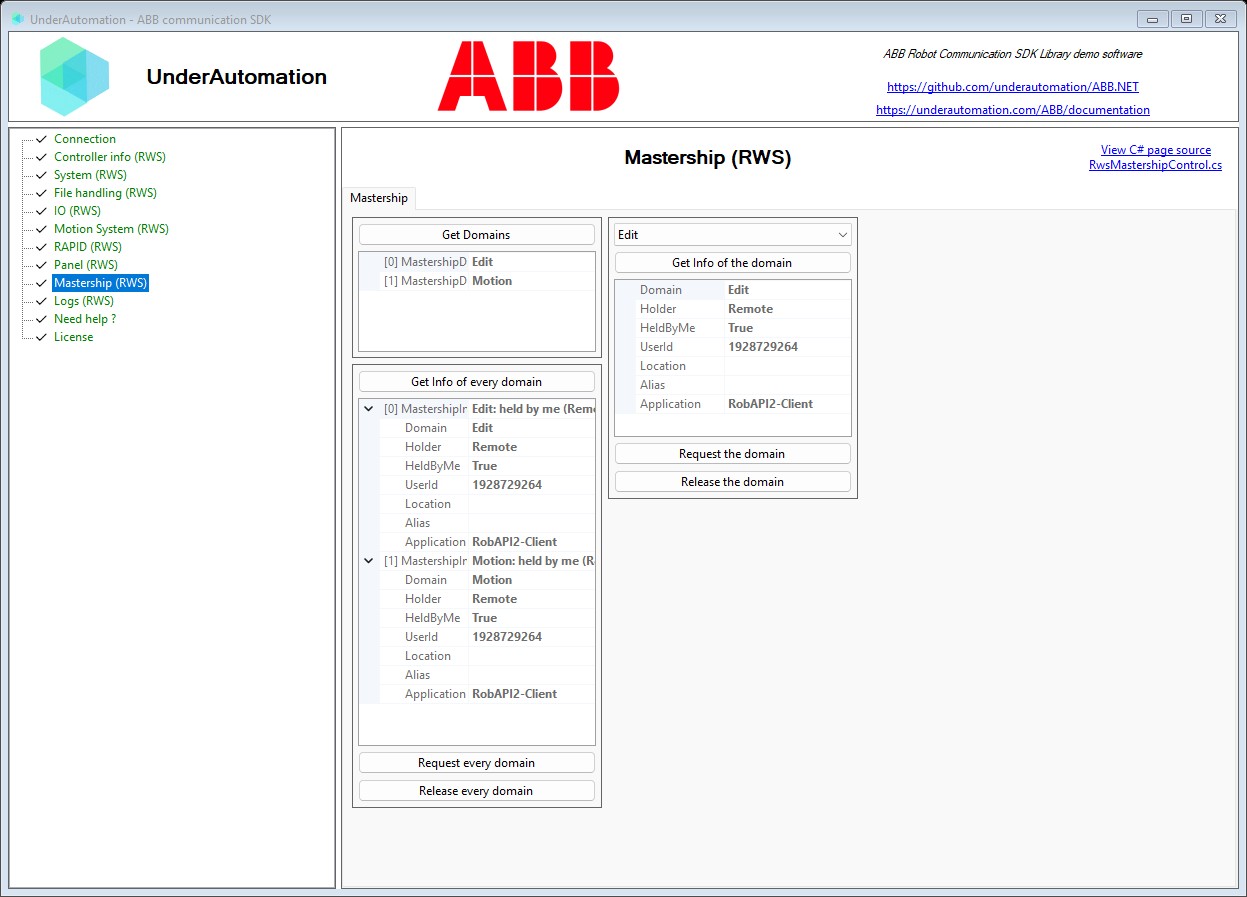
The demo application is open source. The C# source of this page is RwsMastershipControl.cs.
API reference
Methods of MastershipService :// Gets the domains the connected controller can give the mastership of (synchronous)MastershipDomain[] GetDomains();// Gets who holds the mastership of every domain of the controller (synchronous)MastershipInfo[] GetInfo();// Gets who holds the mastership of one domain (synchronous)MastershipInfo GetInfo(MastershipDomain domain);// Gives back the mastership of every domain of the controller (synchronous)void Release();// Gives back the mastership of one domain (synchronous)void Release(MastershipDomain domain);// Takes the mastership of every domain of the controller (synchronous)void Request();// Takes the mastership of one domain (synchronous)void Request(MastershipDomain domain);
Every method also exists in an asynchronous version, with the same name followed by Async and an optional CancellationToken.
State of the mastership of one domain: who holds it, and whether this connection is the holder. Returned by MastershipService.GetInfo().
| Member | Type | Description |
|---|---|---|
MastershipInfo() Constructor | Initializes a new instance of the MastershipInfo class | |
Alias Property | string | Alternate name of the location of the holder, null when nobody holds the mastership |
Application Property | string | Name of the application holding the mastership, null when nobody holds it |
Domain Property | MastershipDomain | Domain this state describes |
HeldByMe Property | bool | Whether this connection is the one holding the mastership, and is therefore allowed to write in the domain |
Holder Property | MastershipHolder | Who holds the mastership of the domain |
Location Property | string | Where the holder is, as it declared itself, null when nobody holds the mastership |
UserId Property | long? | Identifier the controller gave the user holding the mastership, null when nobody holds it |
ToString() Method | string | Returns a string representation of this mastership state |
Domain of the controller a client can take the mastership of. Mastership is what a client has to hold before it is allowed to change anything in a domain. Only one client at a time holds it, and it stays held until the client releases it or its connection ends. The two connection versions do not cut the controller in the same domains: a connection established with version 1 keeps the configuration and the RAPID programs apart, a connection established with version 2 covers both with Edit. Whichever name is used, the service asks the connected controller for the domains it really has.
| Name | Value | Description |
|---|---|---|
Configuration | 2 | The system parameters of the controller. On a connection established with version 2, where it is not a domain of its own, this is the same domain as Edit. |
Edit | 0 | Everything that changes the system itself: its configuration and its RAPID programs. On a connection established with version 1, where the two are separate domains, asking for this one takes Configuration and Rapid together. |
Motion | 1 | The movement of the robot: jogging, the mechanical units and everything that makes an axis move |
Rapid | 3 | The RAPID programs and their data. On a connection established with version 2, where it is not a domain of its own, this is the same domain as Edit. |
Who holds the mastership of a domain
| Name | Value | Description |
|---|---|---|
Internal | 4 | The controller itself holds it, while it runs an operation that must not be interrupted |
Local | 3 | A device attached to the controller holds it, the teach pendant for instance |
None | 1 | Nobody holds the mastership, it is free to be taken |
Remote | 2 | A client connected over the network holds it, possibly this one |
Unknown | 0 | The controller reported a holder this library does not know |