Forward & Inverse Kinematics
Perform forward and inverse kinematics calculations offline for FANUC industrial robots and CRX cobots using DH parameters.
- Why this matters for both industrial arms and cobots
- Typical workflows
- Run forward kinematics (FK)
- Solve inverse kinematics (IK) for an OPW robot
- Solve inverse kinematics (IK) for a CRX cobot
- Build DH parameters from multiple sources
- Practical tips
- Online Forward and Inverse Kinematics
- Forward kinematics using SNPX position registers
- Inverse kinematics using SNPX position registers
- Demonstration
- Core types at a glance
Inverse kinematics (IK) and forward kinematics (FK) let you move between joint space and Cartesian space. FK computes the tool p ose from known joint angles, while IK finds joint angles for a desired pose. The kinematics utilities in the Fanuc SDK are off line helpers: you can evaluate poses and joint solutions without connecting to a controller, making them perfect for simulatio n, path validation, and pre-deployment checks.
Why this matters for both industrial arms and cobots
The SDK ships with two analytical solvers and automatically chooses the right one for you:
- OPW industrial arms: Classical 6-axis Fanuc robots with an ortho-parallel base and spherical wrist, based on the paper
An Analytical Solution of the Inverse Kinematics Problem of Industrial Serial Manipulators with an Ortho-parallel Basis and a Spherical Wristby Mathias Brandstötter, Arthur Angerer, and Michael Hofbaur. - CRX collaborative arms: Fanuc CRX cobots that have their own closed-form solver and optional dual solutions, based on paper
Geometric Approach for Inverse Kinematics of the FANUC CRX Collaborative Robotby Manel Abbes and Gérard Poisson.
When you call KinematicsUtils.InverseKinematics(), it inspects DhParameters.KinematicsCategory:
KinematicsCategory.Opw👉 dispatches toOpw.OpwKinematicsUtils.InverseKinematics(industrial robots).KinematicsCategory.Crx👉 dispatches toCrx.CrxKinematicsUtils.InverseKinematics(CRX cobots).
That means you can rely on a single entry point and let the SDK route the request appropriately. 🚦
Typical workflows
Run forward kinematics (FK)
static void Main(){// Load robot geometryvar dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.CRX10iA);// Joint angles in degrees (Fanuc convention)var jointsDeg = new JointsPosition { J1 = 0, J2 = -30, J3 = 45, J4 = 0, J5 = 60, J6 = 90 };// Compute pose: returns XYZ + WPRCartesianPosition pose = KinematicsUtils.ForwardKinematics(jointsDeg, dh);}}
Solve inverse kinematics (IK) for an OPW robot
static void Main(){// OPW industrial robotvar dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.ARCMate120iD);var target = new CartesianPosition { X = 800, Y = 0, Z = 450, W = 180, P = 0, R = 90 };JointsPosition[] solutions = KinematicsUtils.InverseKinematics(target, dh);// CRX cobot with dual solutionsvar dhCrx = DhParameters.FromArmKinematicModel(ArmKinematicModels.CRX10iAL);var targetCrx = new CartesianPosition { X = 400, Y = 250, Z = 650, W = 0, P = 90, R = 0 };JointsPosition[] crxSolutions = CrxKinematicsUtils.InverseKinematics(targetCrx, dhCrx,includeDuals: true);}}
Solve inverse kinematics (IK) for a CRX cobot
The CRX solver uses a closed-form geometric approach and returns all valid joint solutions directly. No seed position is required. Pass includeDuals: true (C#) or include_duals=True (Python) to also include the dual configurations defined by the CRX kinematics.
using UnderAutomation.Fanuc.Common;using UnderAutomation.Fanuc.Kinematics;using UnderAutomation.Fanuc.Kinematics.Crx;public class KinematicsIK{static void Main(){// OPW industrial robotvar dh = DhParameters.FromArmKinematicModel(ArmKinematicModels.ARCMate120iD);var target = new CartesianPosition { X = 800, Y = 0, Z = 450, W = 180, P = 0, R = 90 };JointsPosition[] solutions = KinematicsUtils.InverseKinematics(target, dh);// CRX cobot with dual solutionsvar dhCrx = DhParameters.FromArmKinematicModel(ArmKinematicModels.CRX10iAL);var targetCrx = new CartesianPosition { X = 400, Y = 250, Z = 650, W = 0, P = 90, R = 0 };JointsPosition[] crxSolutions = CrxKinematicsUtils.InverseKinematics(targetCrx, dhCrx,includeDuals: true);}}
Build DH parameters from multiple sources
- Built-in catalog:
DhParameters.FromArmKinematicModel(ArmKinematicModels model)gives you ready-to-use geometry for many Fanuc arms and cobots. - ROBOGUIDE library:
DhParameters.FromDefFile(path)parses robot definitions inProgramData/FANUC/ROBOGUIDE/Robot Library. - Controller variables:
DhParameters.FromSymotnFileandDhParameters.FromMrrGrpconvert live$MRR_GRPorsymotn.vad ata to reusable DH structures. - OPW data:
DhParameters.FromOpwParametersmaps OPW parameters (meters) to Fanuc-style DH while keeping the kinematics cat egory consistent.
Practical tips ✨
- Offline safety: Because all solvers are offline, you can iterate quickly without touching a robot controller.
- Pose normalization:
OpwKinematicsUtils.InverseKinematicsnormalizes angles to(-180, 180]to match Fanuc expectations. - CRX dual solutions: Pass
includeDuals: truetoCrxKinematicsUtils.InverseKinematicsto include the additional configurations defined by the CRX kinematics model. - Matrix helpers:
KinematicsUtils.Mulmultiplies 2D matrices if you need to compose transforms manually.
Happy path-planning! 🛠️
Online Forward and Inverse Kinematics
Forward kinematics using SNPX position registers
Leverage the controller's built-in FK solver by writing joint angles and reading back the Cartesian pose:
FanucRobot _robot = new FanucRobot();_robot.Connect("192.168.0.1");// Forward kinematics via SNPX: joints → CartesianJointsPosition jointsPosition = new JointsPosition(10, 12, 50, 20, 12, 16);_robot.Snpx.PositionRegisters.Write(1, jointsPosition);CartesianPosition cartesianPosition = _robot.Snpx.PositionRegisters.Read(1).CartesianPosition;// Inverse kinematics via SNPX: Cartesian → jointsCartesianPosition targetPosition = new CartesianPosition() { X = 100, Y = 100, Z = 100 };targetPosition.Configuration.WristFlip = WristFlip.Flip;targetPosition.Configuration.ArmUpDown = ArmUpDown.Down;targetPosition.Configuration.ArmLeftRight = ArmLeftRight.Left;_robot.Snpx.PositionRegisters.Write(1, targetPosition);JointsPosition resultJoints = _robot.Snpx.PositionRegisters.Read(1).JointsPosition;}}
Inverse kinematics using SNPX position registers
Let the controller solve IK by writing a Cartesian pose and reading back joint angles. You will only have 1 solution since the cartesian position contains the configuration.
Demonstration
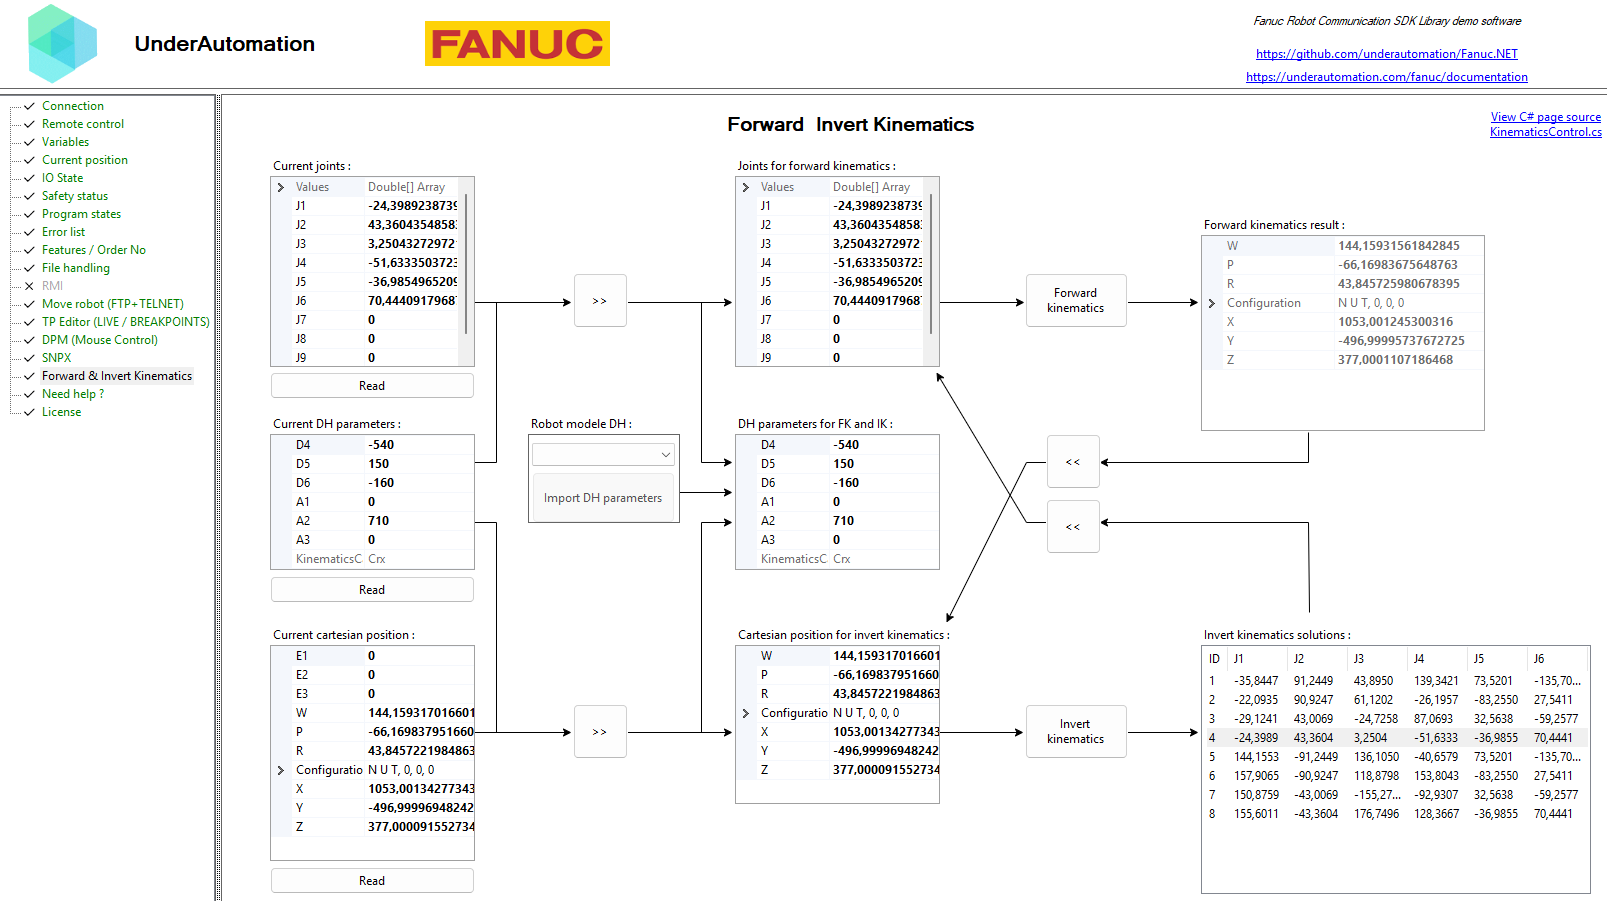
Have a look at : https://fanuc-kinematics.underautomation.com
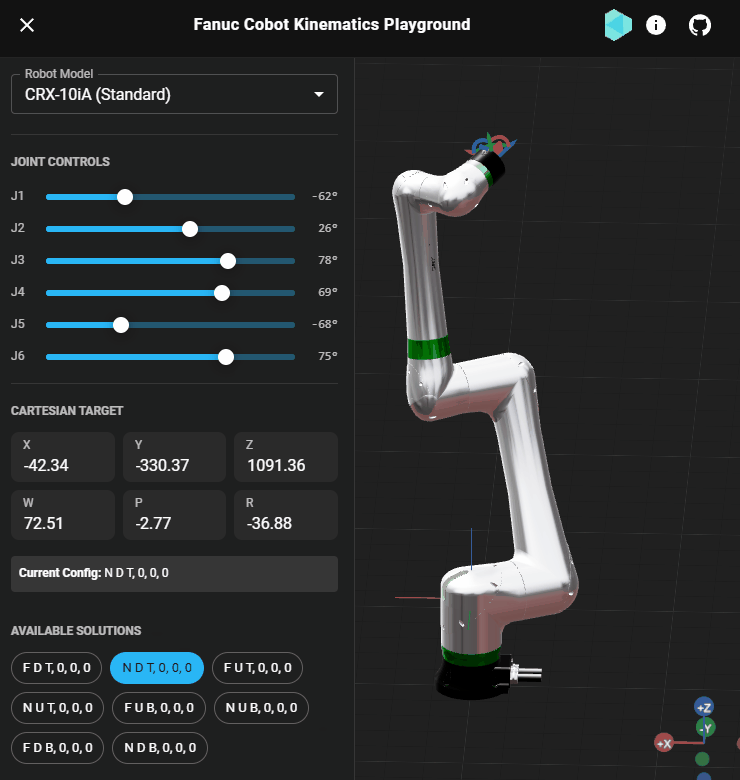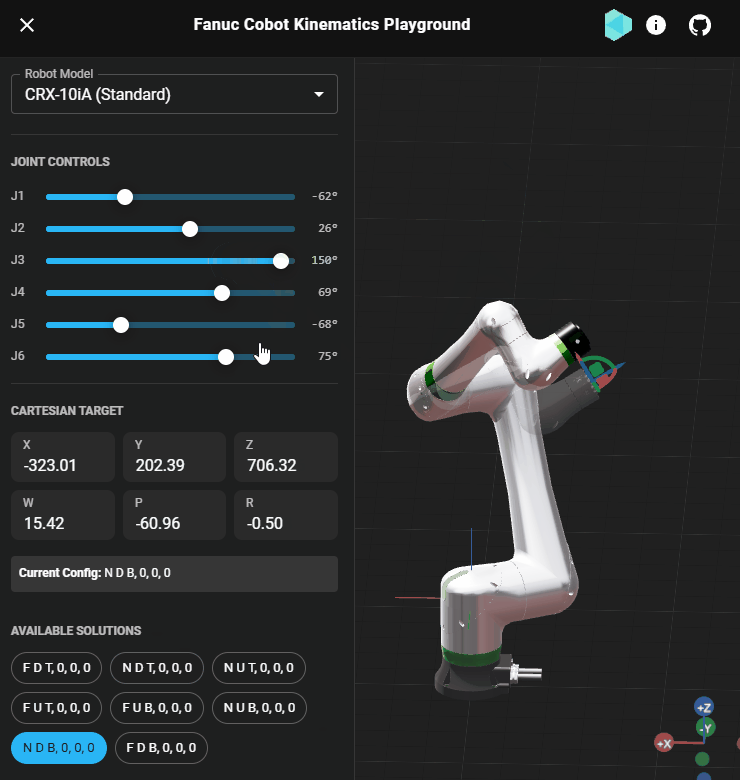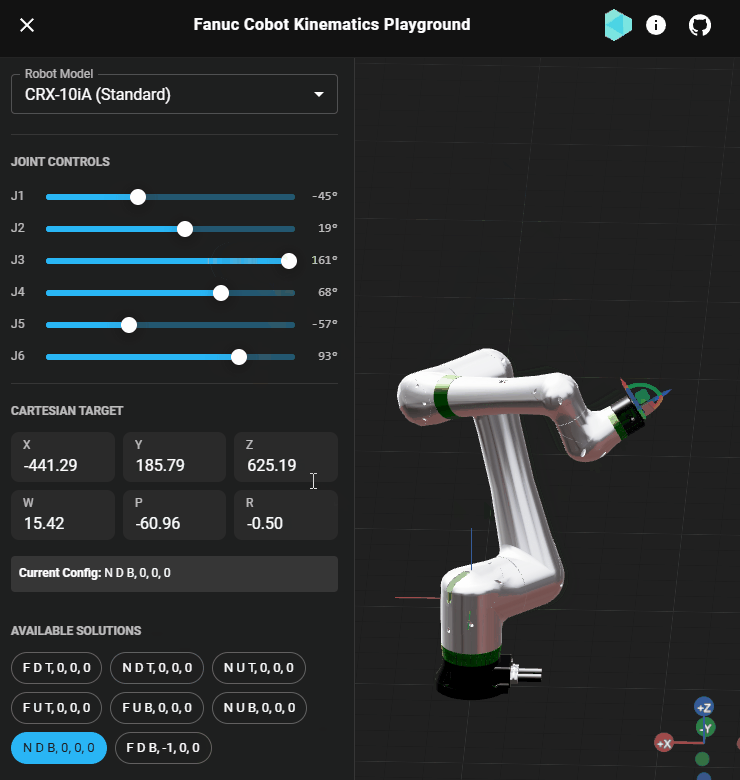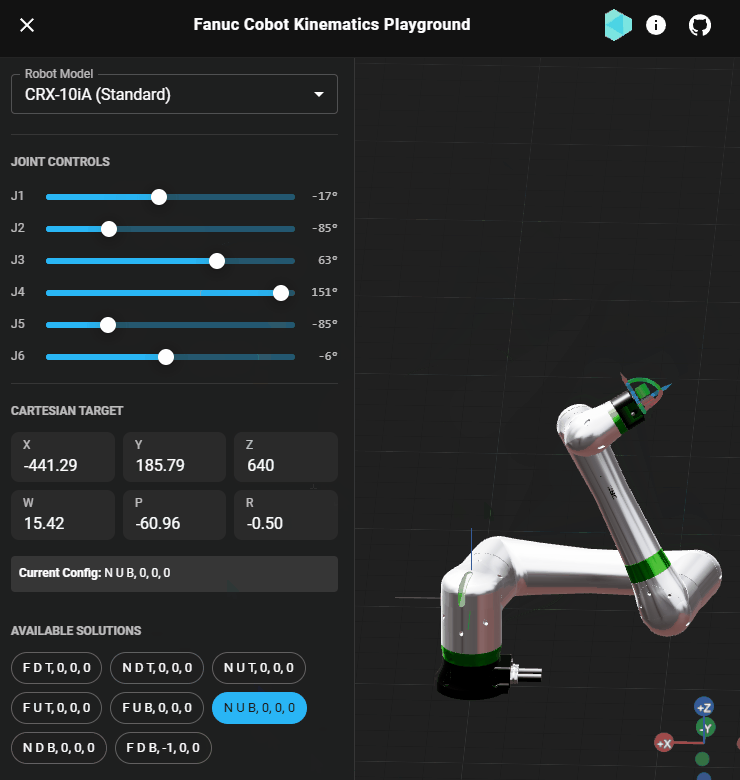
You can also take a look at the Winforms Desktop project source which implements all these features. I can be downloaded here.
Core types at a glance
Kinematics utilities
| Member | Type | Description |
|---|---|---|
ForwardKinematics(double[], DhParameters) Method static | CartesianPosition | Compute FK for given joint angles (rad) and DH parameters |
ForwardKinematics(JointsPosition, DhParameters) Method static | CartesianPosition | Compute FK for given joint angles (deg) and DH parameters |
InverseKinematics(CartesianPosition, DhParameters) Method static | JointsPosition[] | Compute all inverse kinematics solutions for a desired end effector pose.
|
Mul(double[,], double[,]) Method static | double[,] | Multiply two 4x4 homogeneous transformation matrices.
|
Denavit-Hartenberg parameters for a 6-axis robot arm.
| Member | Type | Description |
|---|---|---|
DhParameters() Constructor | Initializes a new empty instance of DhParameters. | |
DhParameters(double, double, double, double, double, double) Constructor | Initializes a new instance of DhParameters with the specified values.
| |
DhParameters(IDhParameters) Constructor | Initializes a new instance of DhParameters by copying from an existing IDhParameters.
| |
A1 Property | double | DH parameter A1 (mm). |
A2 Property | double | DH parameter A2 (mm). |
A3 Property | double | DH parameter A3 (mm). |
D4 Property | double | DH parameter D4 (mm). |
D5 Property | double | DH parameter D5 (mm). |
D6 Property | double | DH parameter D6 (mm). |
KinematicsCategory Property read only | KinematicsCategory | Gets the kinematics category determined from the DH parameter values. |
Tag Field | object | User-defined tag for associating additional data with this instance. |
Equals(object) Method | bool | |
FromArmKinematicModel(string) Method static | DhParameters | Returns DH parameters from a known Arm Kinematic Model name. Returns null if not found in enum ArmKinematicModels. |
FromArmKinematicModel(ArmKinematicModels) Method static | DhParameters | Returns DH parameters from a known Arm Kinematic Model. |
FromDefFile(string) Method static | DhParameters[] | Loads DH parameters of each robots described in a ROBOGUIDE definition file (*.def). By default, this file is located in "C:\ProgramData\FANUC\ROBOGUIDE\Robot Library". |
FromDefFile(XDocument) Method static | DhParameters[] | Loads DH parameters of each robots described in a ROBOGUIDE definition file (*.def). By default, this file is located in "C:\ProgramData\FANUC\ROBOGUIDE\Robot Library". |
FromMrrGrp(MrrGrpVariableType) Method static | DhParameters | Loads DH parameters from parsed variable $MRR_GRP located in symotn.va. |
FromOpwParameters(double, double, double, double, double) Method static | DhParameters | Creates DH parameters from OPW parameters (in meters) C1 and B are ignored because B is always 0 and C1 is not used in the DH representation.
|
FromSymotnFile(SymotnFile) Method static | DhParameters[] | Loads DH parameters of each group from a parsed symotn.va file. |
GetHashCode() Method | int | |
ToString() Method | string |
Category of kinematics model for a robot arm.
| Name | Value | Description |
|---|---|---|
Crx | 1 | CRX collaborative robot kinematics. |
Invalid | 0 | Invalid or unsupported kinematics configuration. |
Opw | 2 | OPW (ortho-parallel wrist) kinematics for standard industrial robots. |
Interface defining the Denavit-Hartenberg parameters for a 6-axis robot arm.
| Member | Type | Description |
|---|---|---|
A1 Property read only | double | DH parameter A1 (mm). |
A2 Property read only | double | DH parameter A2 (mm). |
A3 Property read only | double | DH parameter A3 (mm). |
D4 Property read only | double | DH parameter D4 (mm). |
D5 Property read only | double | DH parameter D5 (mm). |
D6 Property read only | double | DH parameter D6 (mm). |
Joints position in degrees
| Member | Type | Description |
|---|---|---|
JointsPosition() Constructor | Default constructor | |
JointsPosition(double, double, double, double, double, double) Constructor | Constructor with 6 joint values in degrees | |
JointsPosition(double, double, double, double, double, double, double, double, double) Constructor | Constructor with 9 joint values in degrees | |
JointsPosition(double[]) Constructor | Constructor from an array of joint values in degrees | |
this[int] Property | double | Gets or sets the joint value at the specified index |
J1 Property | double | Joint 1 in degrees |
J2 Property | double | Joint 2 in degrees |
J3 Property | double | Joint 3 in degrees |
J4 Property | double | Joint 4 in degrees |
J5 Property | double | Joint 5 in degrees |
J6 Property | double | Joint 6 in degrees |
J7 Property | double | Joint 7 in degrees |
J8 Property | double | Joint 8 in degrees |
J9 Property | double | Joint 9 in degrees |
Values Property read only | double[] | Numeric values for each joints |
Equals(object) Method | bool | |
GetHashCode() Method | int | |
IsNear(JointsPosition, JointsPosition, double) Method static | bool | Check if joints position is near to expected joints position with a tolerance value |
ToString() Method | string |
Fanuc cartesian position and rotations
| Member | Type | Description |
|---|---|---|
CartesianPosition() Constructor | Default constructor | |
CartesianPosition(double, double, double, double, double, double) Constructor | Constructor with position and rotations | |
CartesianPosition(double, double, double, double, double, double, Configuration) Constructor | Constructor with position, rotations and configuration | |
CartesianPosition(CartesianPosition) Constructor | Copy constructor | |
CartesianPosition(XYZPosition, double, double, double) Constructor | Constructor from an XYZ position with rotations | |
Configuration Property | Configuration | Position configuration |
Equals(object) Method | bool | |
FromHomogeneousMatrix(double[,]) Method static | CartesianPosition | Create a CartesianPosition with unknow configuration from a homogeneous rotation and translation 4x4 matrix
|
GetHashCode() Method | int | |
IsNear(CartesianPosition, CartesianPosition, double, double) Method static | bool | Check if two Cartesian positions are near each other within specified tolerances |
NormalizeAngle(double) Method static | double | Normalize an angle to the range ]-180, 180] |
NormalizeAngles(CartesianPosition) Method static | void | Normalize the W, P, R angles to the range ]-180, 180] |
ToHomogeneousMatrix() Method | double[,] | Convert position to a homogeneous rotation and translation 4x4 matrix |
ToString() Method | string |