Get started with LabVIEW
Use the VIs of the Yaskawa SDK in LabVIEW 2010 to 2024: status, alarms, positions, motion, jobs, variables, I/O and files of a Motoman controller.
This page shows how to use the Yaskawa SDK from LabVIEW, to read and control a Yaskawa Motoman controller through its High Speed Ethernet Server. The library is a set of VIs grouped in UnderAutomation.Yaskawa.lvlib, compatible with LabVIEW 2010 to 2024 on Windows. Nothing is installed on the controller.
Download
The releases of Yaskawa.vi contain one zip per LabVIEW version, UnderAutomation.Yaskawa_LabVIEW_<year>.zip. Each zip contains:
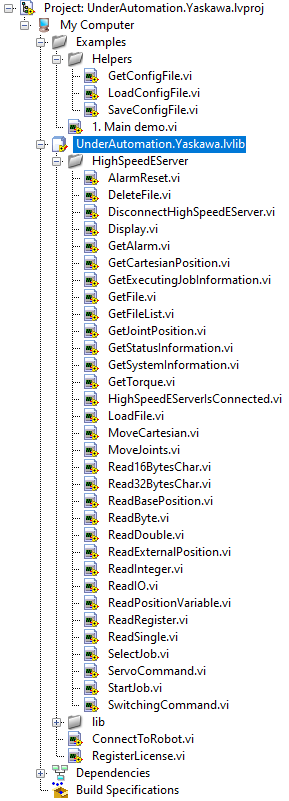
UnderAutomation.Yaskawa.lvproj: the project, with the exampleExamples/1. Main demo.vi;UnderAutomation.Yaskawa/UnderAutomation.Yaskawa.lvlib: the library of VIs;UnderAutomation.Yaskawa/lib/UnderAutomation.Yaskawa.dll: the .NET library called by the VIs.
On Windows, unblock the zip before you extract it: right click, Properties, check Unblock.
The sources are on GitHub: github.com/underautomation/Yaskawa.vi. Questions and bug reports go to its issues.
Example application
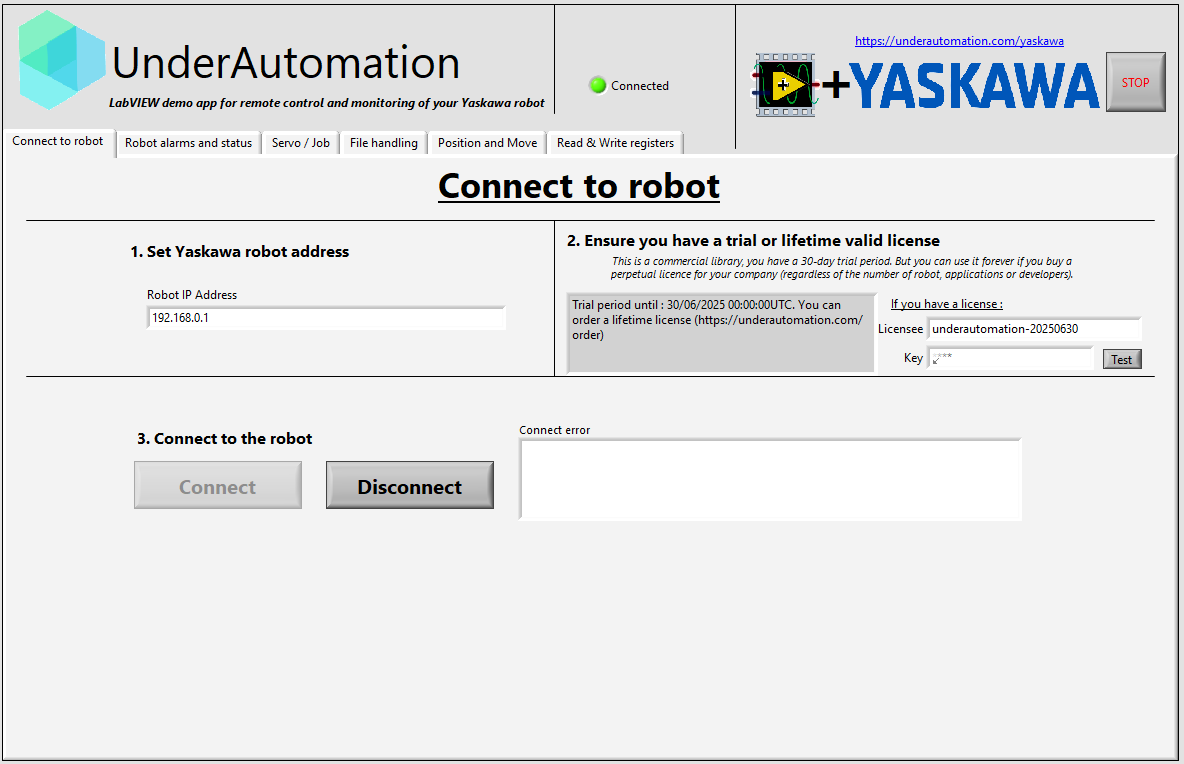
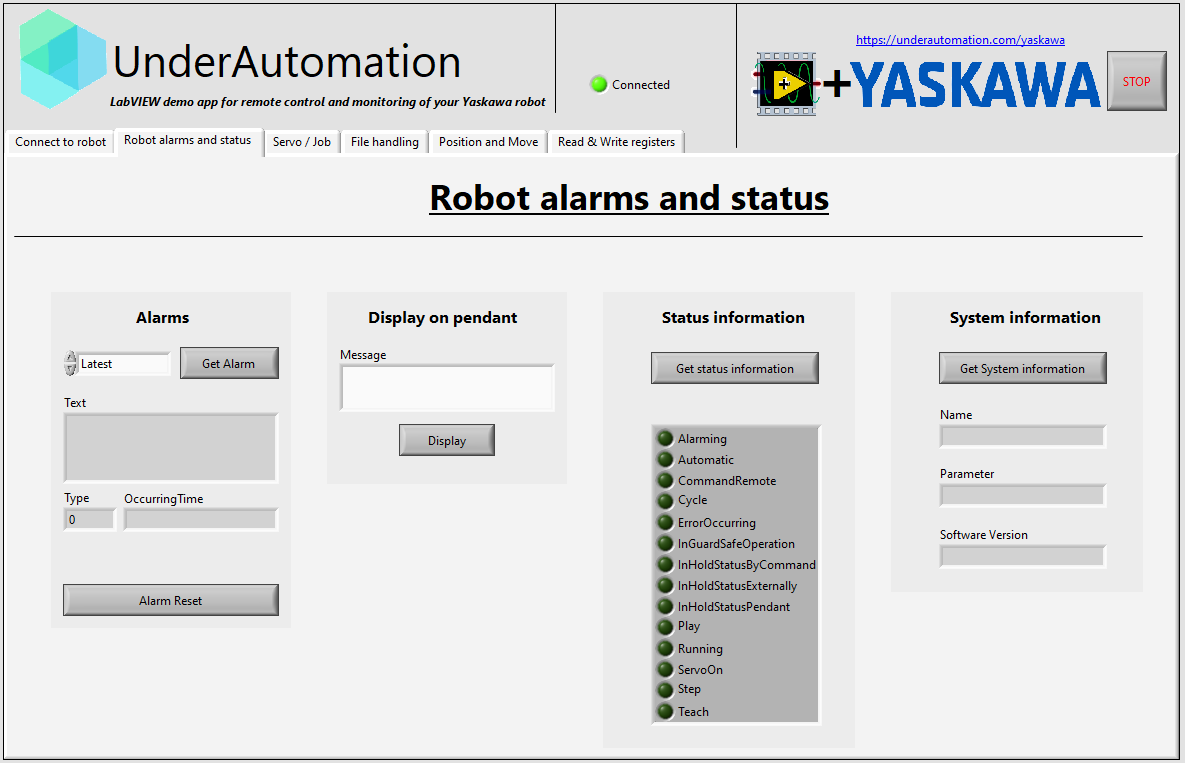
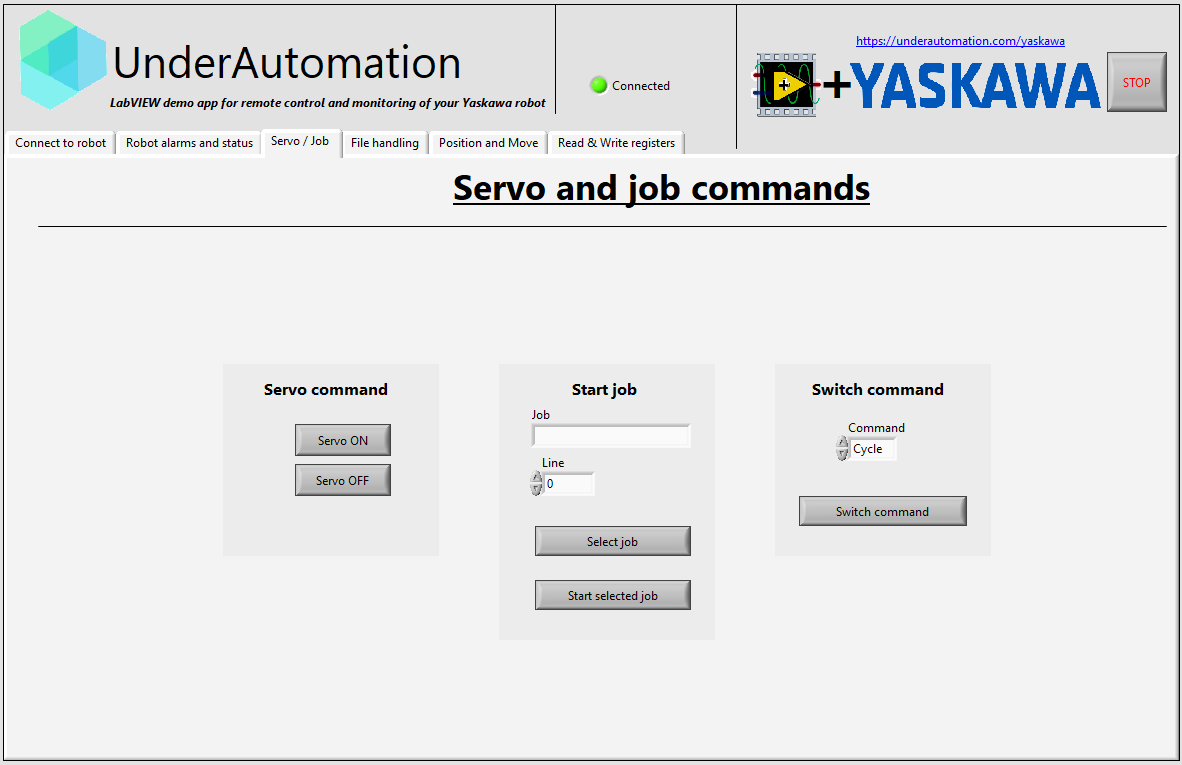
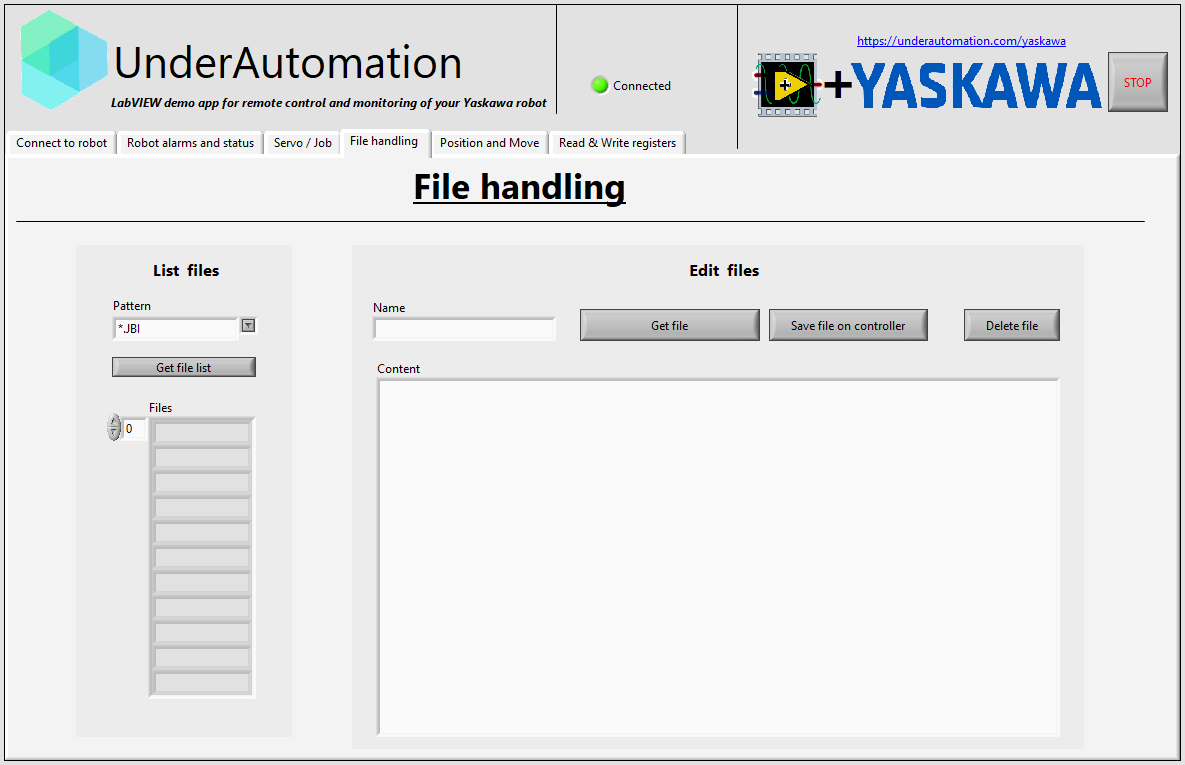
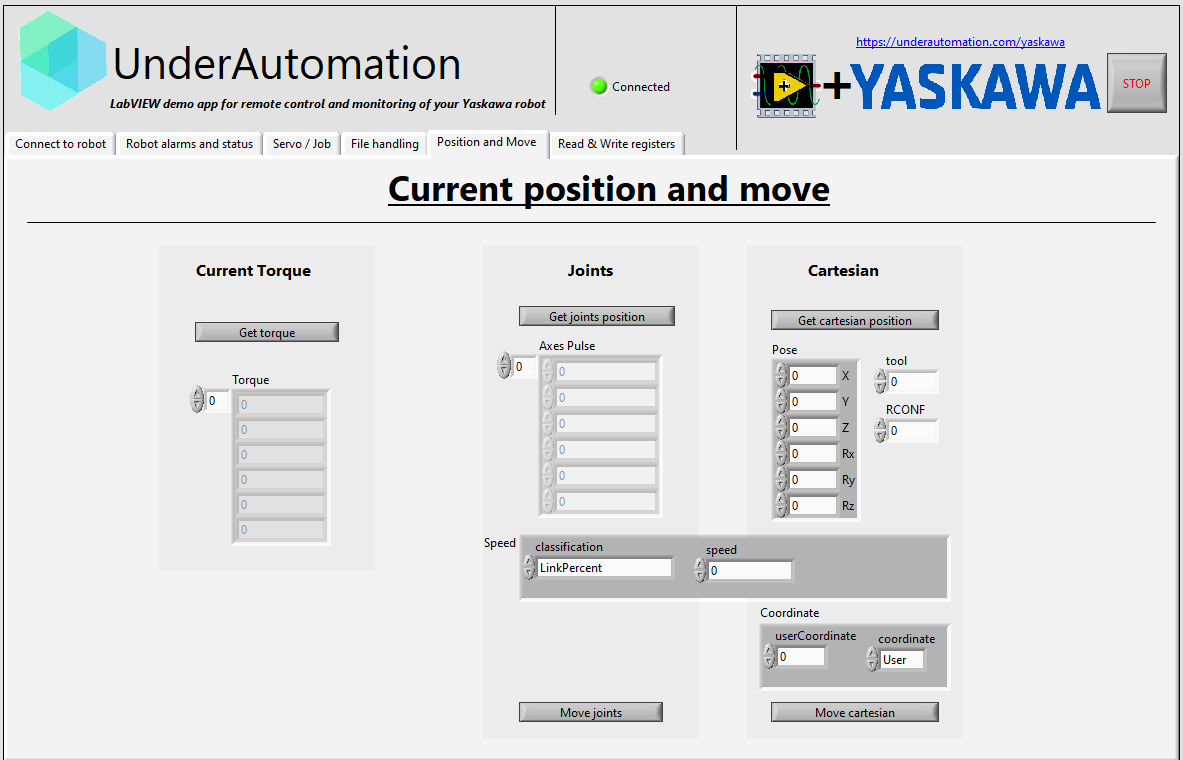
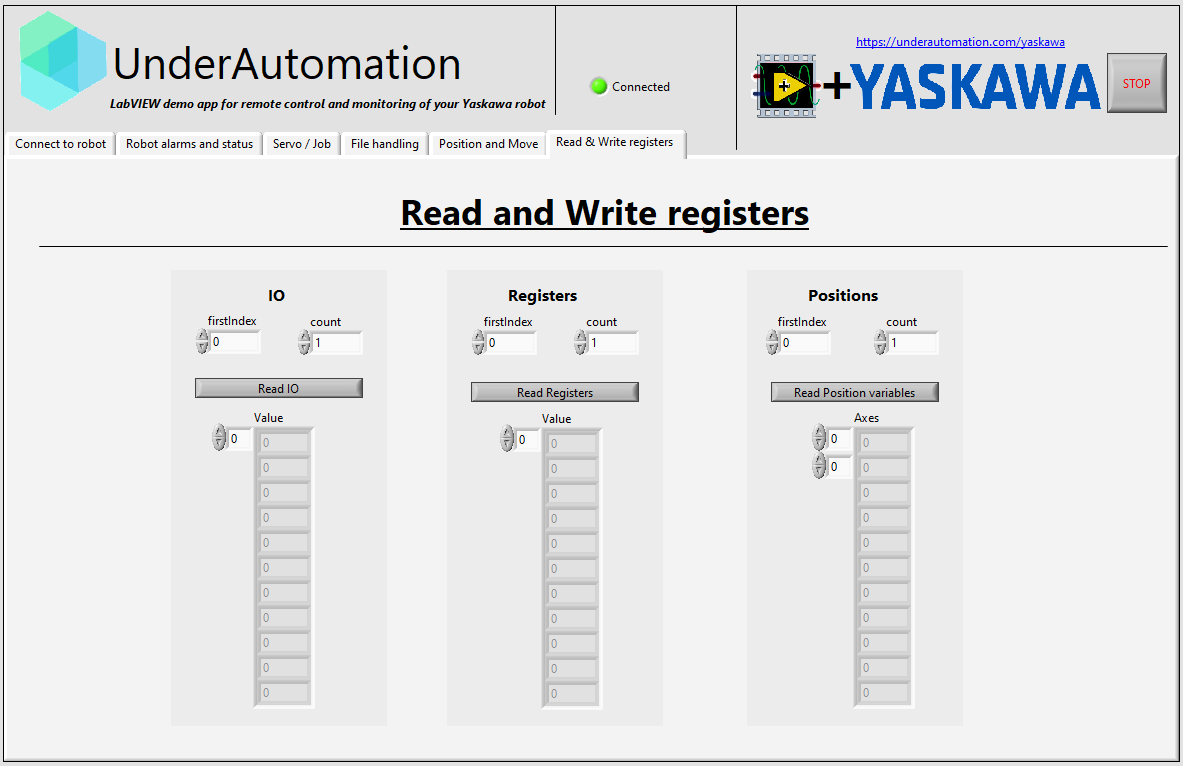
Examples/1. Main demo.vi connects to the robot and shows the main functions: status and alarms, servo and jobs, files, positions and motion, registers.
Connection and license
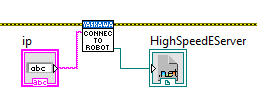
ConnectToRobot.vi connects to the robot with its IP address. It returns the robot reference that the other VIs take as input. RegisterLicense.vi registers your license key. Without a key, the library runs for 30 days.
The VIs that change the state of the controller (servo, motion, job start, file write) need the remote mode and the settings of Connect to your robot.
VIs of the library
Alarms
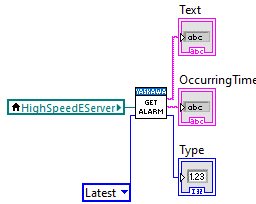
AlarmReset.vi resets the alarms. GetAlarm.vi reads one of the 4 alarms that the controller reports.
Files
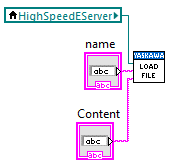
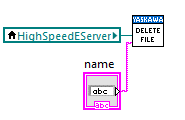
GetFileList.vi, GetFile.vi, LoadFile.vi and DeleteFile.vi list, download, upload and delete the files of the controller.
Jobs
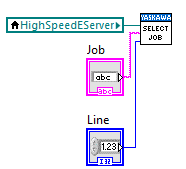
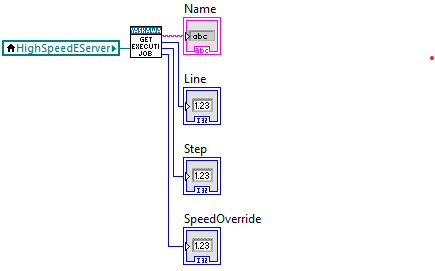
SelectJob.vi and StartJob.vi select and start a job. GetExecutingJobInformation.vi reads the name, the line and the step of the executing job.
Positions and motion
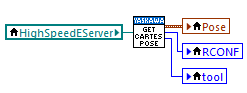
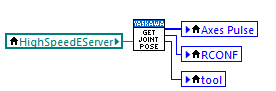
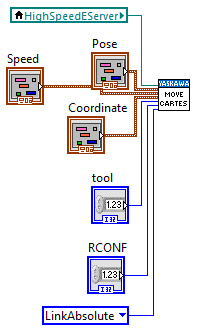
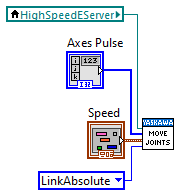
GetCartesianPosition.vi and GetJointPosition.vi read the position of the robot. MoveCartesian.vi and MoveJoints.vi move it.
Status and system
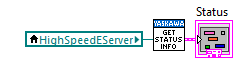
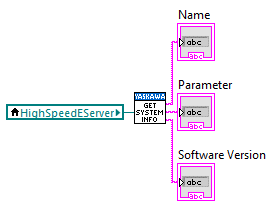
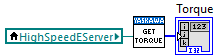
GetStatusInformation.vi, GetSystemInformation.vi and GetTorque.vi read the status of the controller, its software version and the torque of each axis. Display.vi shows a message on the pendant.
Variables and I/O
ReadIO.vi reads the I/O signals. Other VIs read the variables: registers, byte, integer, double integer, real and string variables (16 and 32 bytes), position variables, base and external axis positions.
Commands
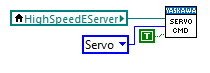
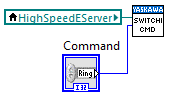
ServoCommand.vi switches the servo on and off. SwitchingCommand.vi selects the cycle mode: step, cycle or continuous.
Compatibility
| Item | Supported |
|---|---|
| LabVIEW | 2010 to 2024, one folder per version |
| Operating system | Windows |
| Controllers | YRC1000 (micro), MOTOMAN NEXT, DX100 / DX200, FS100, ERC / XRC / MRC |
What to read next
- Connect to your robot: the settings of the controller.
- High Speed Ethernet Server overview: what each function does. The VIs have the names of the .NET methods.
- Licensing: the 30 day trial and the license key.